Last Updated on 18. October 2026 by SuffocationLink status: OK
Here, some distance measuring sensors are to be presented. The list does not claim to be exhaustive. Only the sensors that I am currently using in my projects will be described.
Comparison
Hier der direkte Vergleich, zu den einzelnen Beiträgen geht es weiter unten.
| US-015 | HC-SR04 | US-100 | GY-530 (VL53L0X) | TFmini | GY-68 | GY-302 | GY-273 | |
|---|---|---|---|---|---|---|---|---|
| Messgröße | Entfernung | Entfernung | Entfernung | Entfernung | Entfernung | Barometer Thermometer | Beleuchtungsstärke (Luxmeter) | Kompass – 3-Achsen-Magnetometer |
| Messprinzip | Sonar | Sonar | Sonar | Lidar | Lidar | |||
| Sensor-Baustein | ST VL53L0X | Bosch BMP180 | ROHM BH1750FVI | Honeywell HMC5883L | ||||
| Messbereich | 20–4000 mm | 20–4000 mm | 20–4500 mm | 30 – 2000 mm | 300–12000 mm | 300–1100 hPa; 0–65 °C | 1–65535 lx | ±8 Gauss je Achse (x, y, z) |
| Accuracy | 1 mm + 1 % | 3 mm | 3 mm + 1 % | ±3 % (High-Accuracy-Modus, bis 1,2 m); sonst 3–12 % | 1 % (unter 6 m), 2 % (6–12 m) | ±0,12 hPa (relativ), −4 … +2 hPa (absolut); ±1,0 °C | 1 lx (Auflösung H-Modus); Messwert/Istwert 0,96–1,44 | 1–2° |
| Öffnungswinkel | unter 15° | 15° | unter 15° | 25° | 2,3° | |||
| Frequenz/Wellenlänge | 40 kHz | 40 kHz | 40 kHz | 940 nm | 850 nm | |||
| Operating voltage | 5 V | 5 V | 2,4–5,5 V | 2,8 – 5 V | 4,5–6 V | 5V | 5 V | 5 V |
| Sensor voltage | 2,6–3,5 V | 1,8–3,6 V | 2,4–3,6 V | 2,16–3,6 V | ||||
| Stromaufnahme | 2,2 mA | 15 mA | 2 mA | 19 mA (Spitze 40 mA) | ≤ 120 mW (≈ 24 mA bei 5 V) | |||
| Schnittstellen | TTL Pegel Trigger/Echo | TTL Pegel Trigger/Echo | UART, TTL Pegel Trigger/Echo | I²C | UART | I²C | I²C (23h / 5Ch) | I²C (1Eh) |
| Abmessungen | 45 x 20 x 18 mm | 45 × 20 × 15 mm | 45 x 20 x 18 mm | Groß 25 x 12 x 4 Klein 13,3 x 10,5 x 2 mm | 42 × 15 × 16 mm | 13,9 × 18,5 mm | 16 × 18 mm | |
| Weight | unter 9 g | 8,7 g | 9 g | 0,5 g | 6,1 g | |||
| Description | Ultraschall-Entfernungssensor | Ultraschall-Entfernungssensor | Ultraschall-Entfernungssensor | Laser-Entfernungssensor (Time of Flight) | Lidar-Entfernungssensor |
Ultrasonic sensors
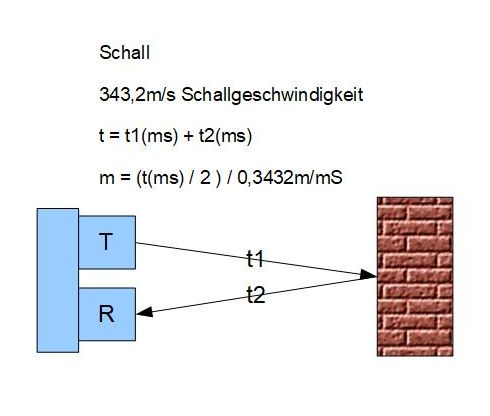
Ultraschallsensoren senden einen Schallimpuls aus und warten dann auf eine Reflektion des Impulses durch ein Hindernis. Trifft der Impuls nicht auf ein Hindernis, wird er auch nicht zurückgeworfen und der Sensor läuft in einen Timeout. Dies ist bei der Verwendung dieser Sensoren zu berücksichtigen.
IR/Laser sensors
| Date | Change | Author |
|---|---|---|
| 18.10.2026 | Sensor-Tabelle (TablePress) durch Vergleichsblock des Taxonomy Modeller ersetzt | Suffocation |
| 08.10.2026 | Überschriften-Hierarchie korrigiert (H1→H2, Unterebenen eine Stufe tiefer) | Suffocation |
| 04.10.2026 | Rechtschreibung korrigiert: Tippfehler, Grammatik | Suffocation |
| 03.10.2026 | Log-Liste eingefügt | Suffocation |
| 04.06.2017 | Post created | Suffocation |
Hello. Thank you for the interesting articles on ultrasonic sensors/distance sensors. I intend to create an ultrasonic curtain/sensor curtain over a specific measurement window to enable precise positioning (X/Y) down to millimetres. Are any of these sensors suitable for this purpose (e.g. US-015)?
Since I want to use this for an evaluation system to analyse an air pistol target, in addition to accuracy, the problem of measuring speed also arises. The speed of the pellet is approximately 130 m/s.
A target looks like this, for example:
https://kks-berlin.de/wp-content/uploads/2016/03/Zielscheibe_Luftpistole.jpg (Source: KKS Berlin)
I would be grateful for any known information or ideas.
Hello Tom,
That's a nice project. The ultrasonic sensors are too sluggish, have a wide dispersion, and would probably not even register the projectile at all. There are laser sensors, but they require around 33ms for a measurement. This is still too slow. In that time, your projectile has already travelled 4.5cm.
Proposal 1: Light barriers, horizontal and vertical. A light sensor opposite a laser. This allows for continuous measurement, and common controllers should be able to capture the projectile. At least one horizontal and one vertical light barrier will always be crossed, thus determining the coordinates on the disc. (This might also be solvable capacitively (plate capacitor))
Proposal two: two high-speed cameras, one mounted horizontally and one vertically, positioned opposite a light source. At 200 frames per second, it takes around 5 ms per frame; the projectile has travelled around 6.5 cm in 5 ms, so with a depth of field of 20 cm, the projectile should appear at least two or three times (if I’ve done my maths correctly).
(To camera https://hackaday.com/2019/08/10/660-fps-raspberry-pi-video-captures-the-moment-in-extreme-slo-mo/)
I hope that helps; I’m keen to see how things develop.
Hello
Stefan
Thank you Stefan for your reply. With the light barriers, we tried something that worked wonderfully with a slow projectile or a pinhead. However, the diabolo with its 4.5mm diameter and its approx. 470-500 km/h is too fast and unfortunately isn't detected. That's why I came across your interesting blog forum. All attempts to increase the programming speed have failed so far. Does anyone perhaps have an idea for optimisation or similar?
Everything is controlled by one Raspberry Pi 1 B.
Of course, there are already manufacturers selling this sort of thing (expensive models with photoelectric sensors, ultrasonic sensors and promising printing plate detection are available), but at a price that’s quite high for home use. Development, manufacturing and so on certainly justify the cost, but perhaps you could build one yourself.
The variant with the camera sounds interesting too. Regards, Tim.