Last Updated on 3. October 2026 by SuffocationLink status: OK
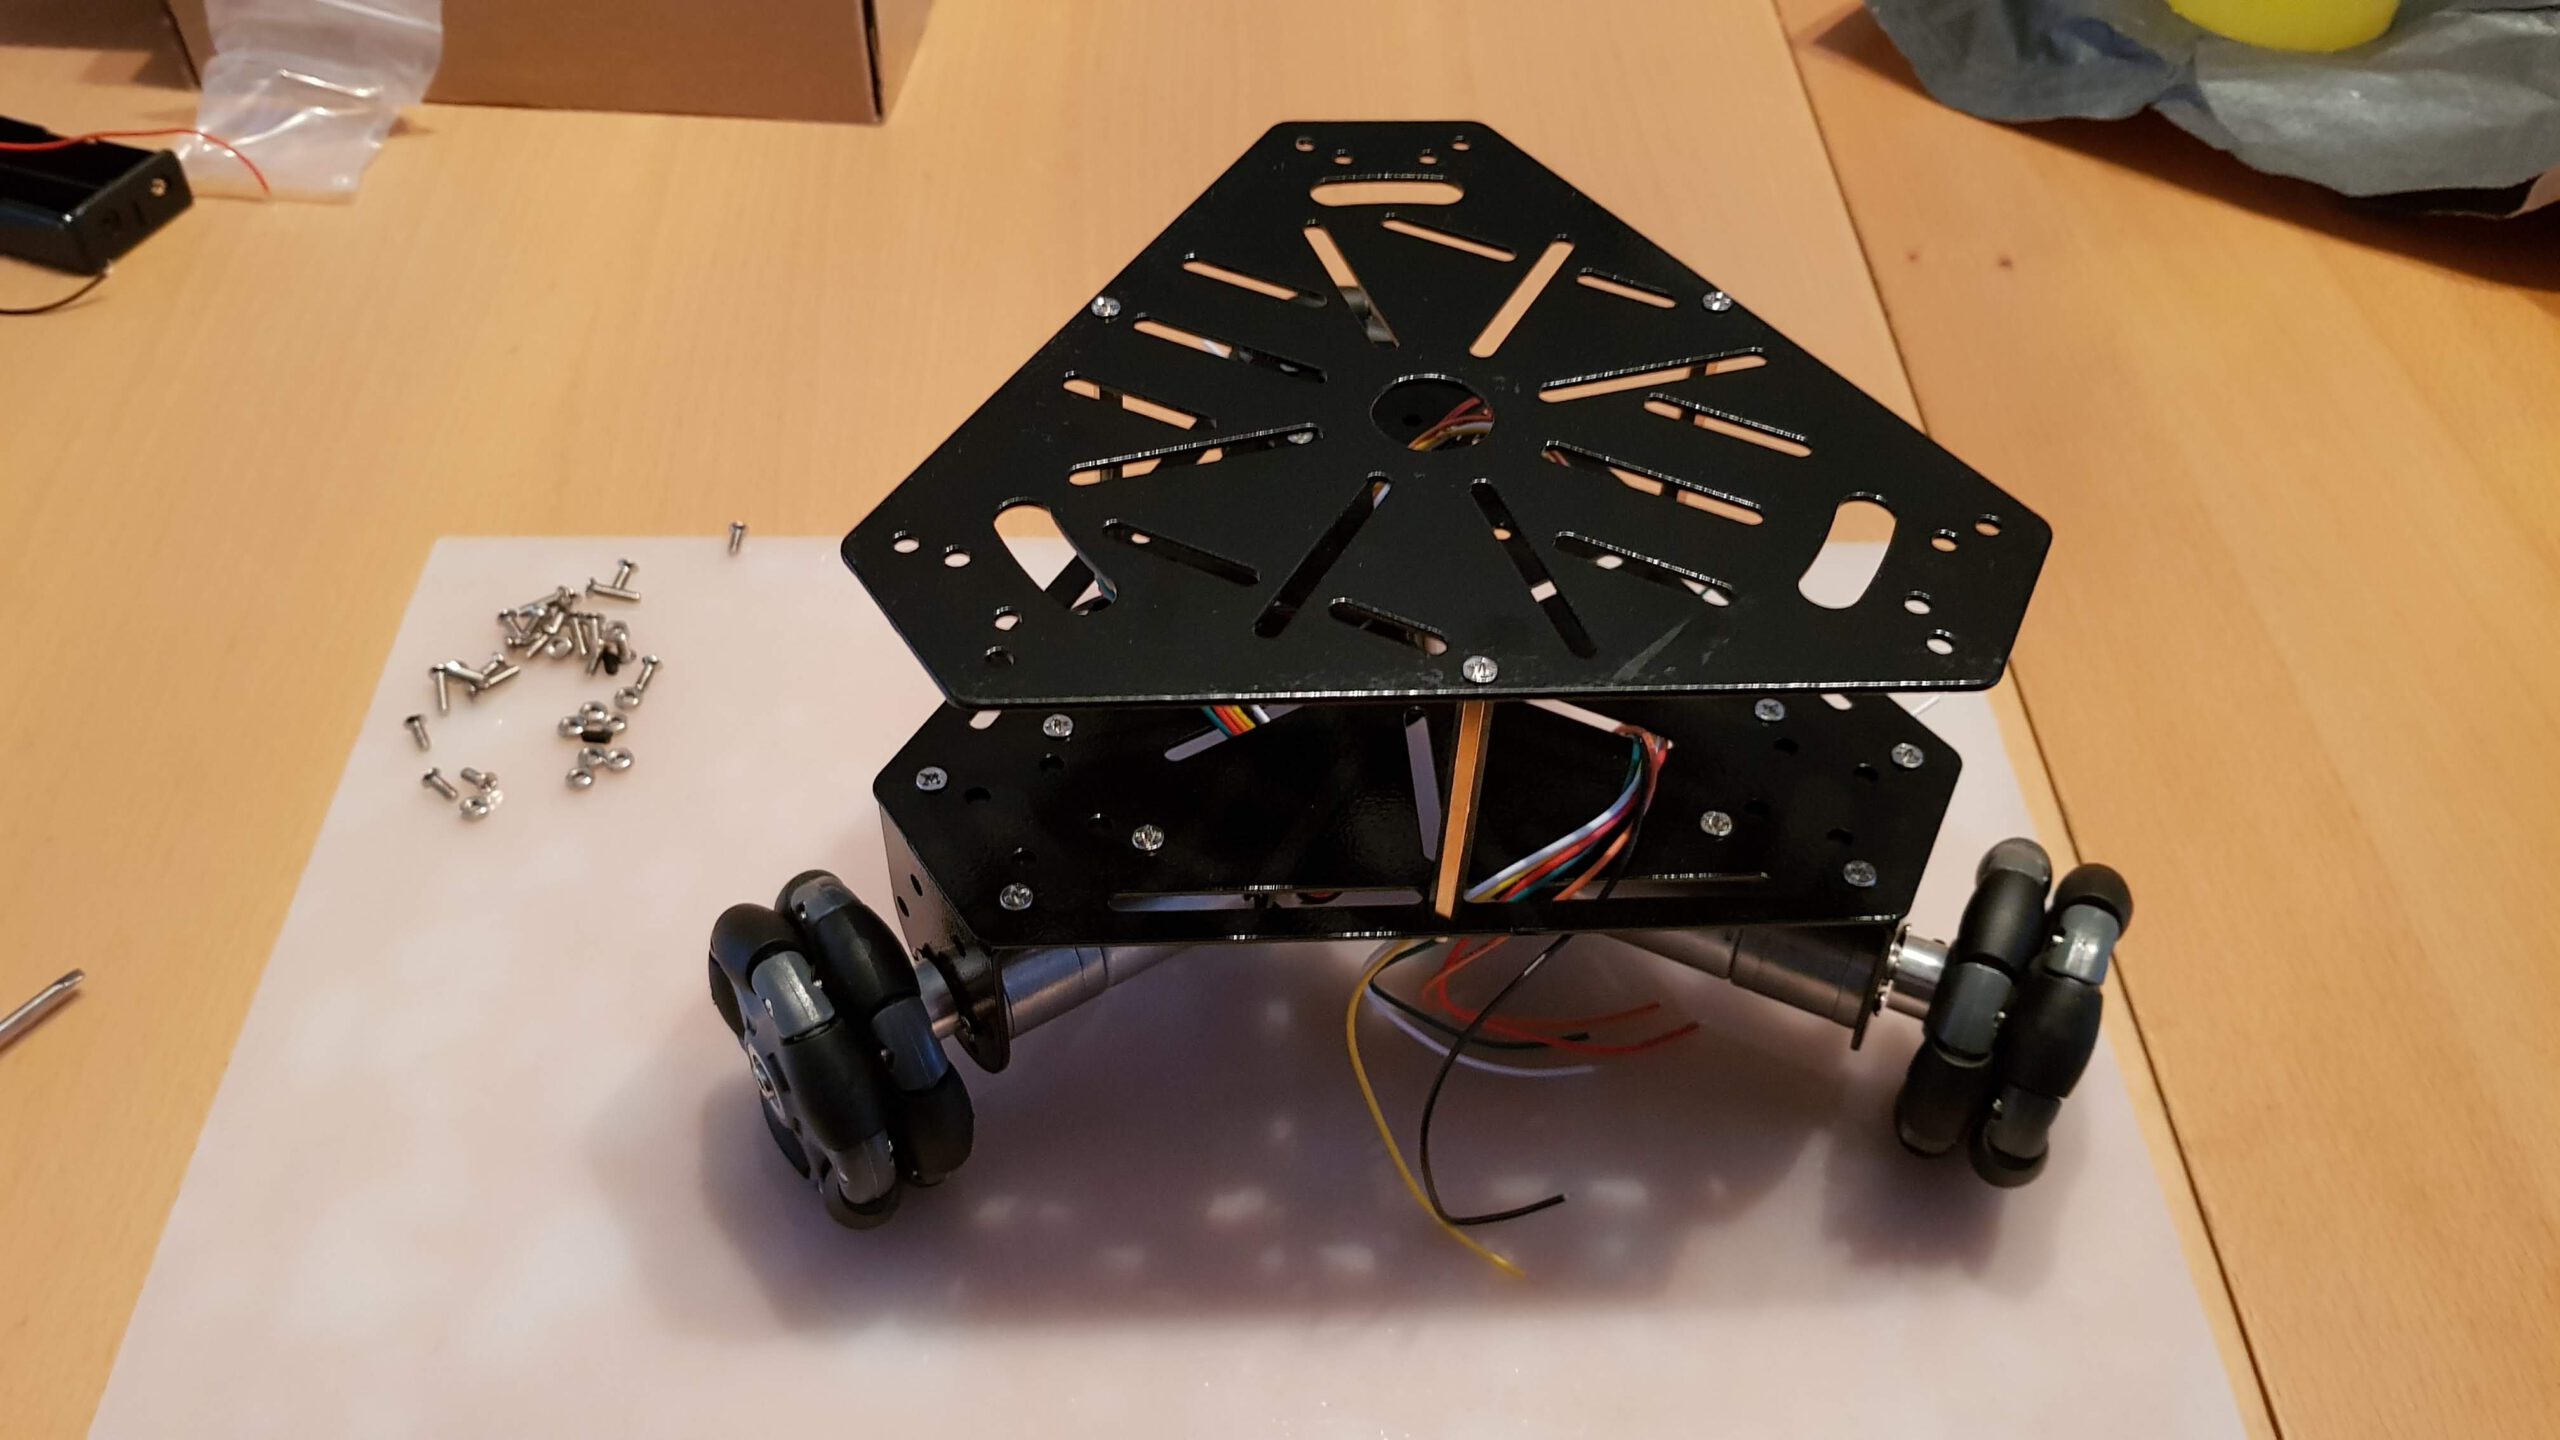
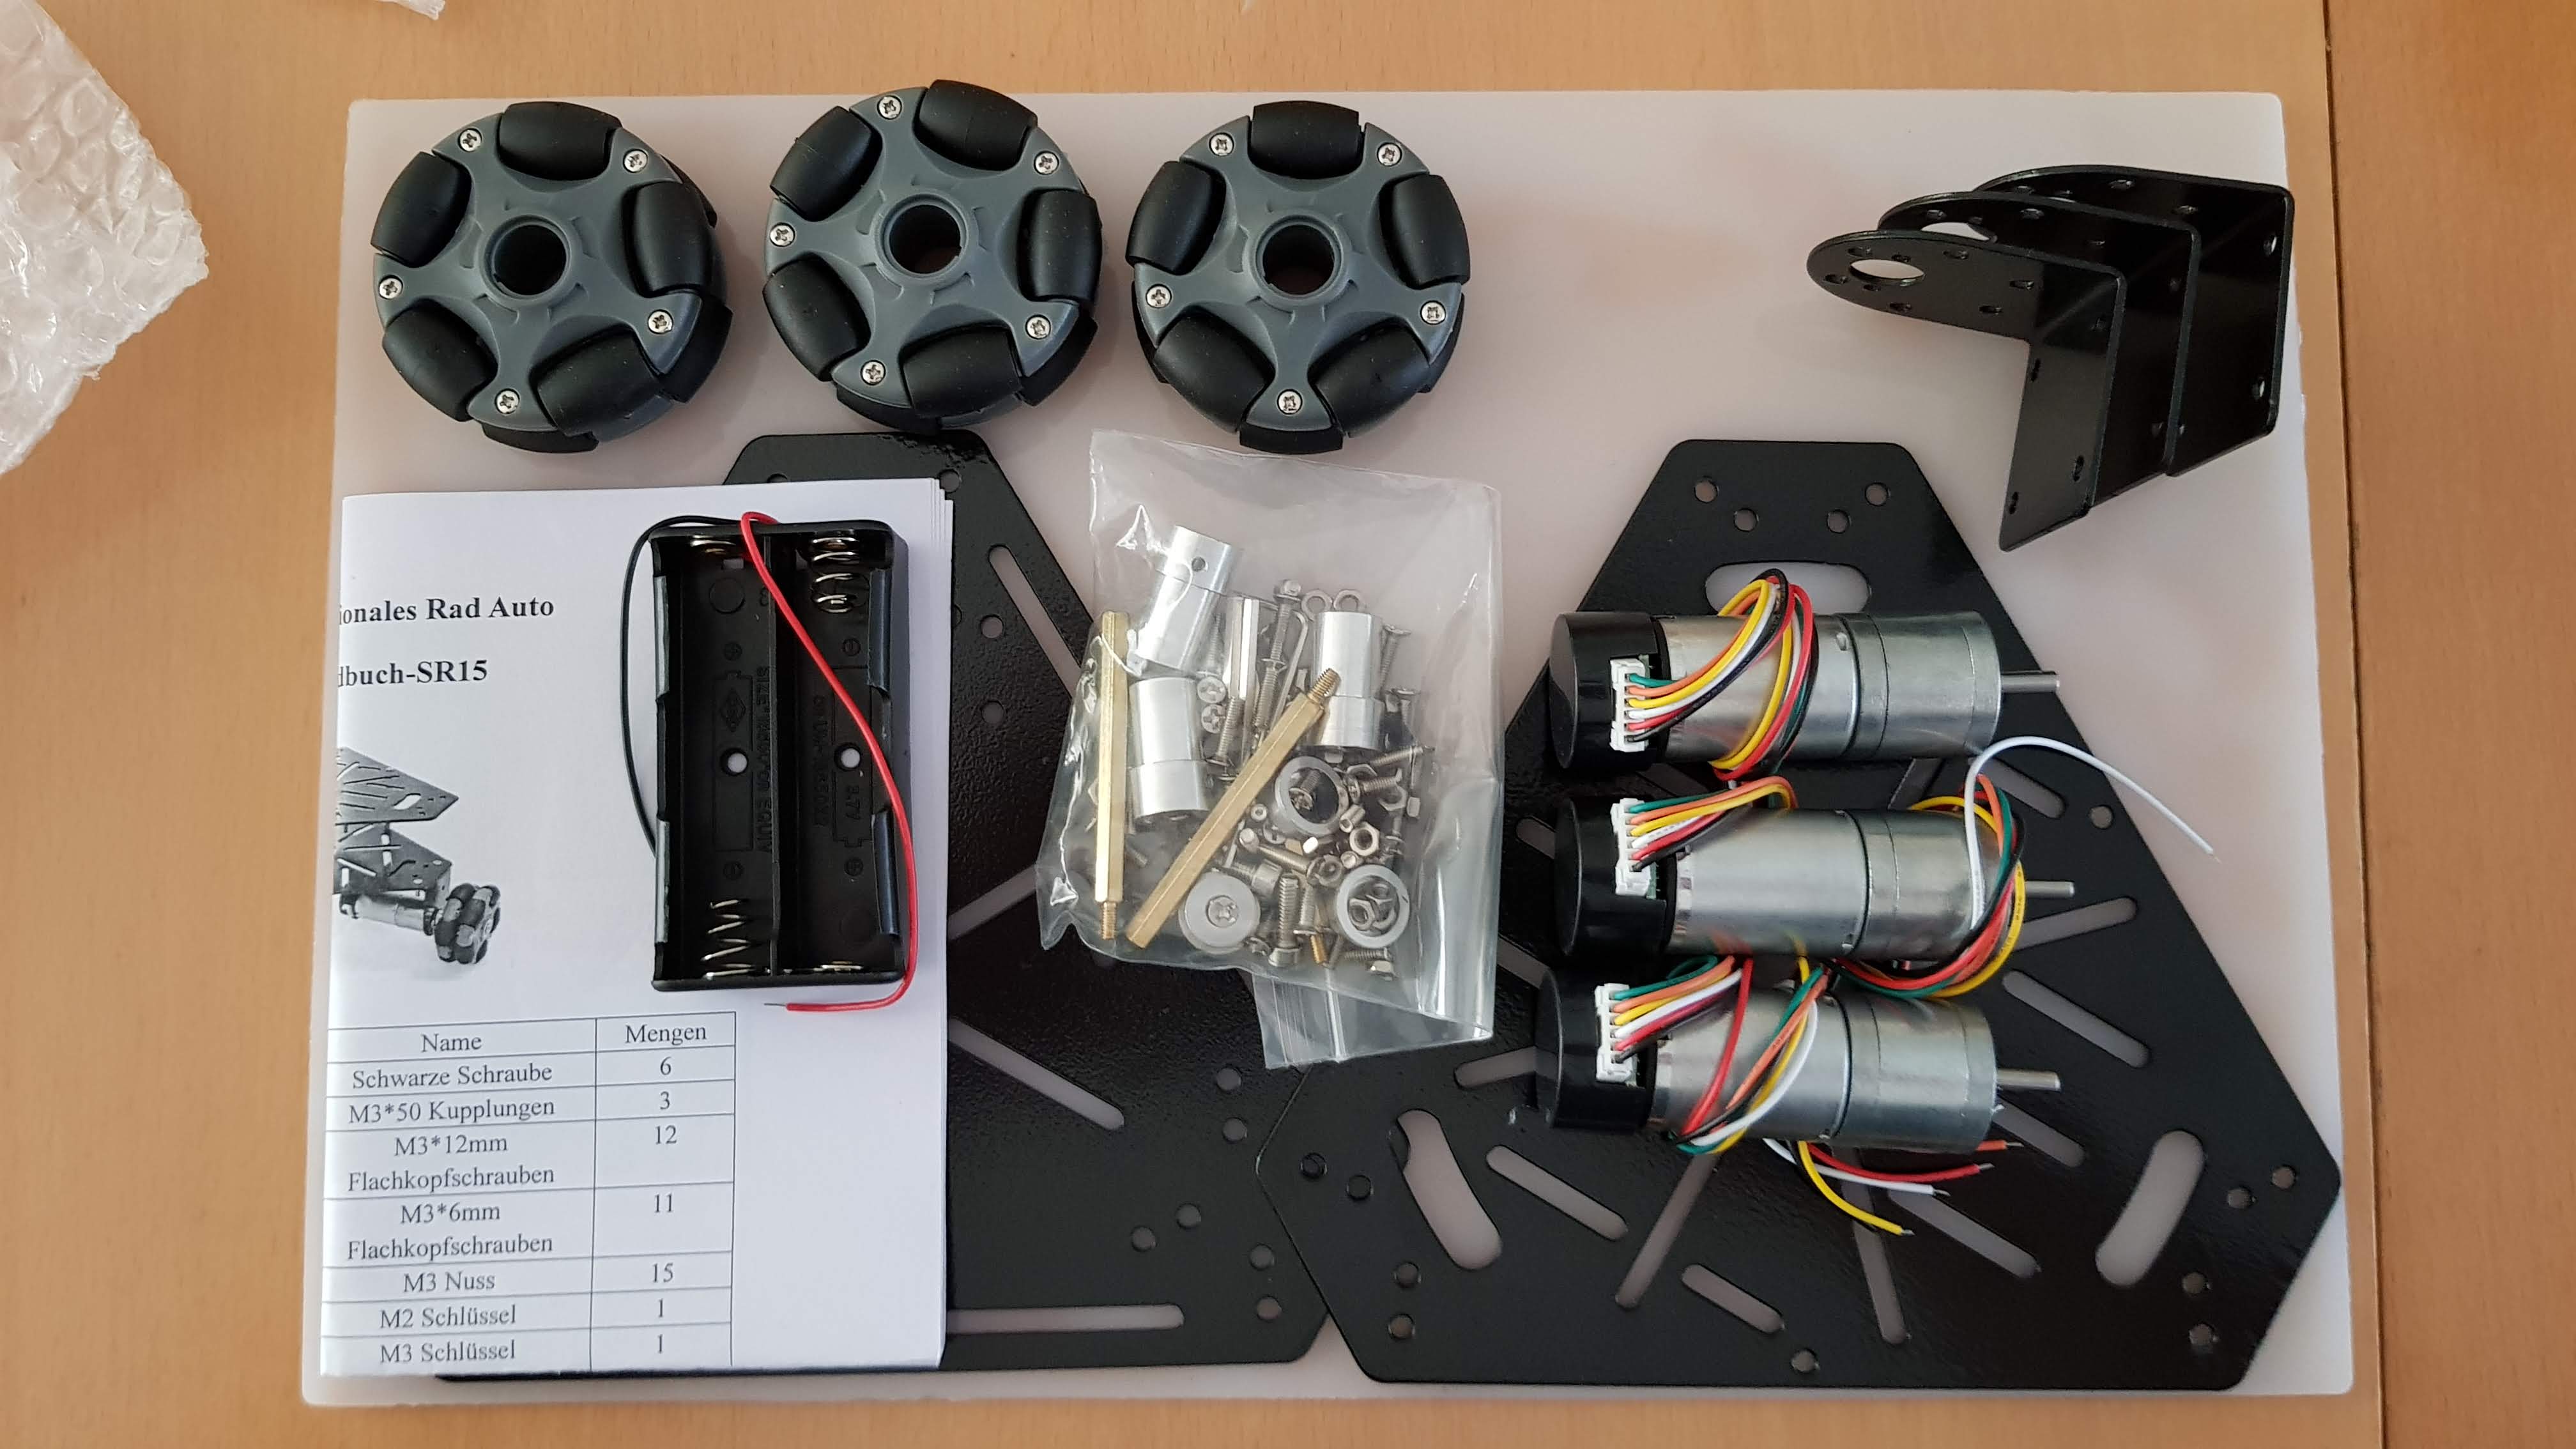
I acquired a robot chassis for €89 (this time directly from Amazon). This chassis has three omnidirectional wheels. In this report, I will show the assembly and mention a few facts. The use of the chassis will follow in later reports.
(The manufacturer has a video showing how to assemble this, which I've linked below)
Facts
Components
- Stabile Plattform aus Metall
- Drei Getriebemotoren mit Hall Sensor
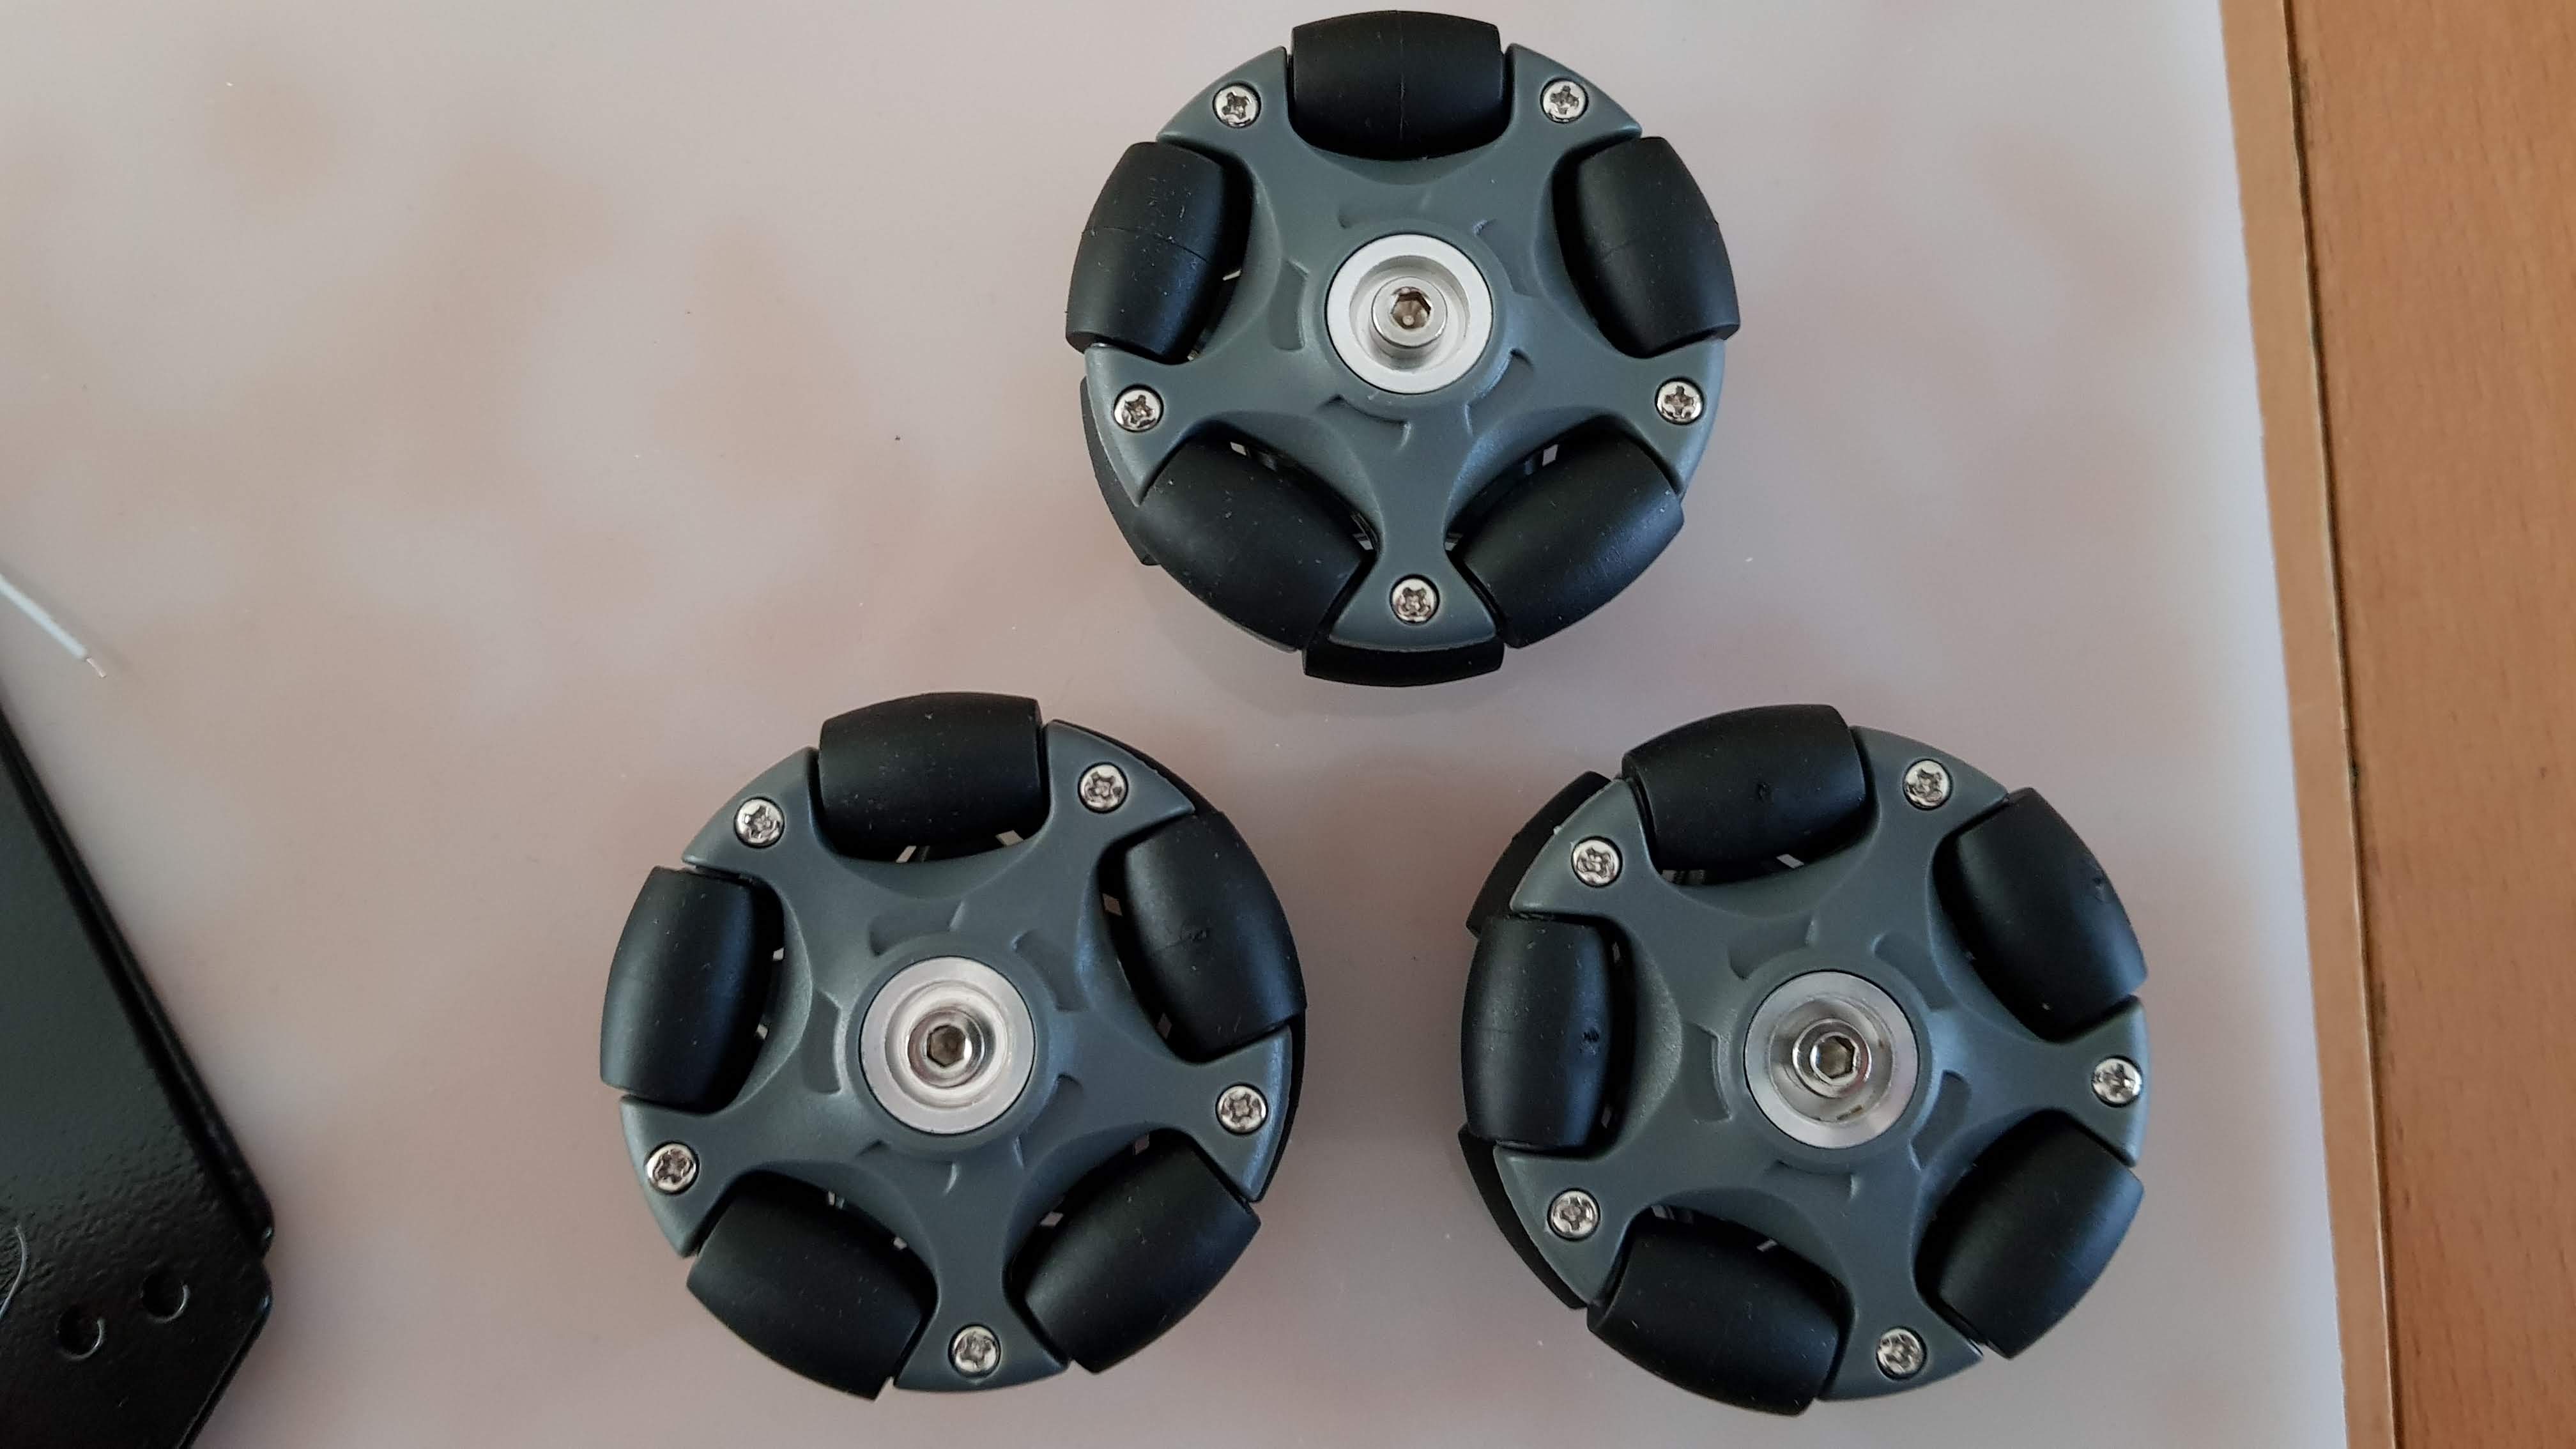
- Three omnidirectional wheels
- A battery compartment for 18650 industrial batteries
- Diverse Schrauben + 3 Inbus Schlüssel
- Speed: 20m / min
- Last: 2kg
- Maximal zulässiger Gradient: 40 Grad ?(was auch immer das bedeuten mag)
- Product colour: black
- DIY-Installationszeit: ca. 15 Minuten (ich habe etwas länger gebraucht wegen der Fotos)
- Product size: 14 * 14 * 11.5cm
- Packaging size: 27 * 18 * 5.5 cm
- Total weight: 1155g
The engines
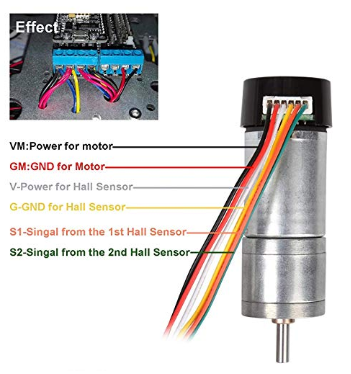
- Hall Sensor 5V DC
- Motor voltage: DC 9V
- No-load current: ≤200mA
- Max. current: 1.2A
- Motordrehzahl: Leerlauf 150 U / min – Last 100 U / min / min
Areas of application
- Laborversuche (Räder sind nur auf glatten, geraden Flächen gut)
- As a toy for the children 😉
- Autonomes Fahren mit allen Einschränkungen …
Structure
Unpacking
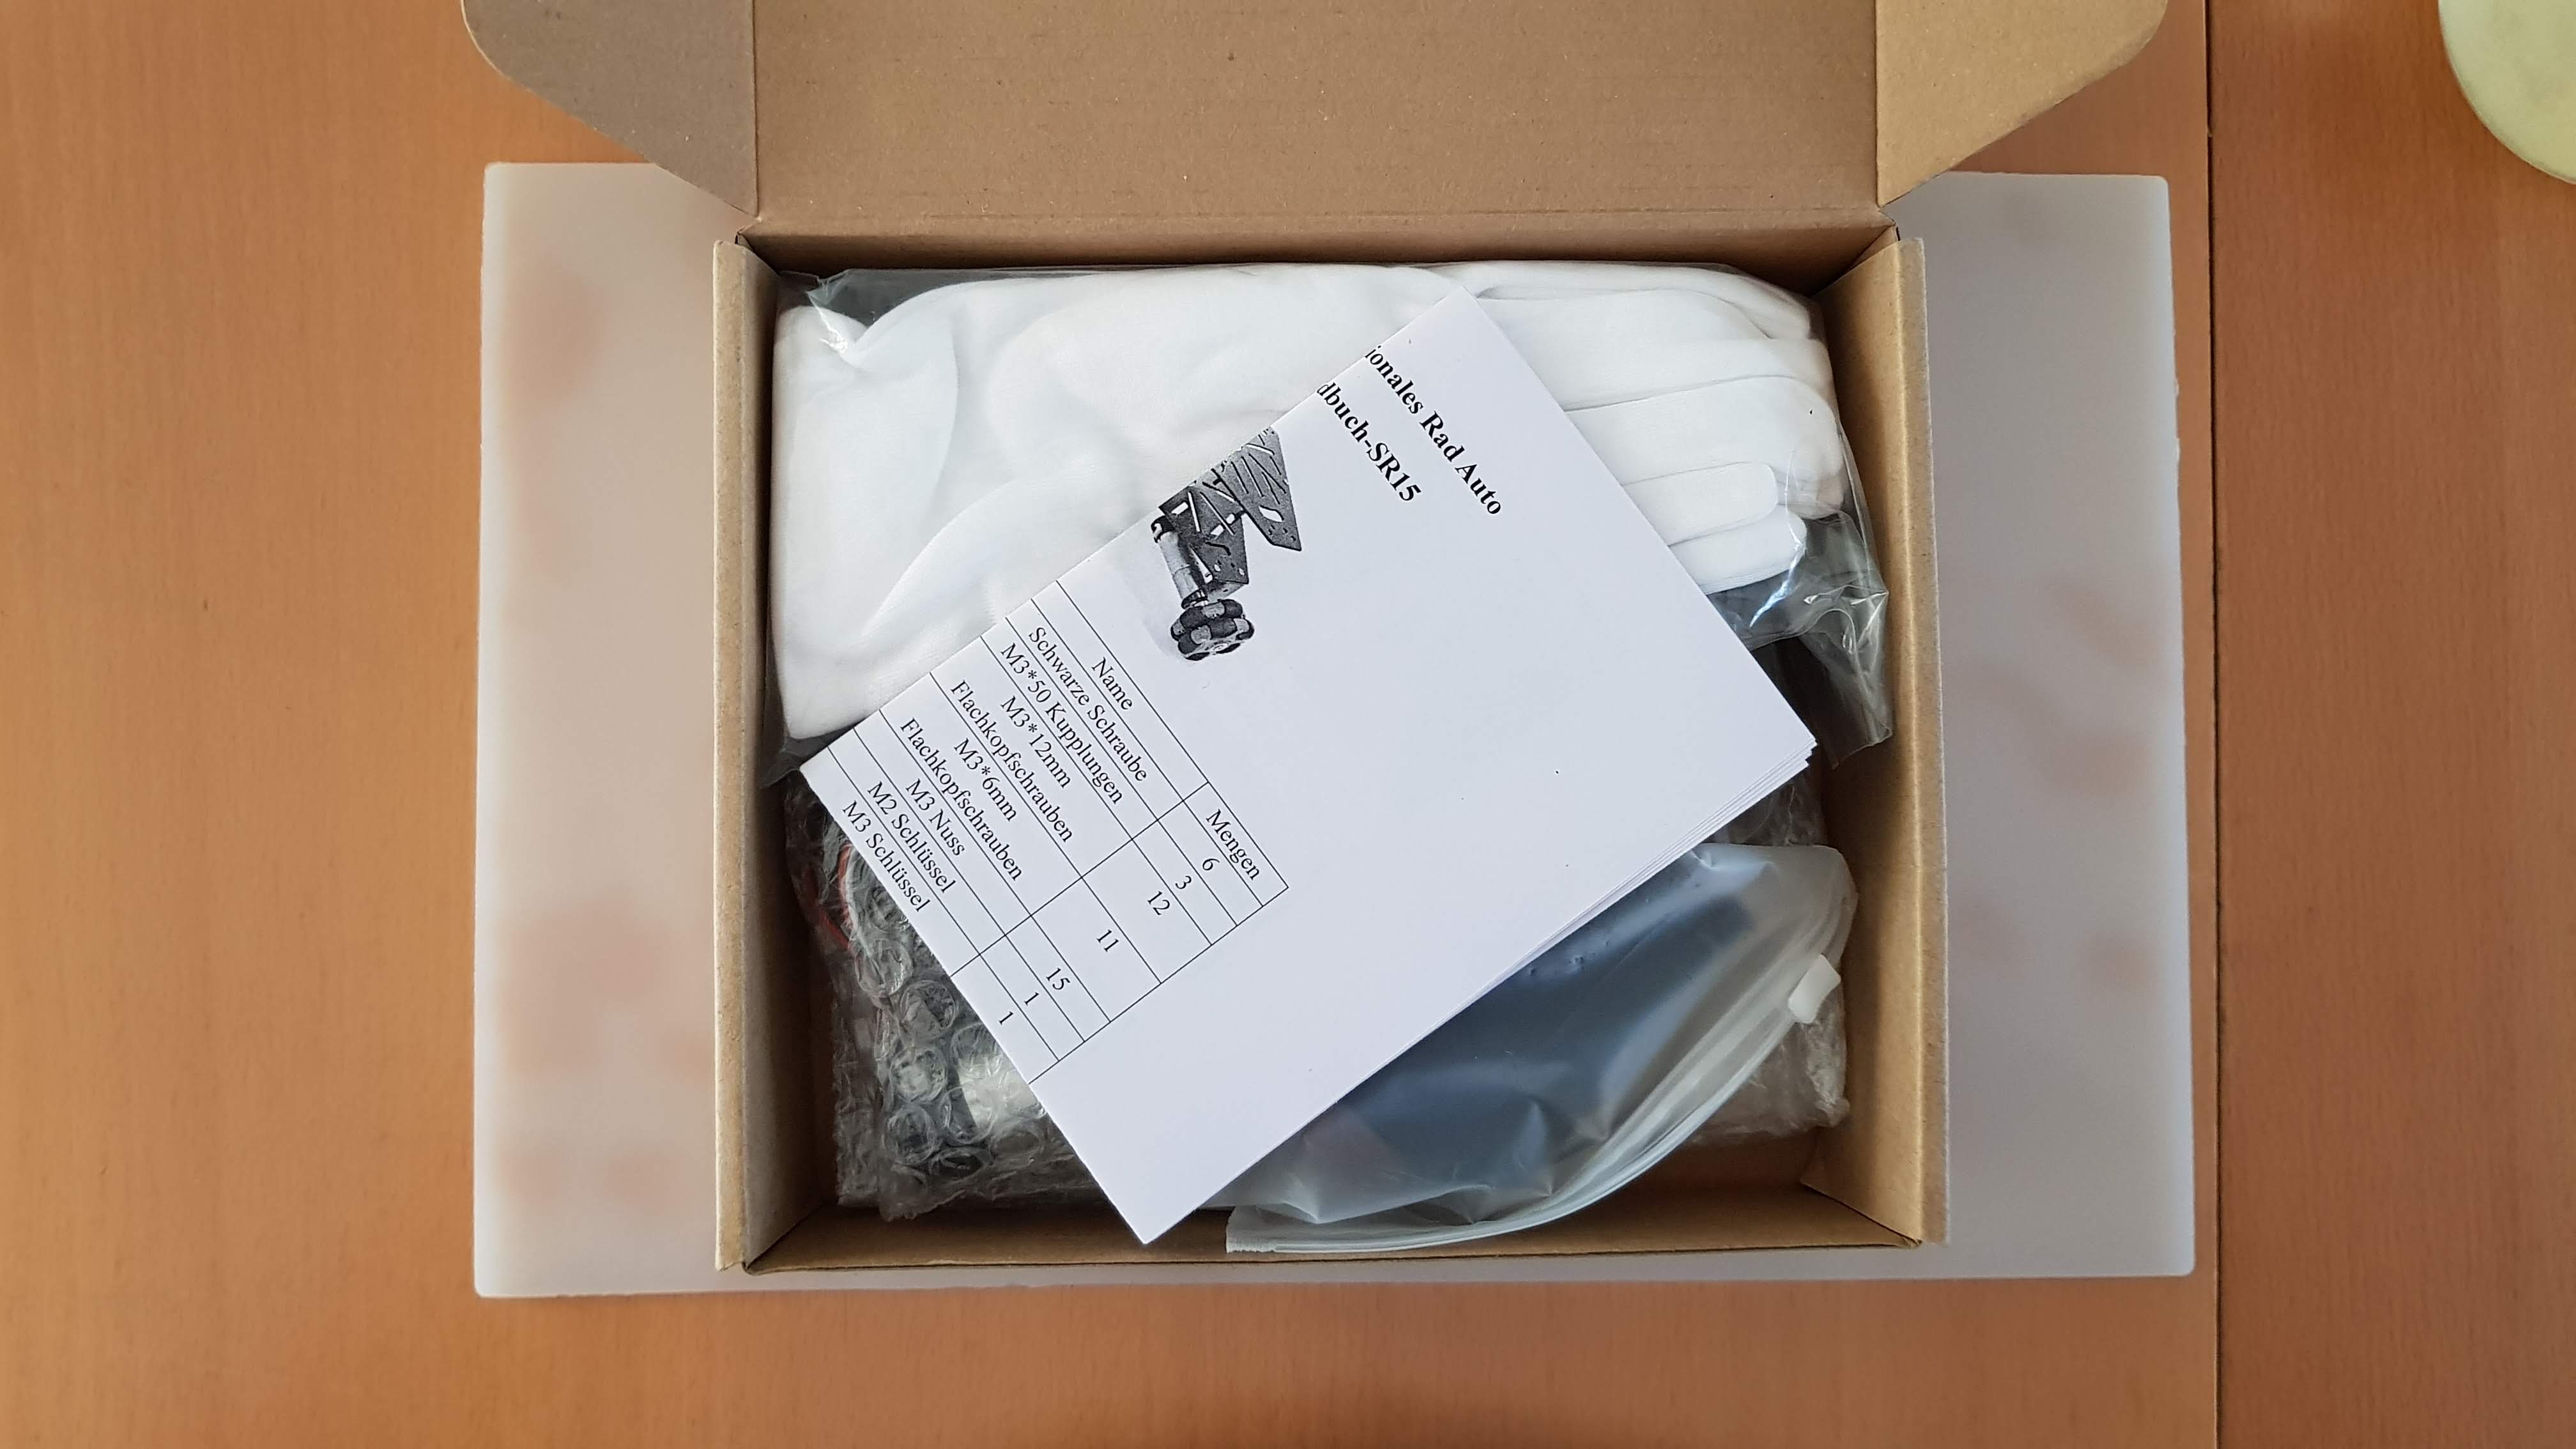
Der Bausatz kam gut verpackt und schnell bei mir an.
Prepare wheels
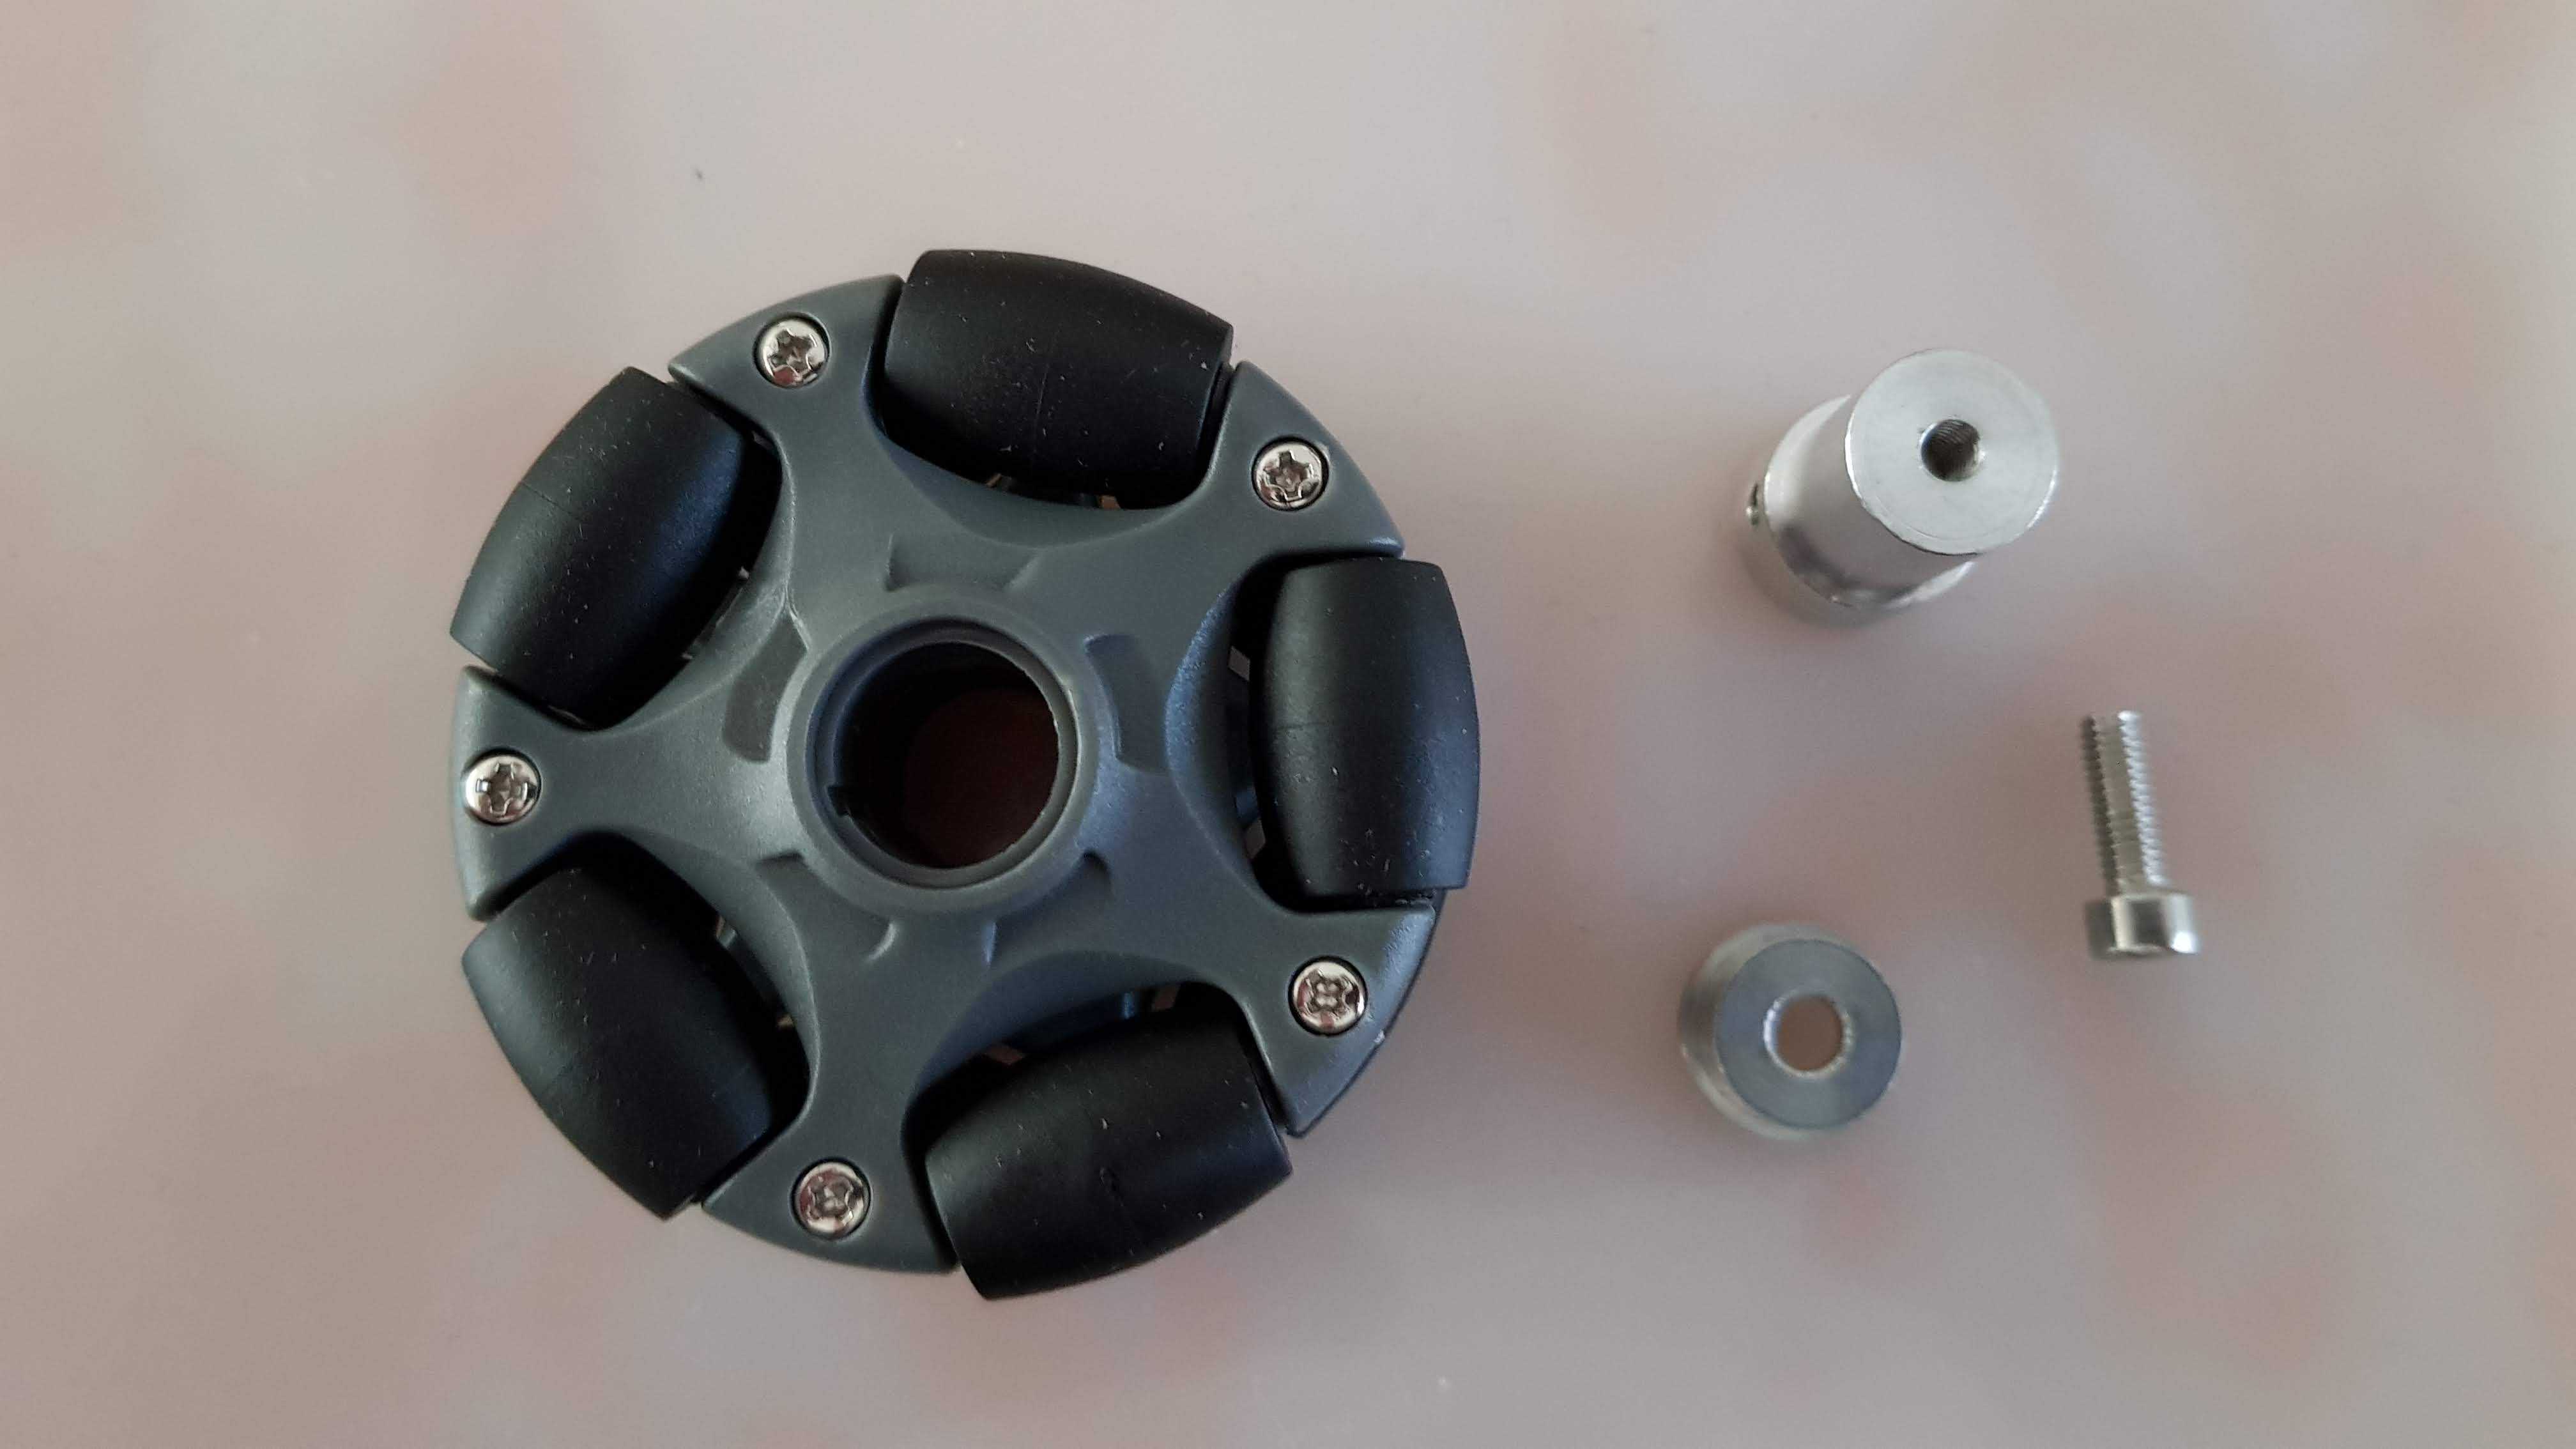
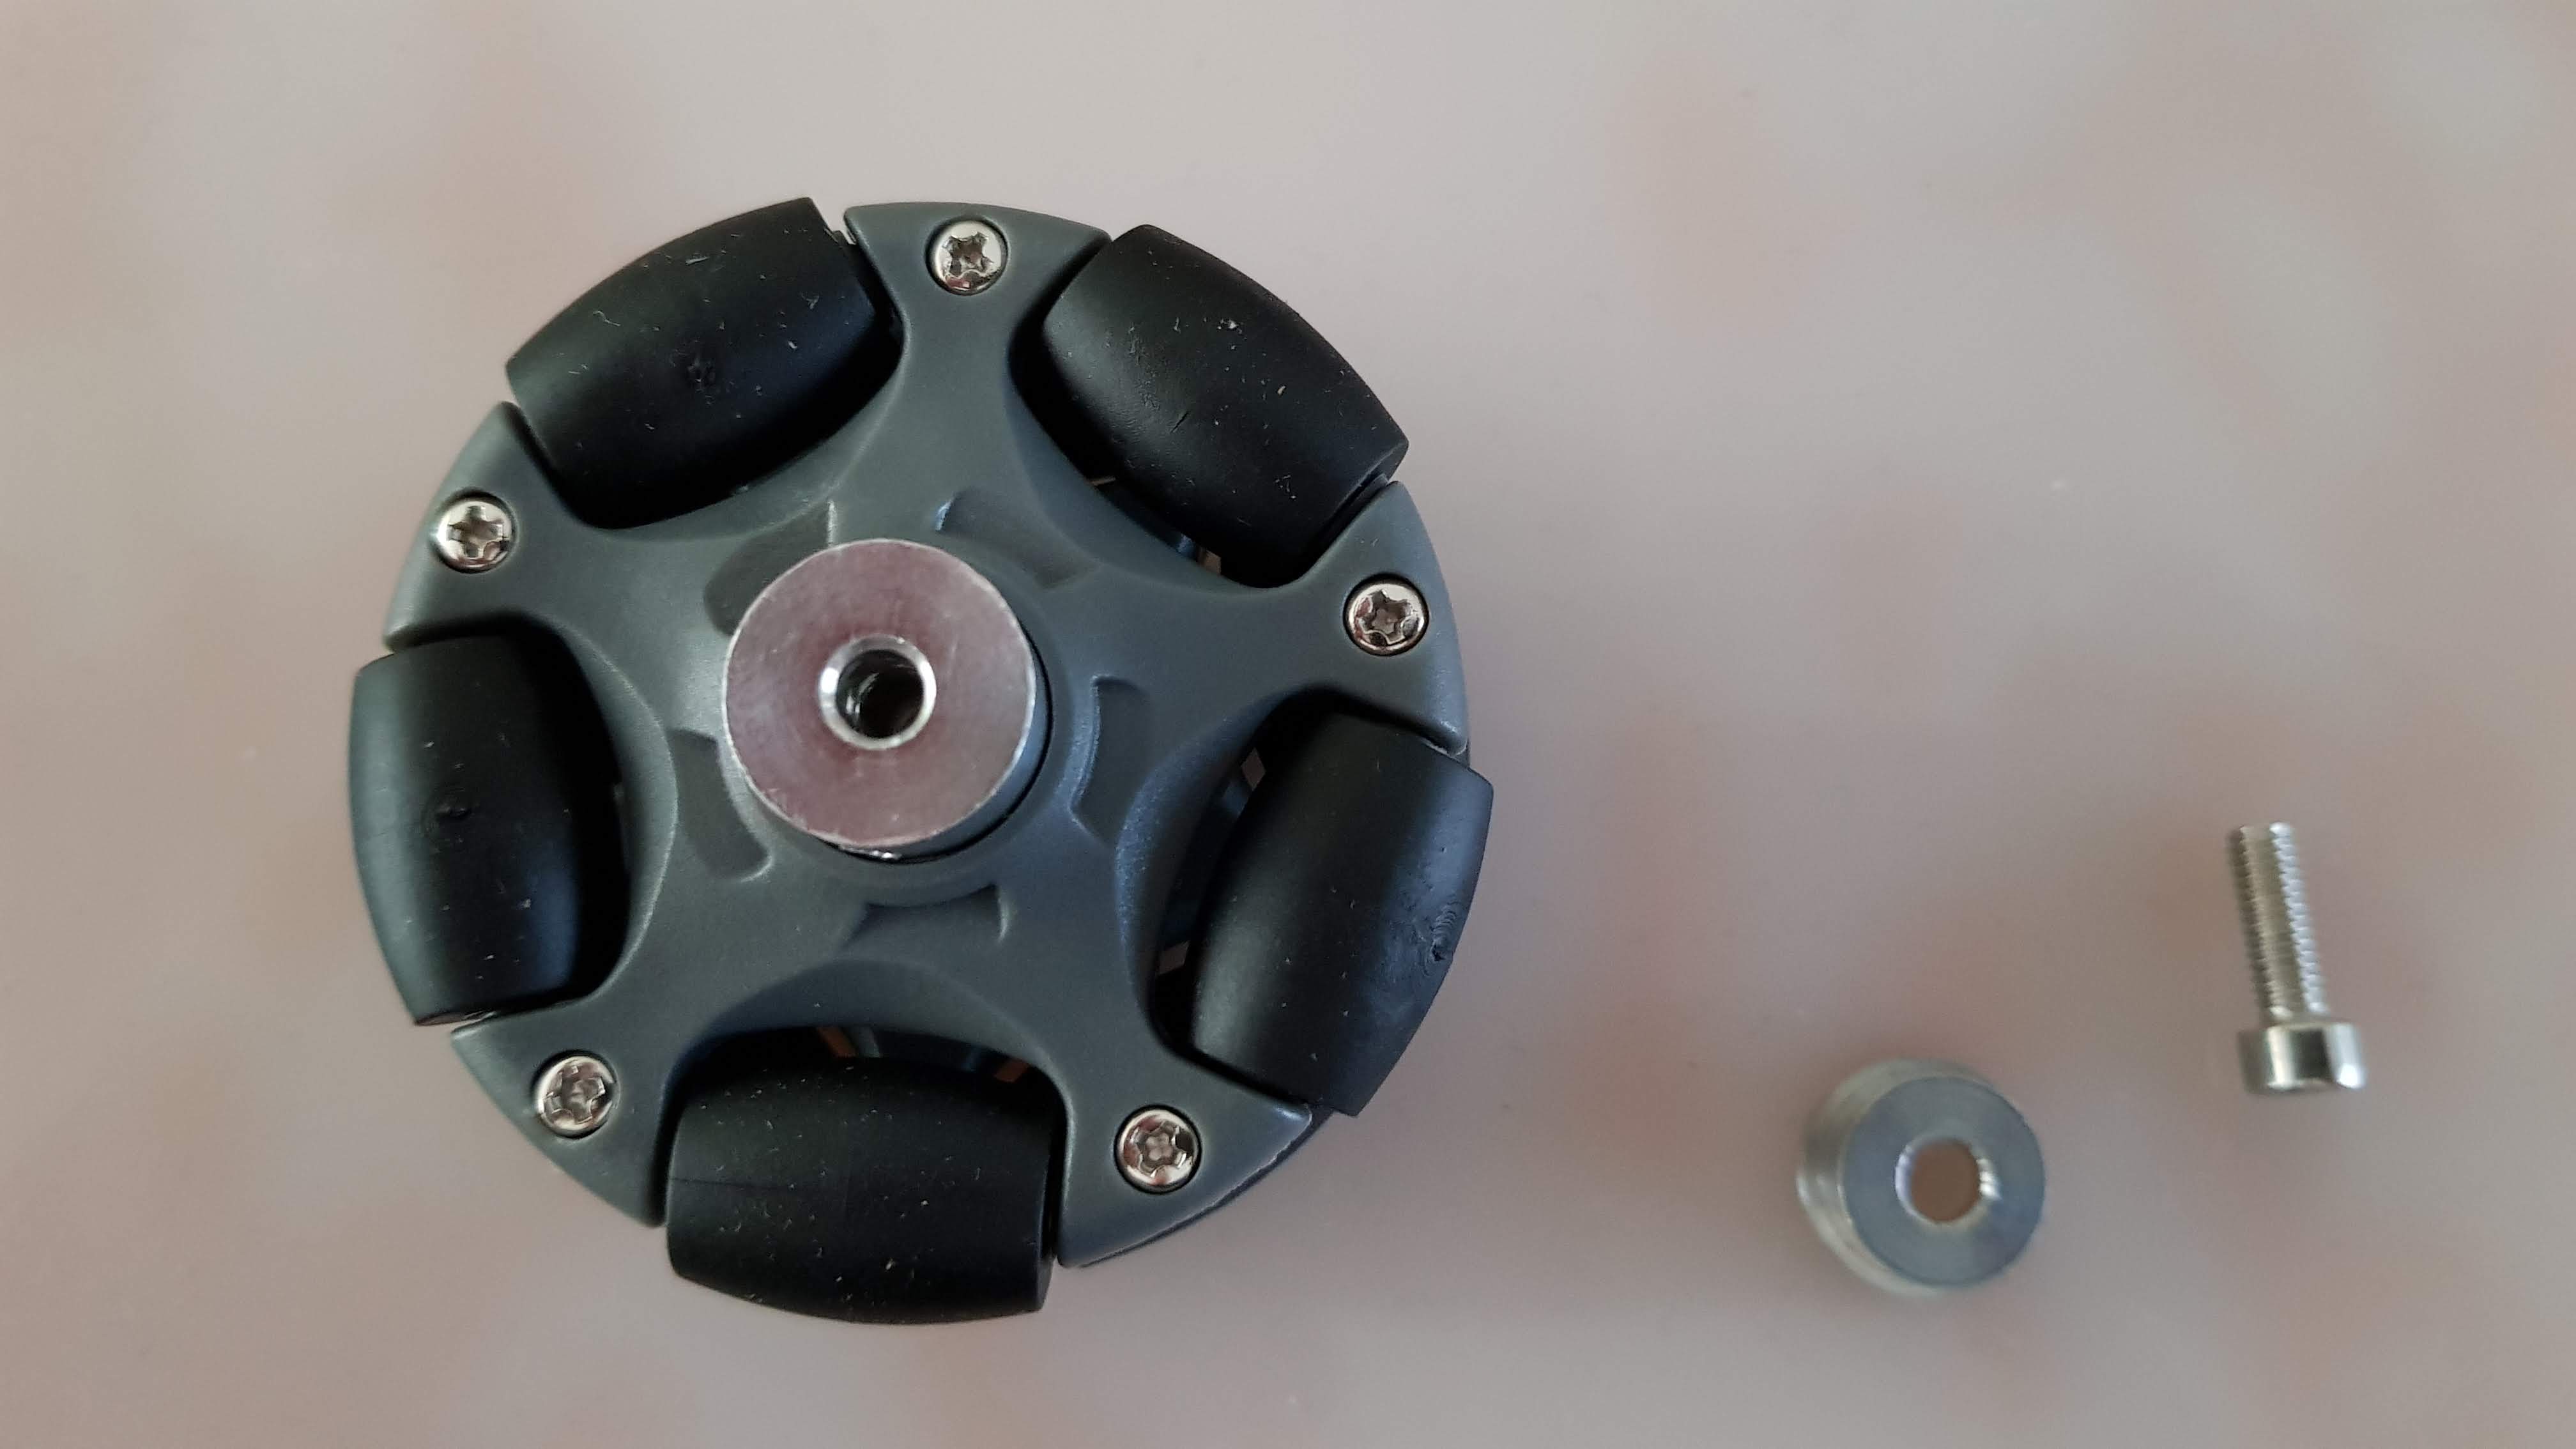
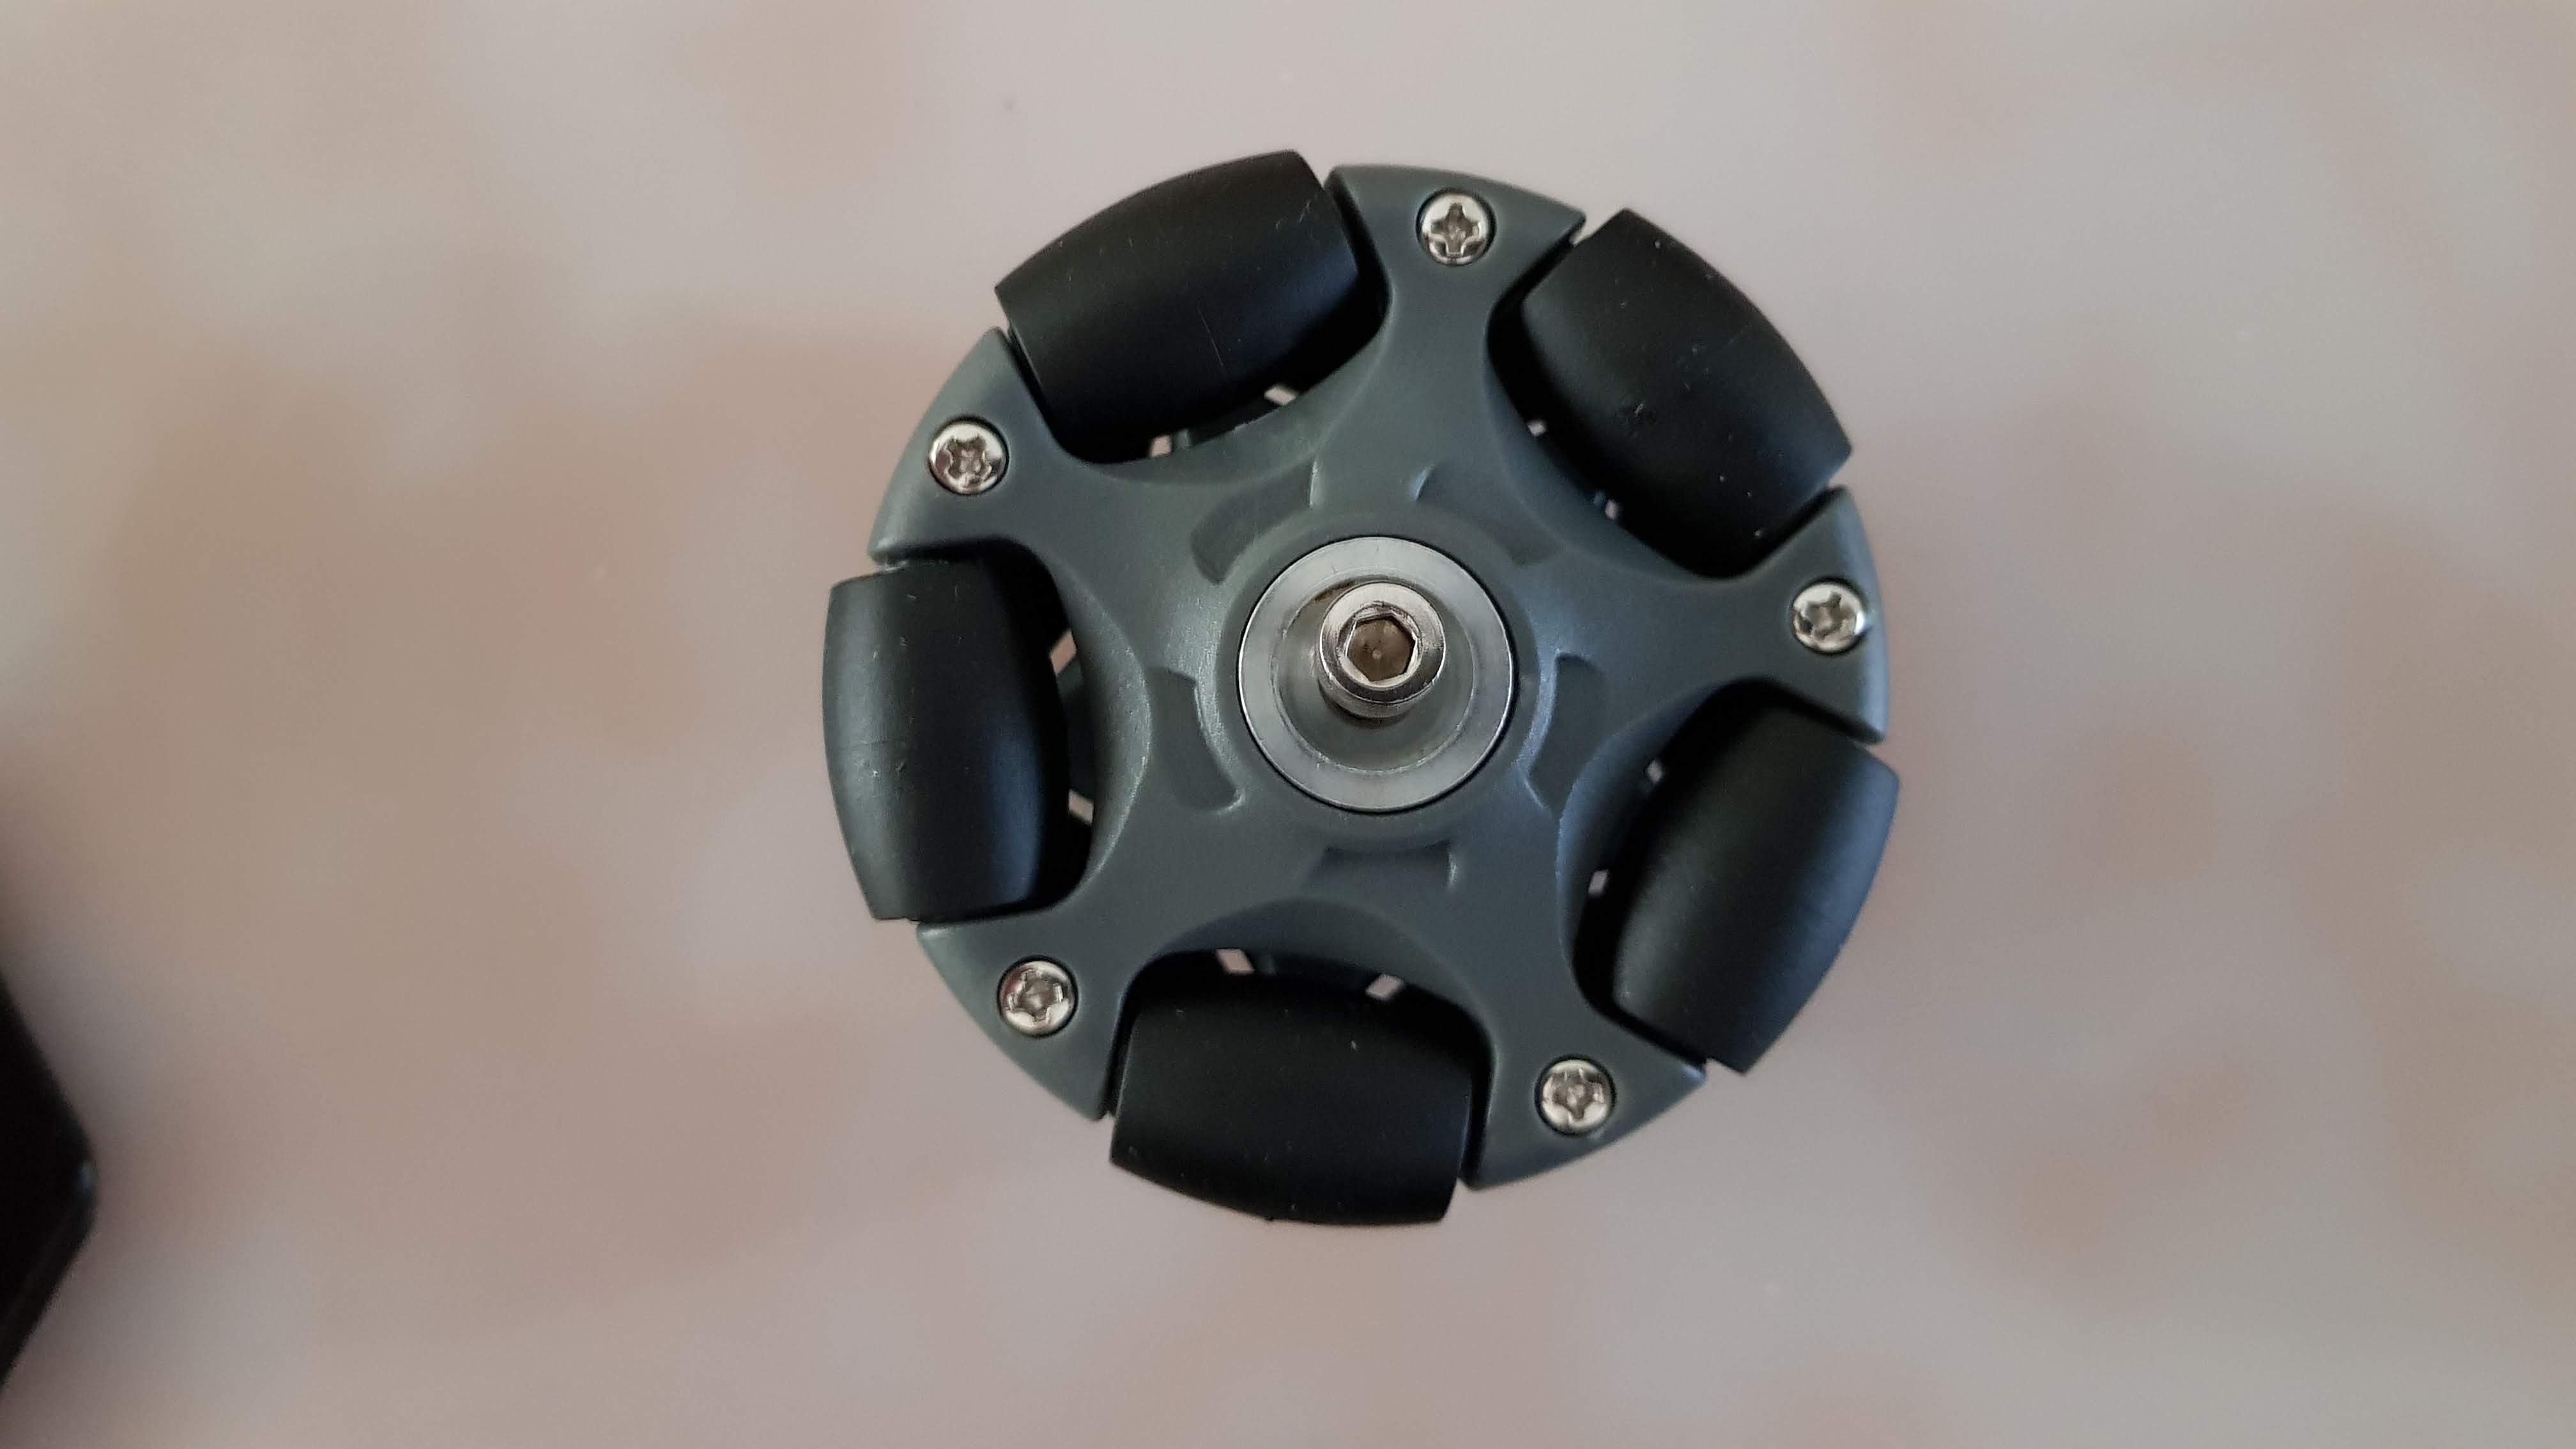
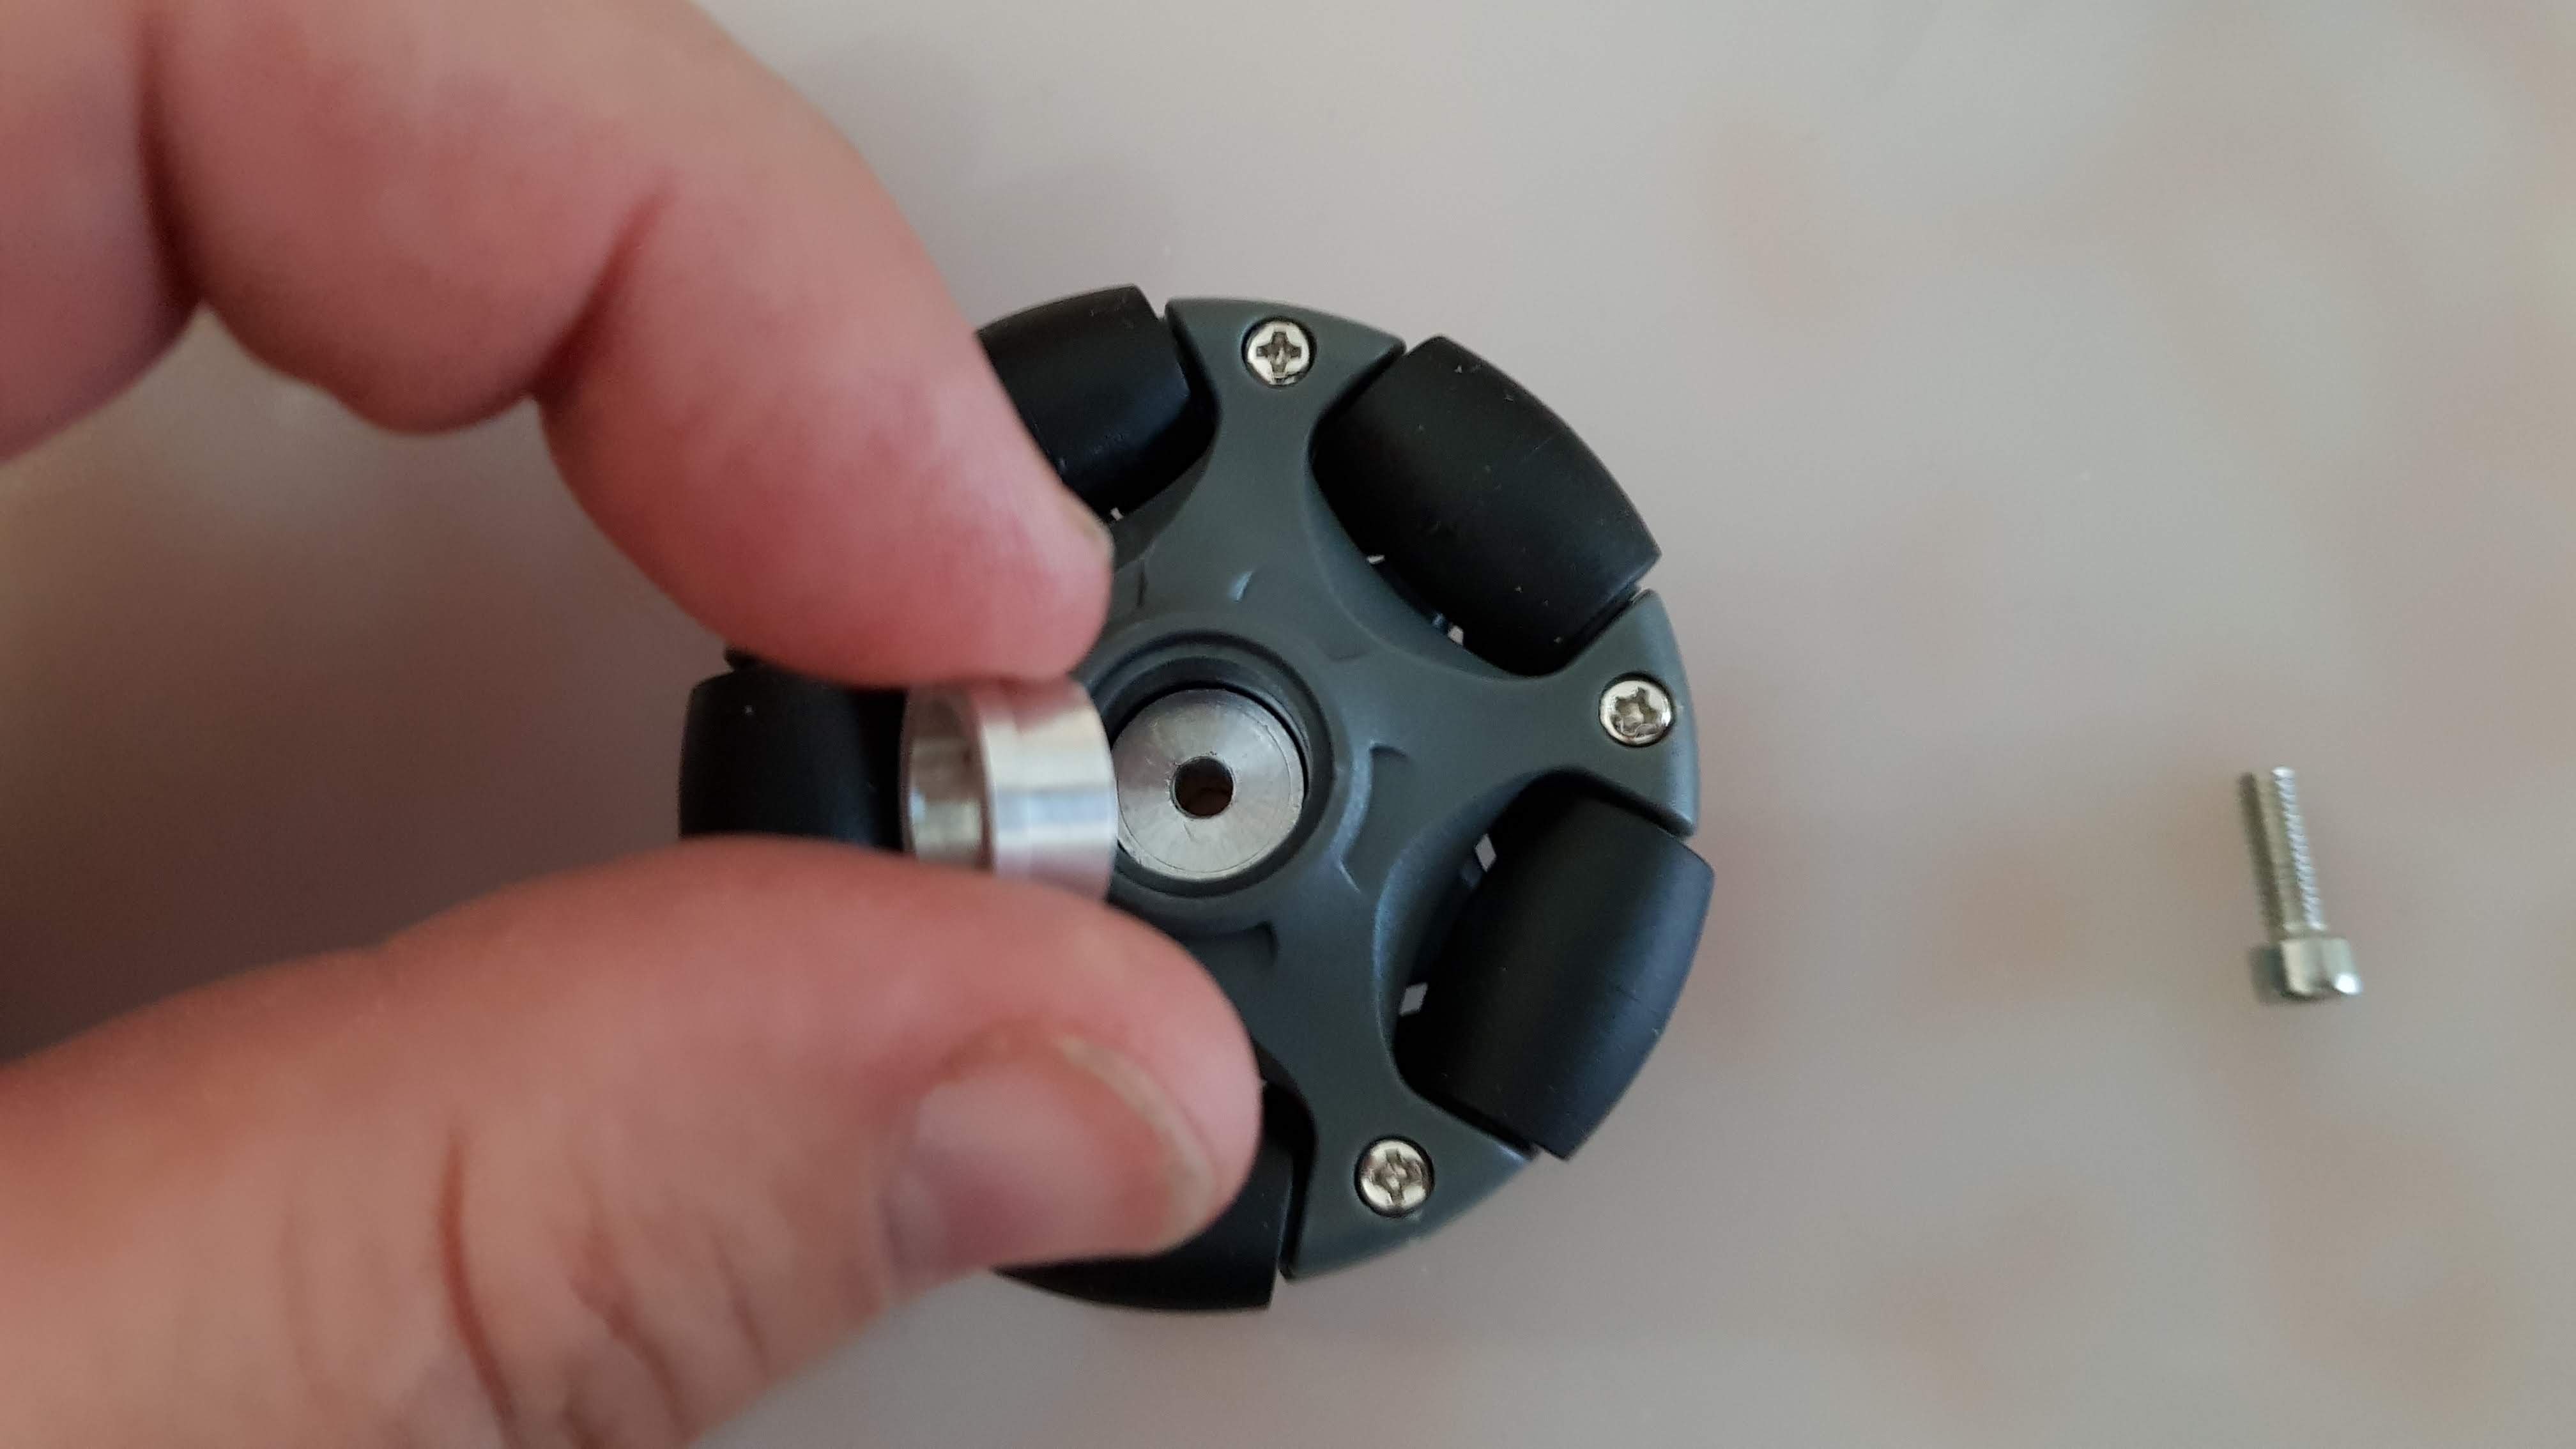
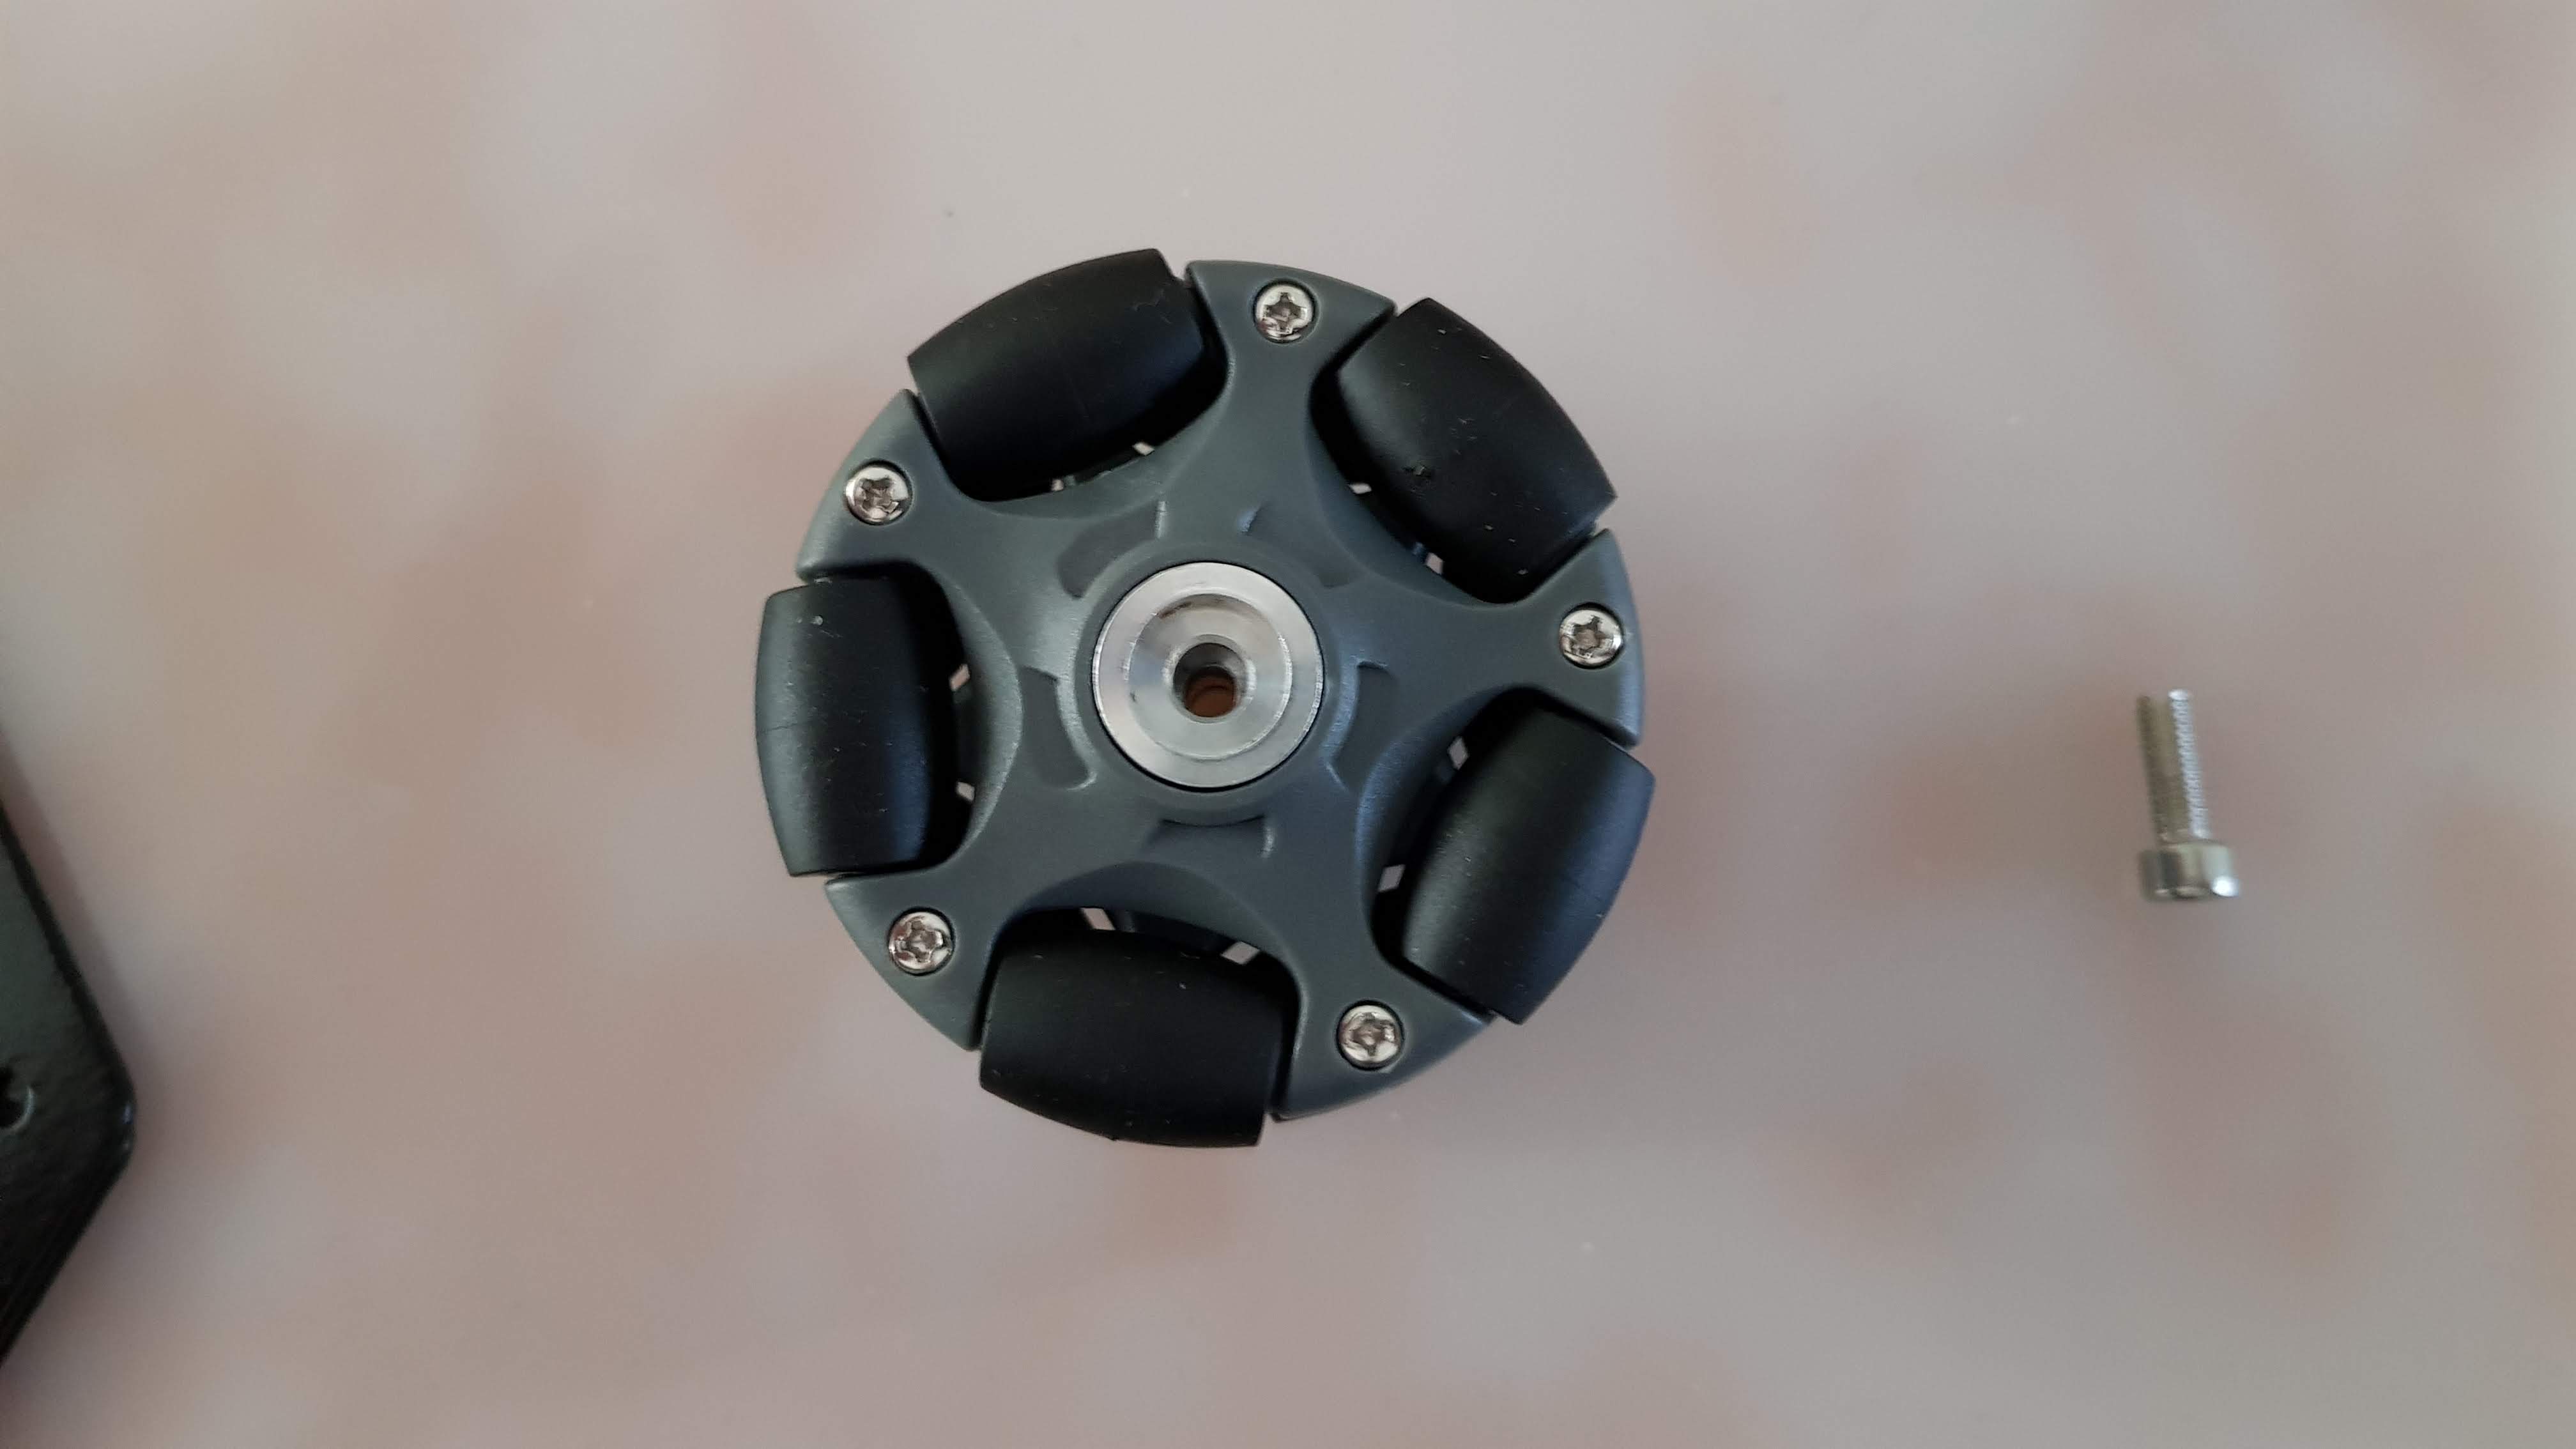
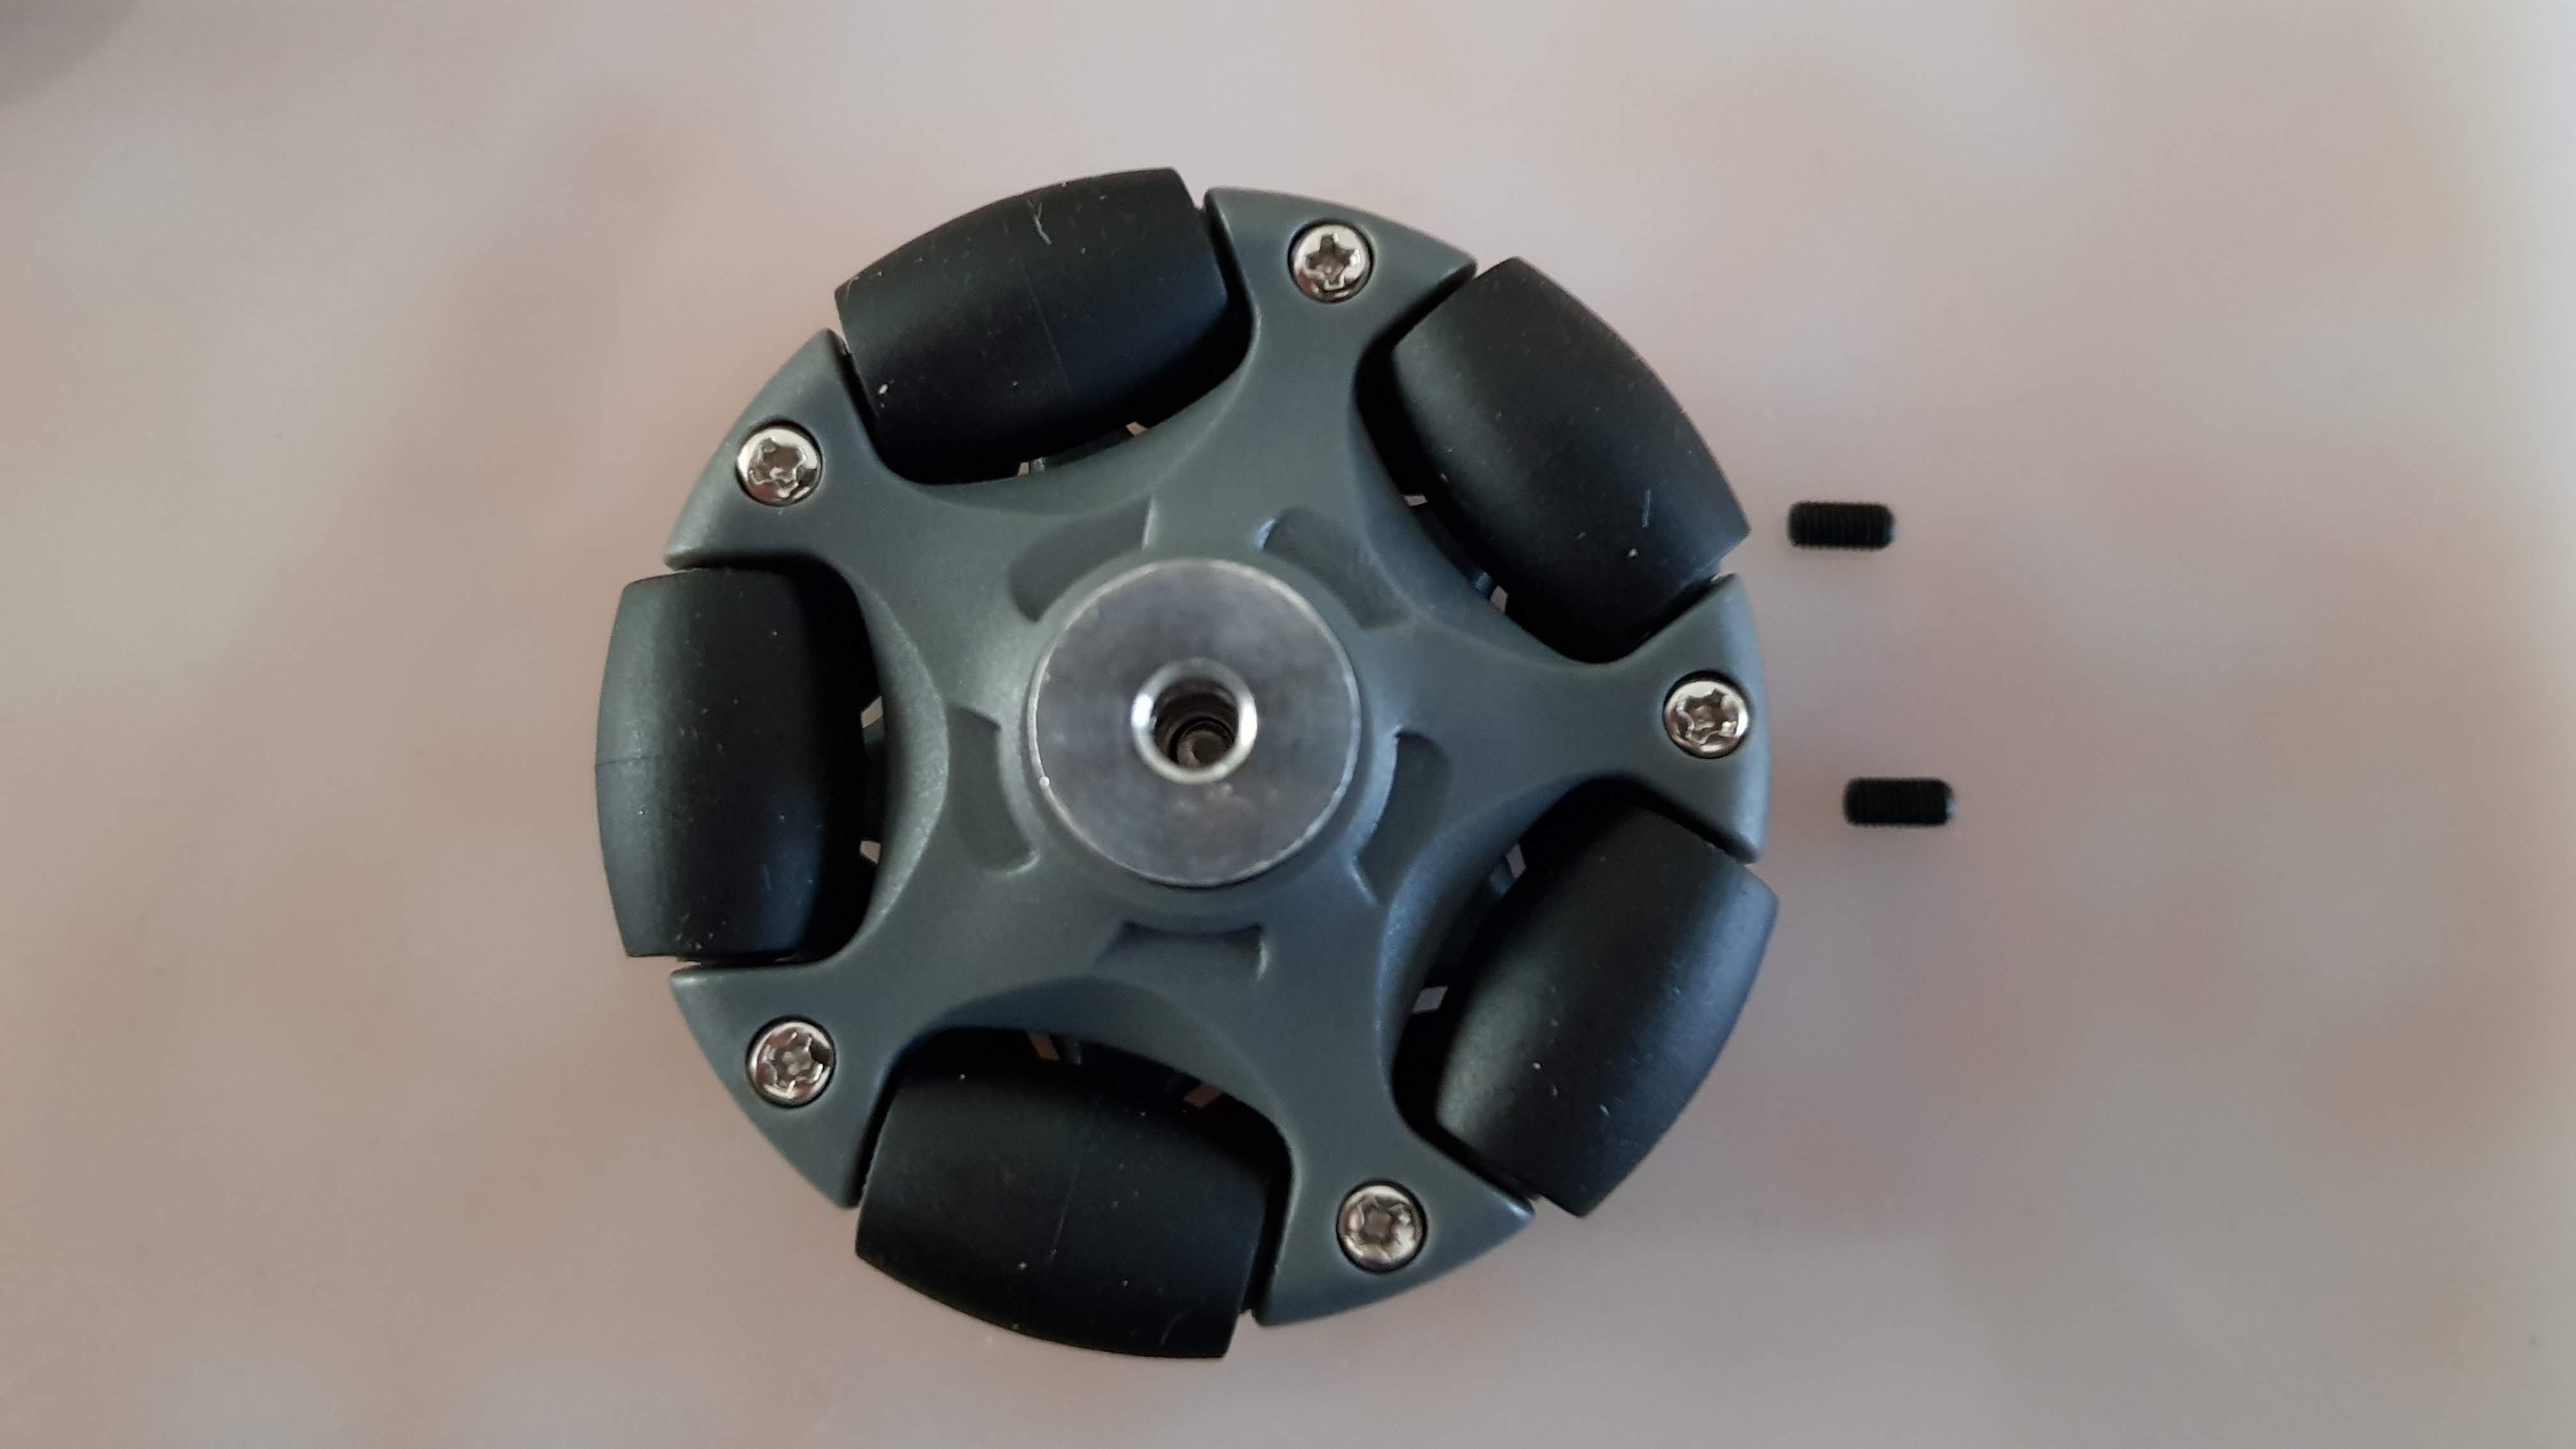
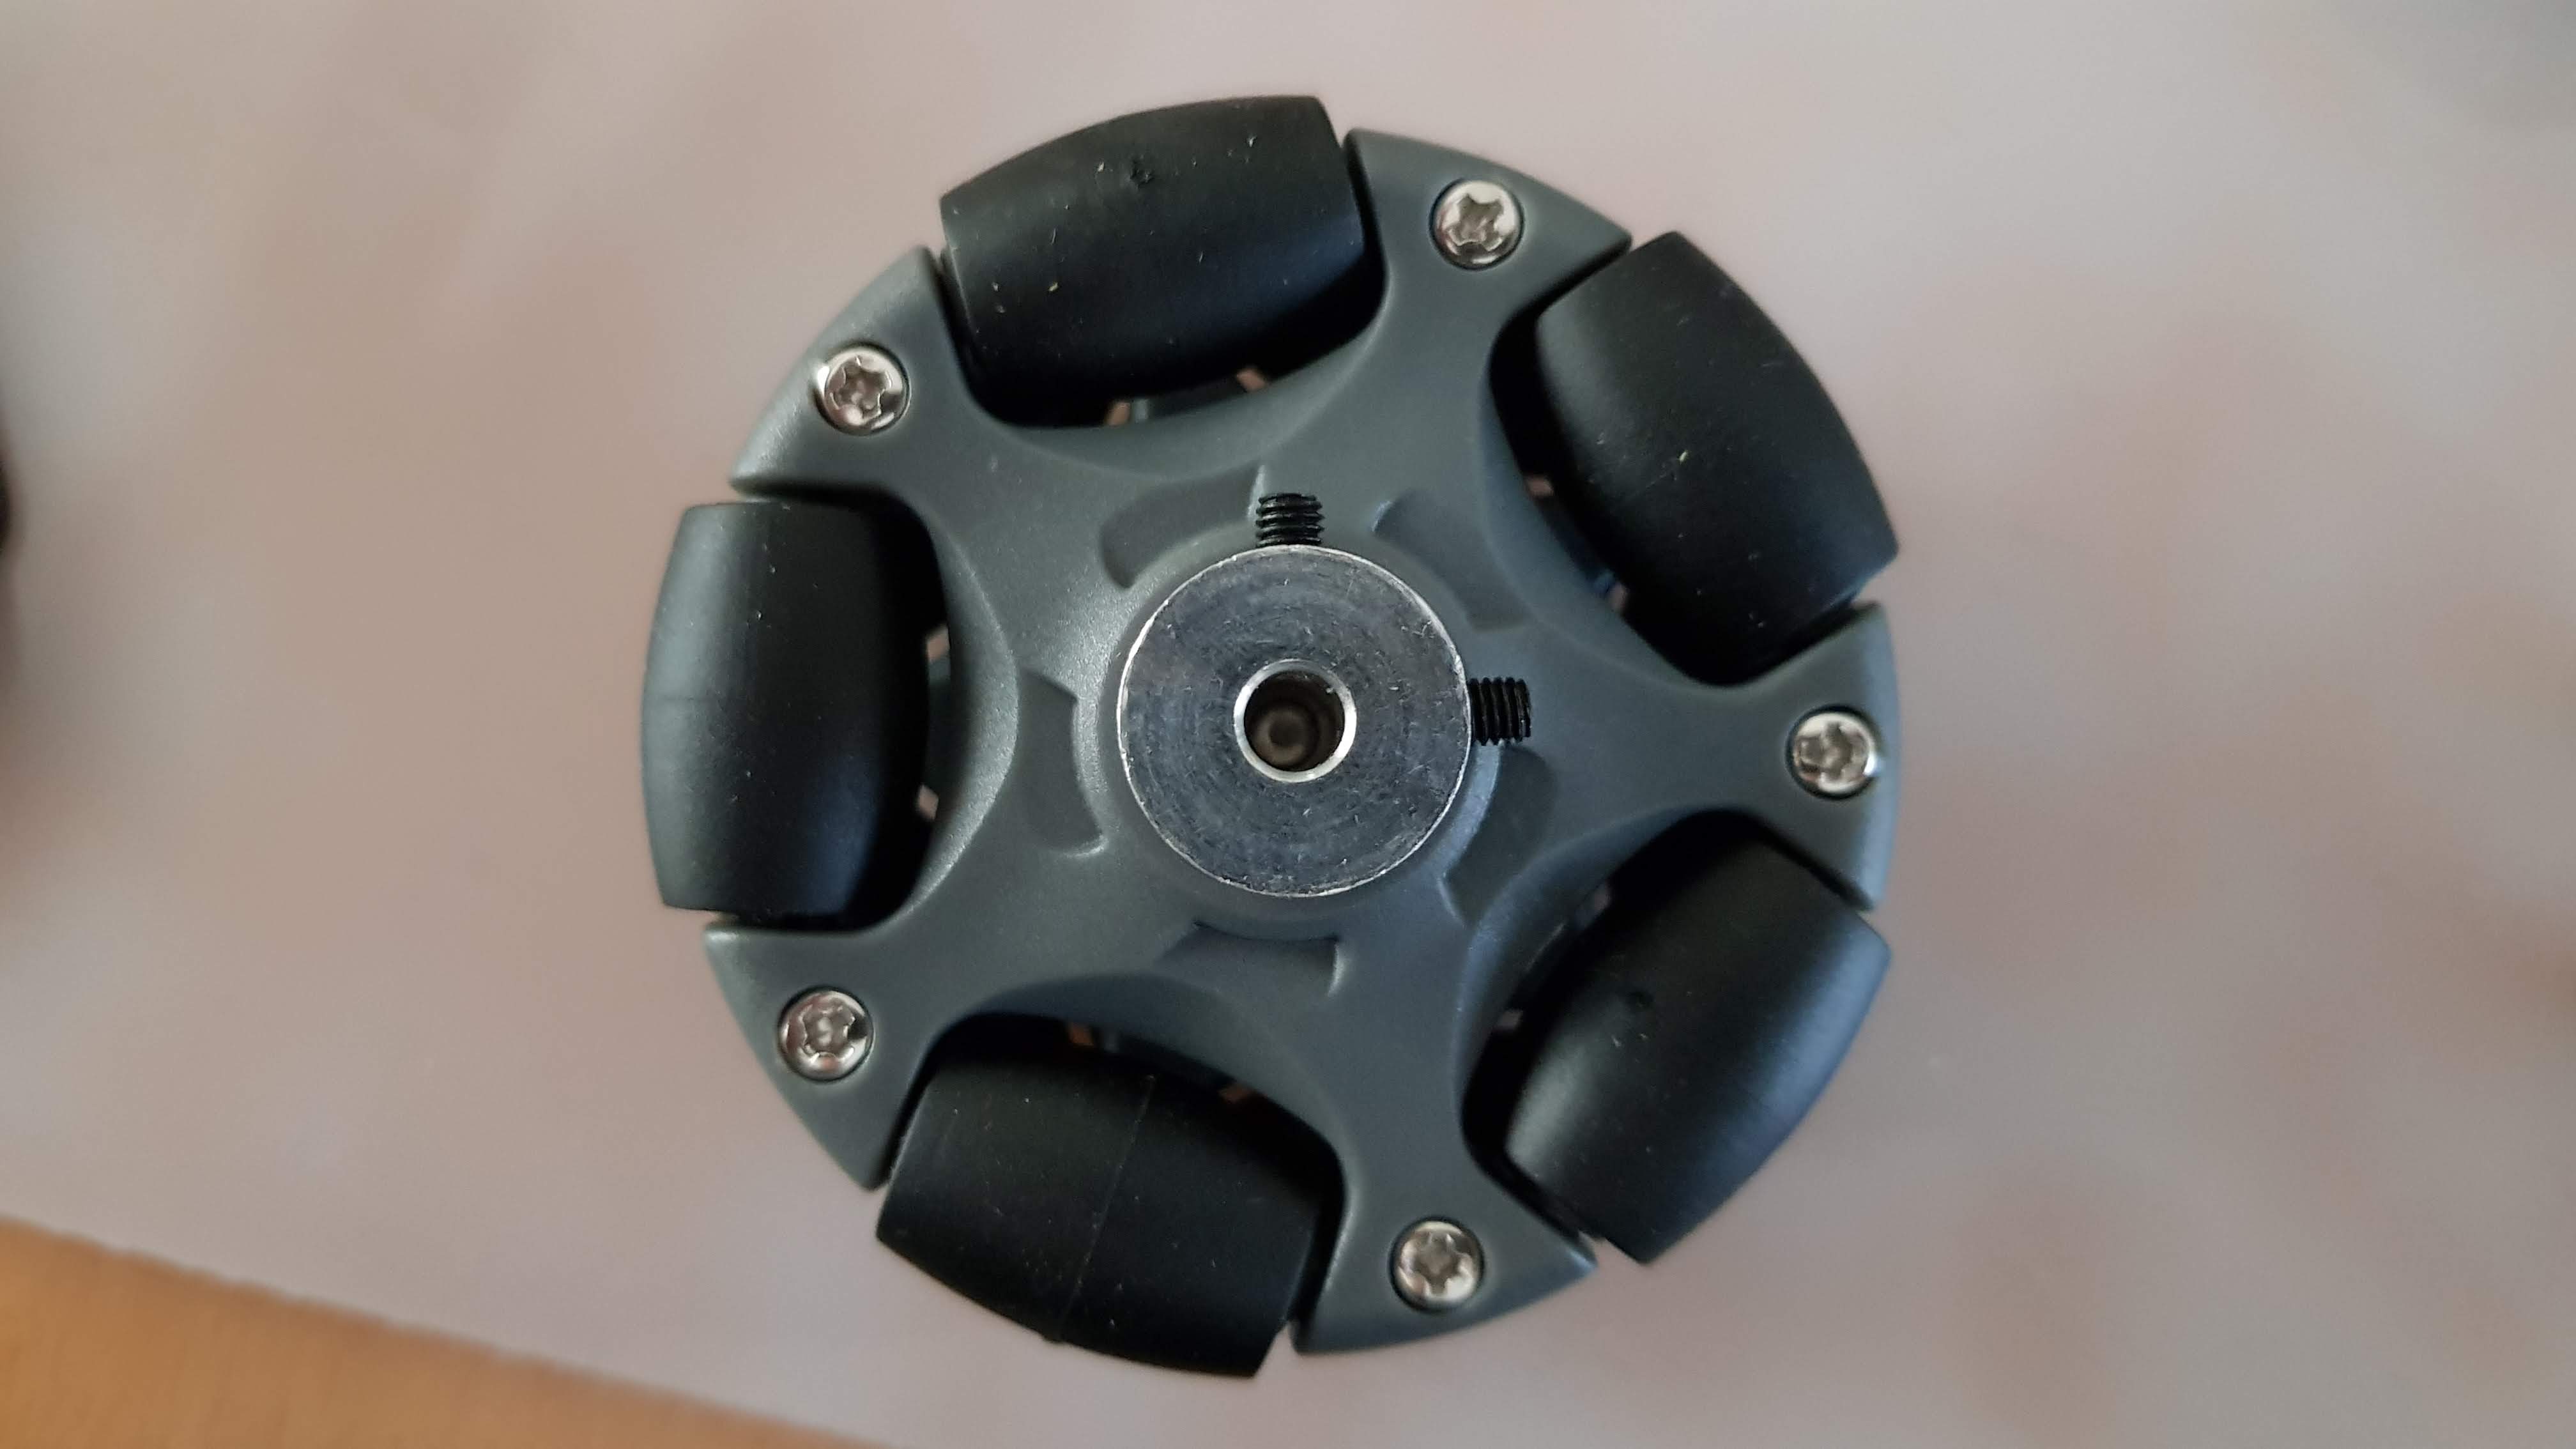
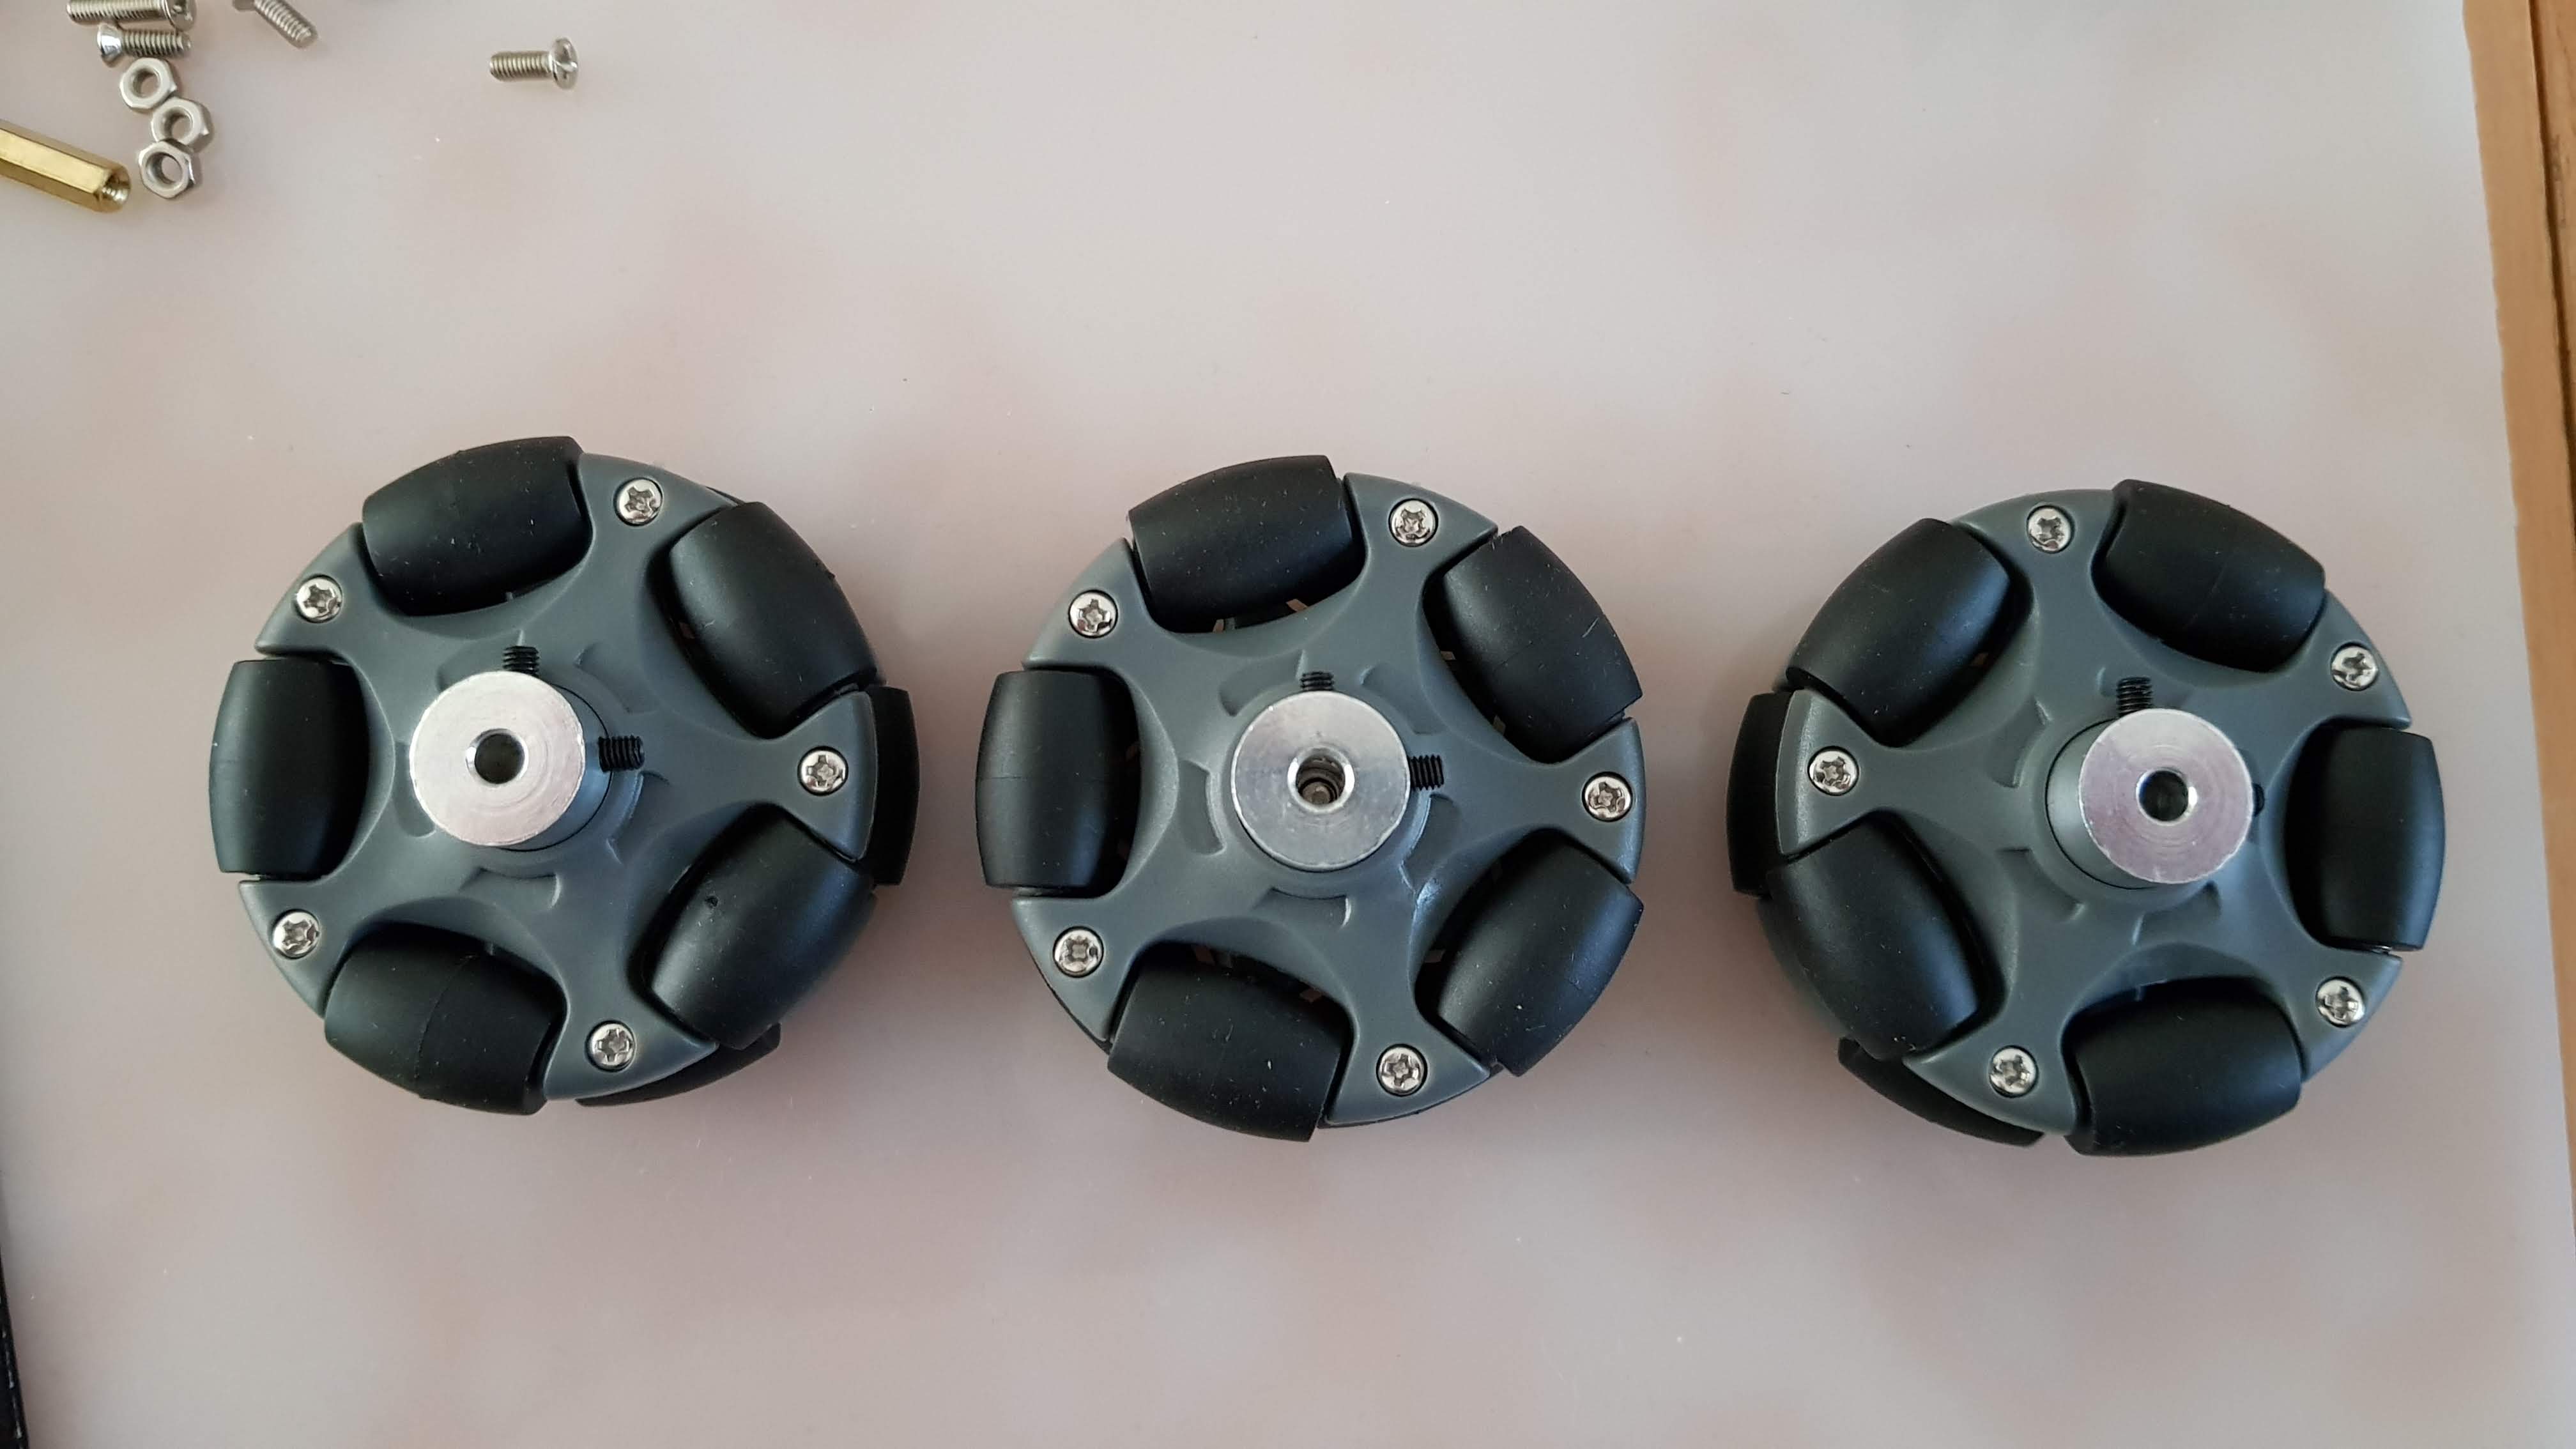
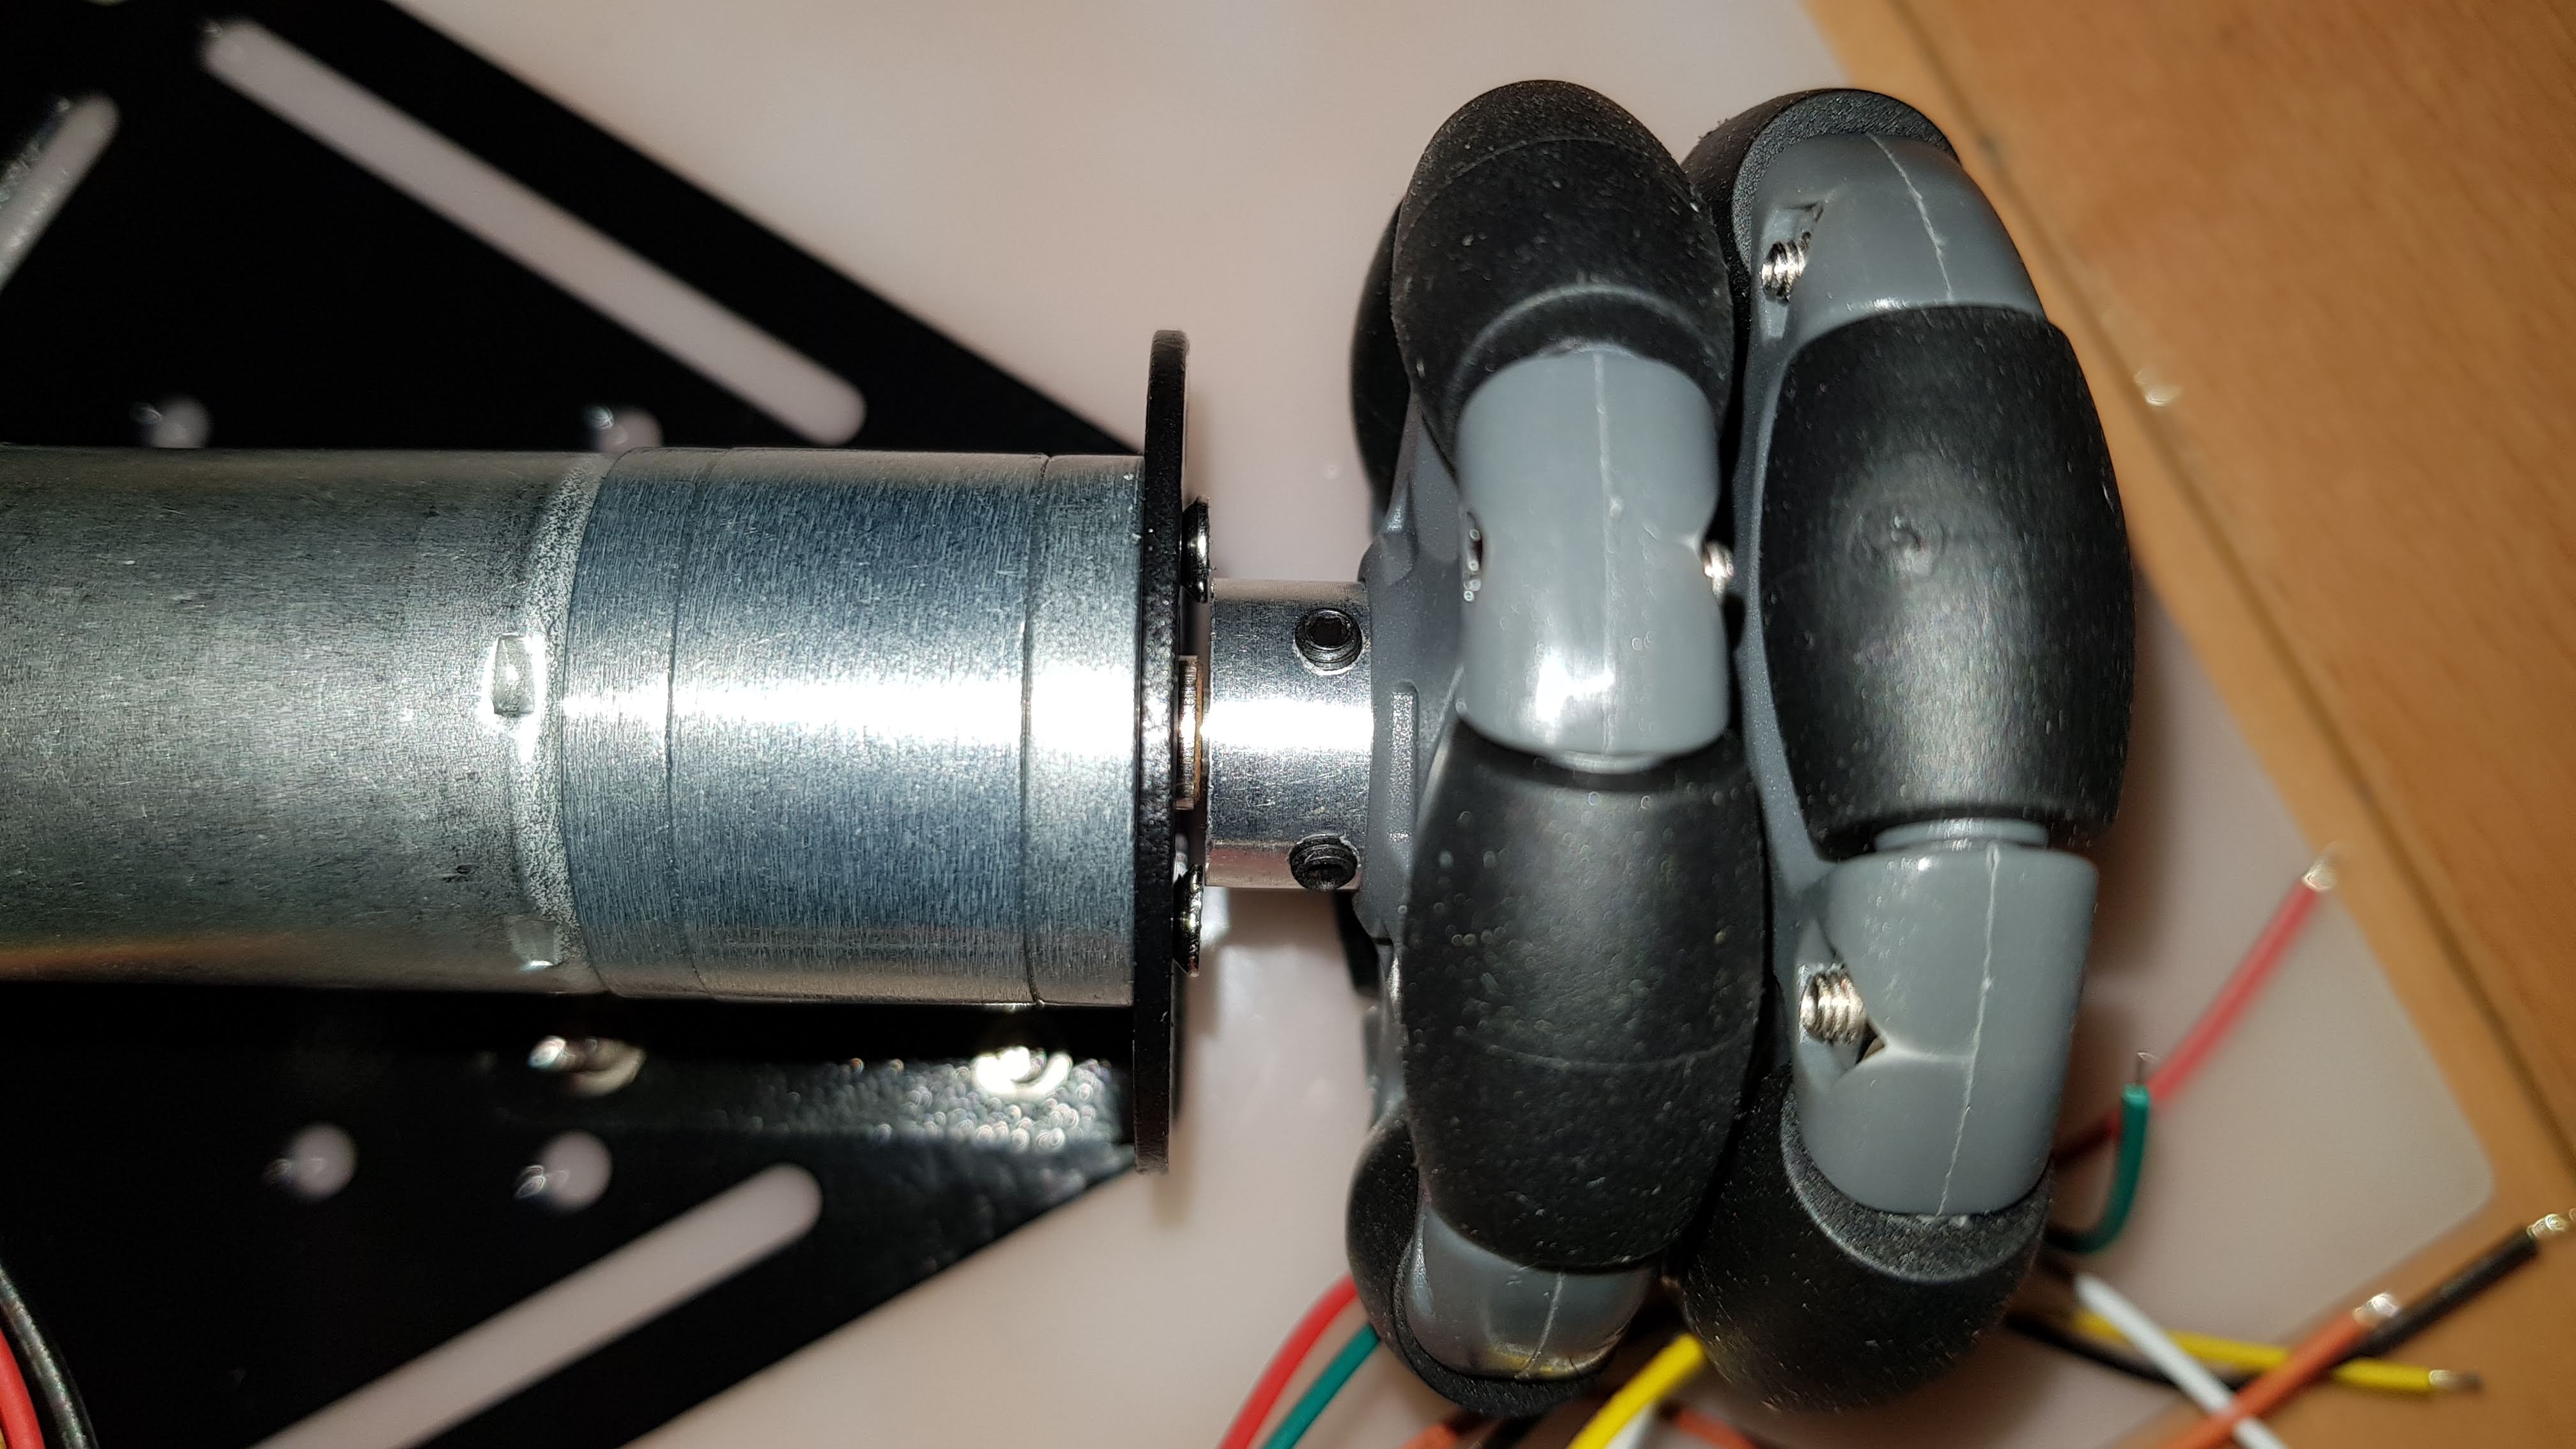
Das Omnirad ist schon zusammengebaut, es muss nur noch die Aufnahme für die Achse eingesetzt und festgeschraubt werden. Hier erstmal die Bestandteile ohne Madenschrauben:
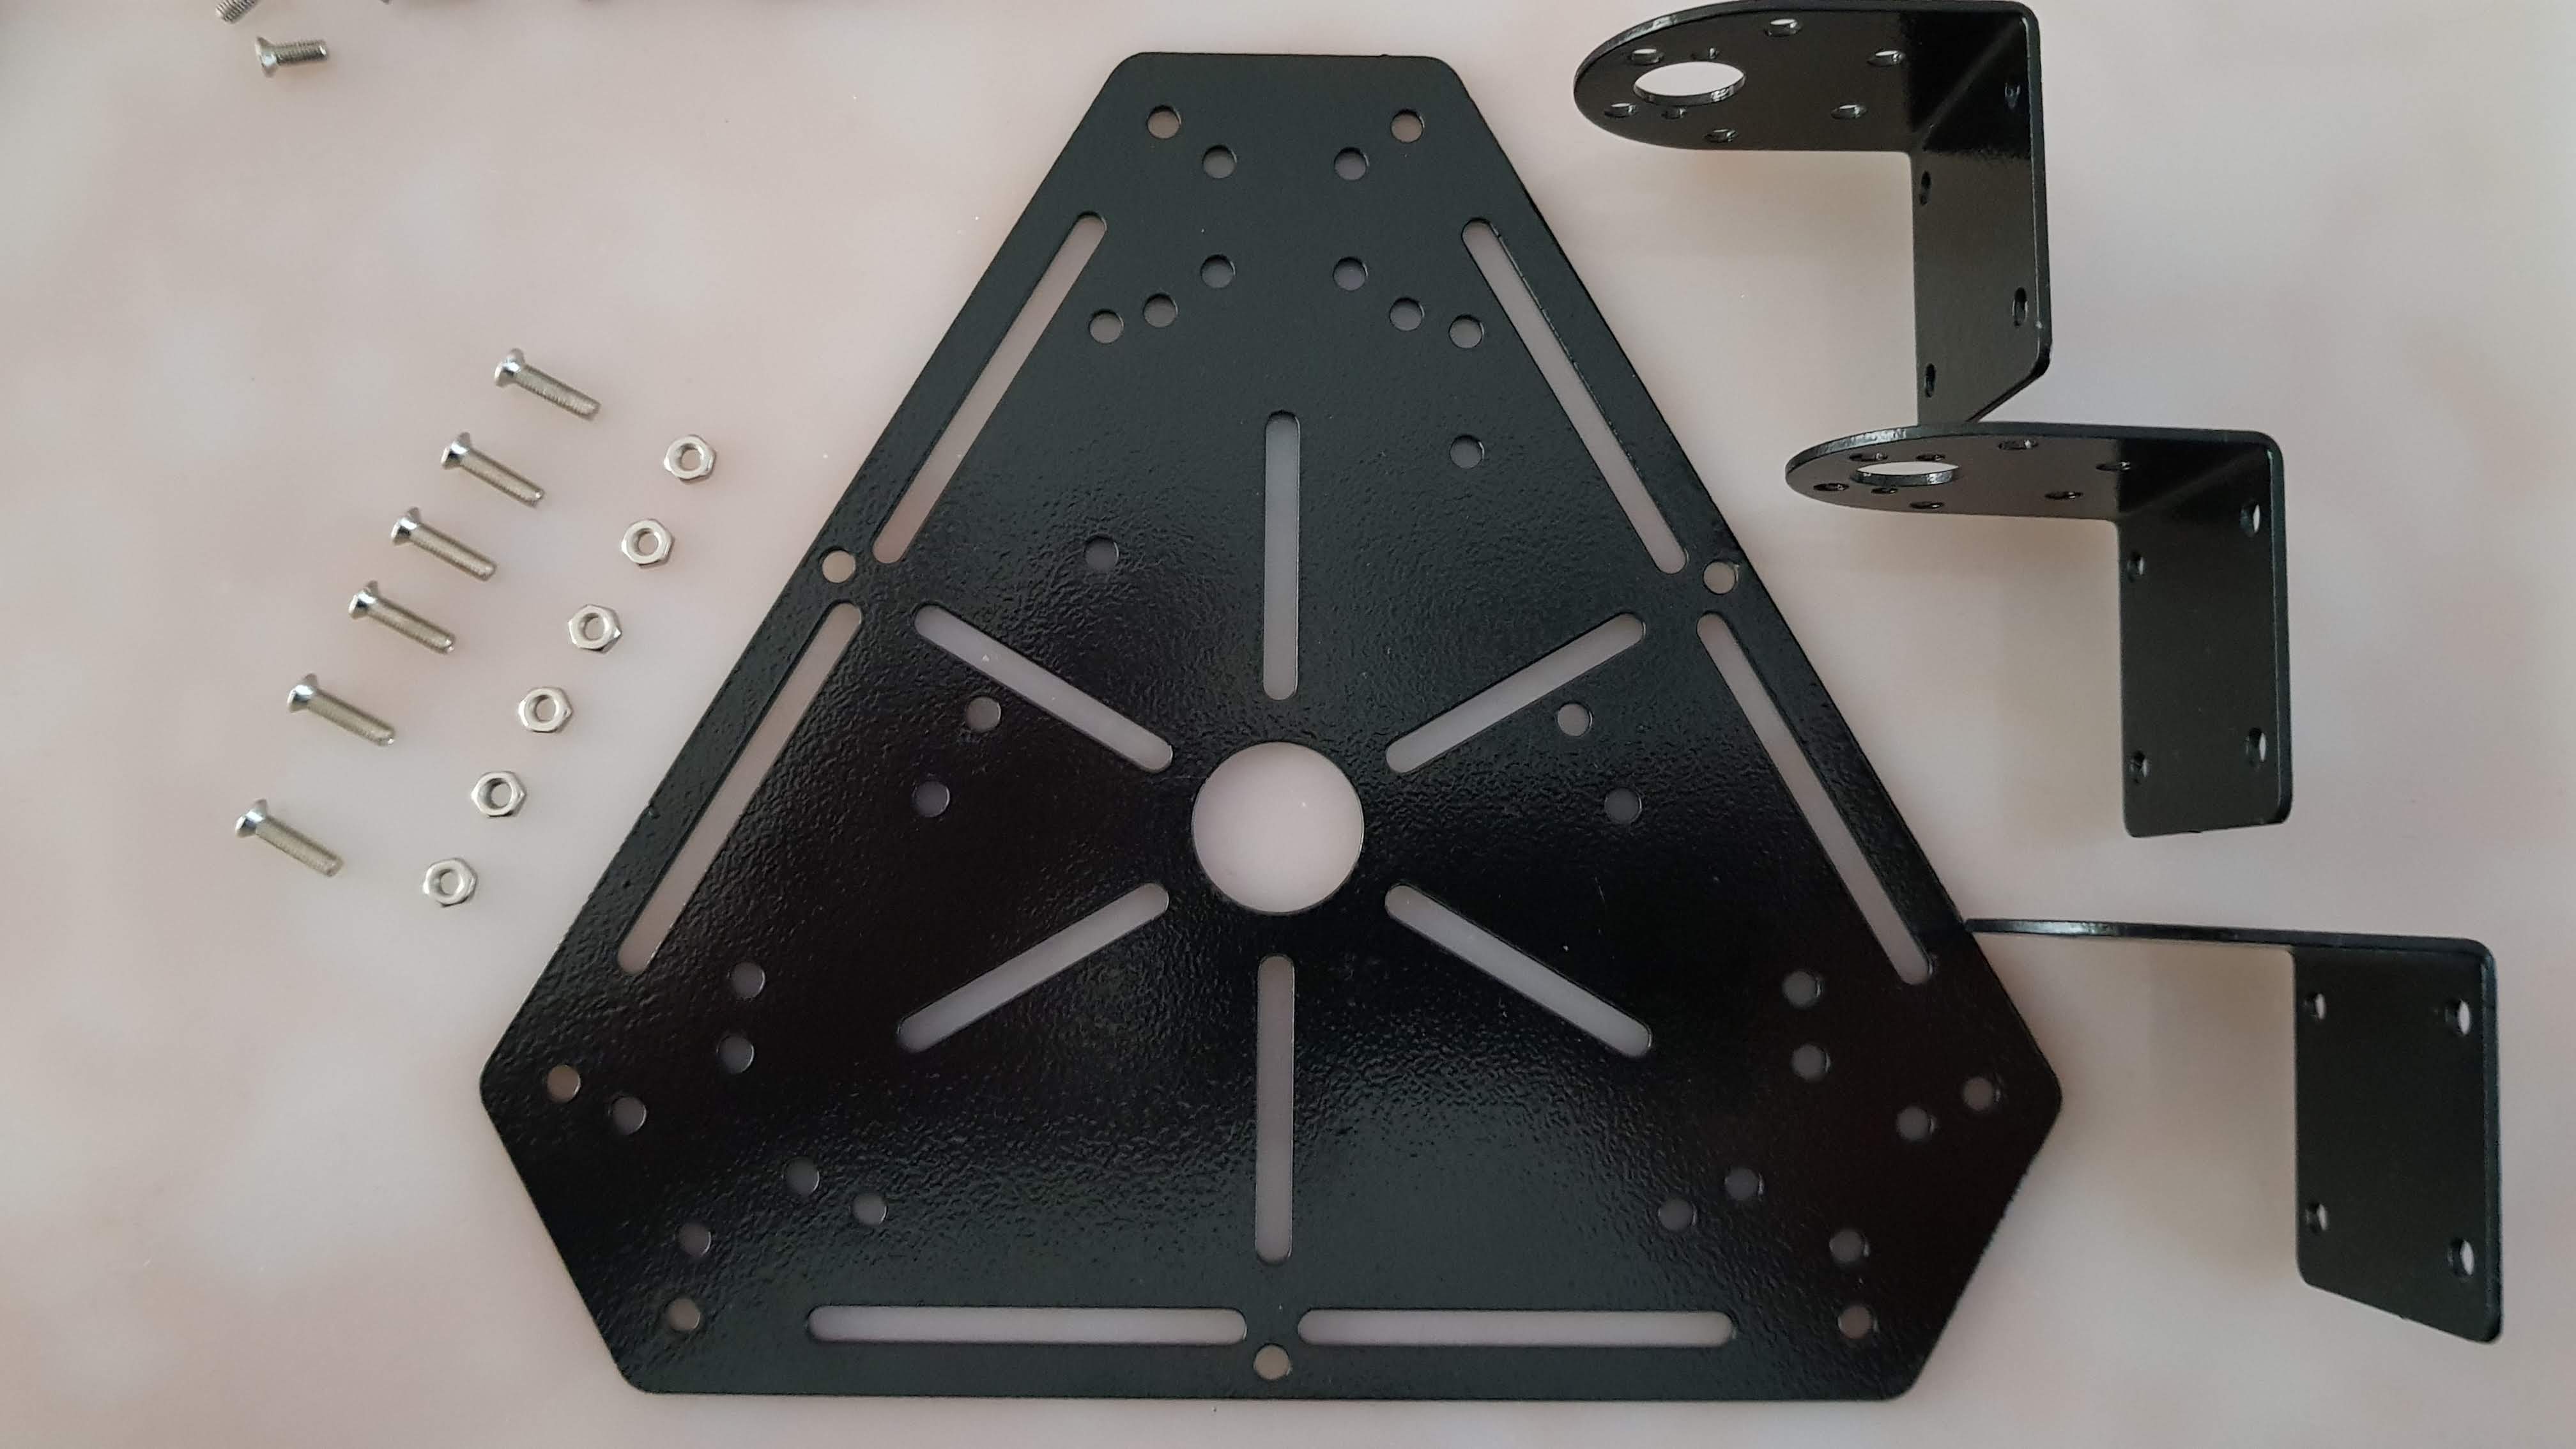
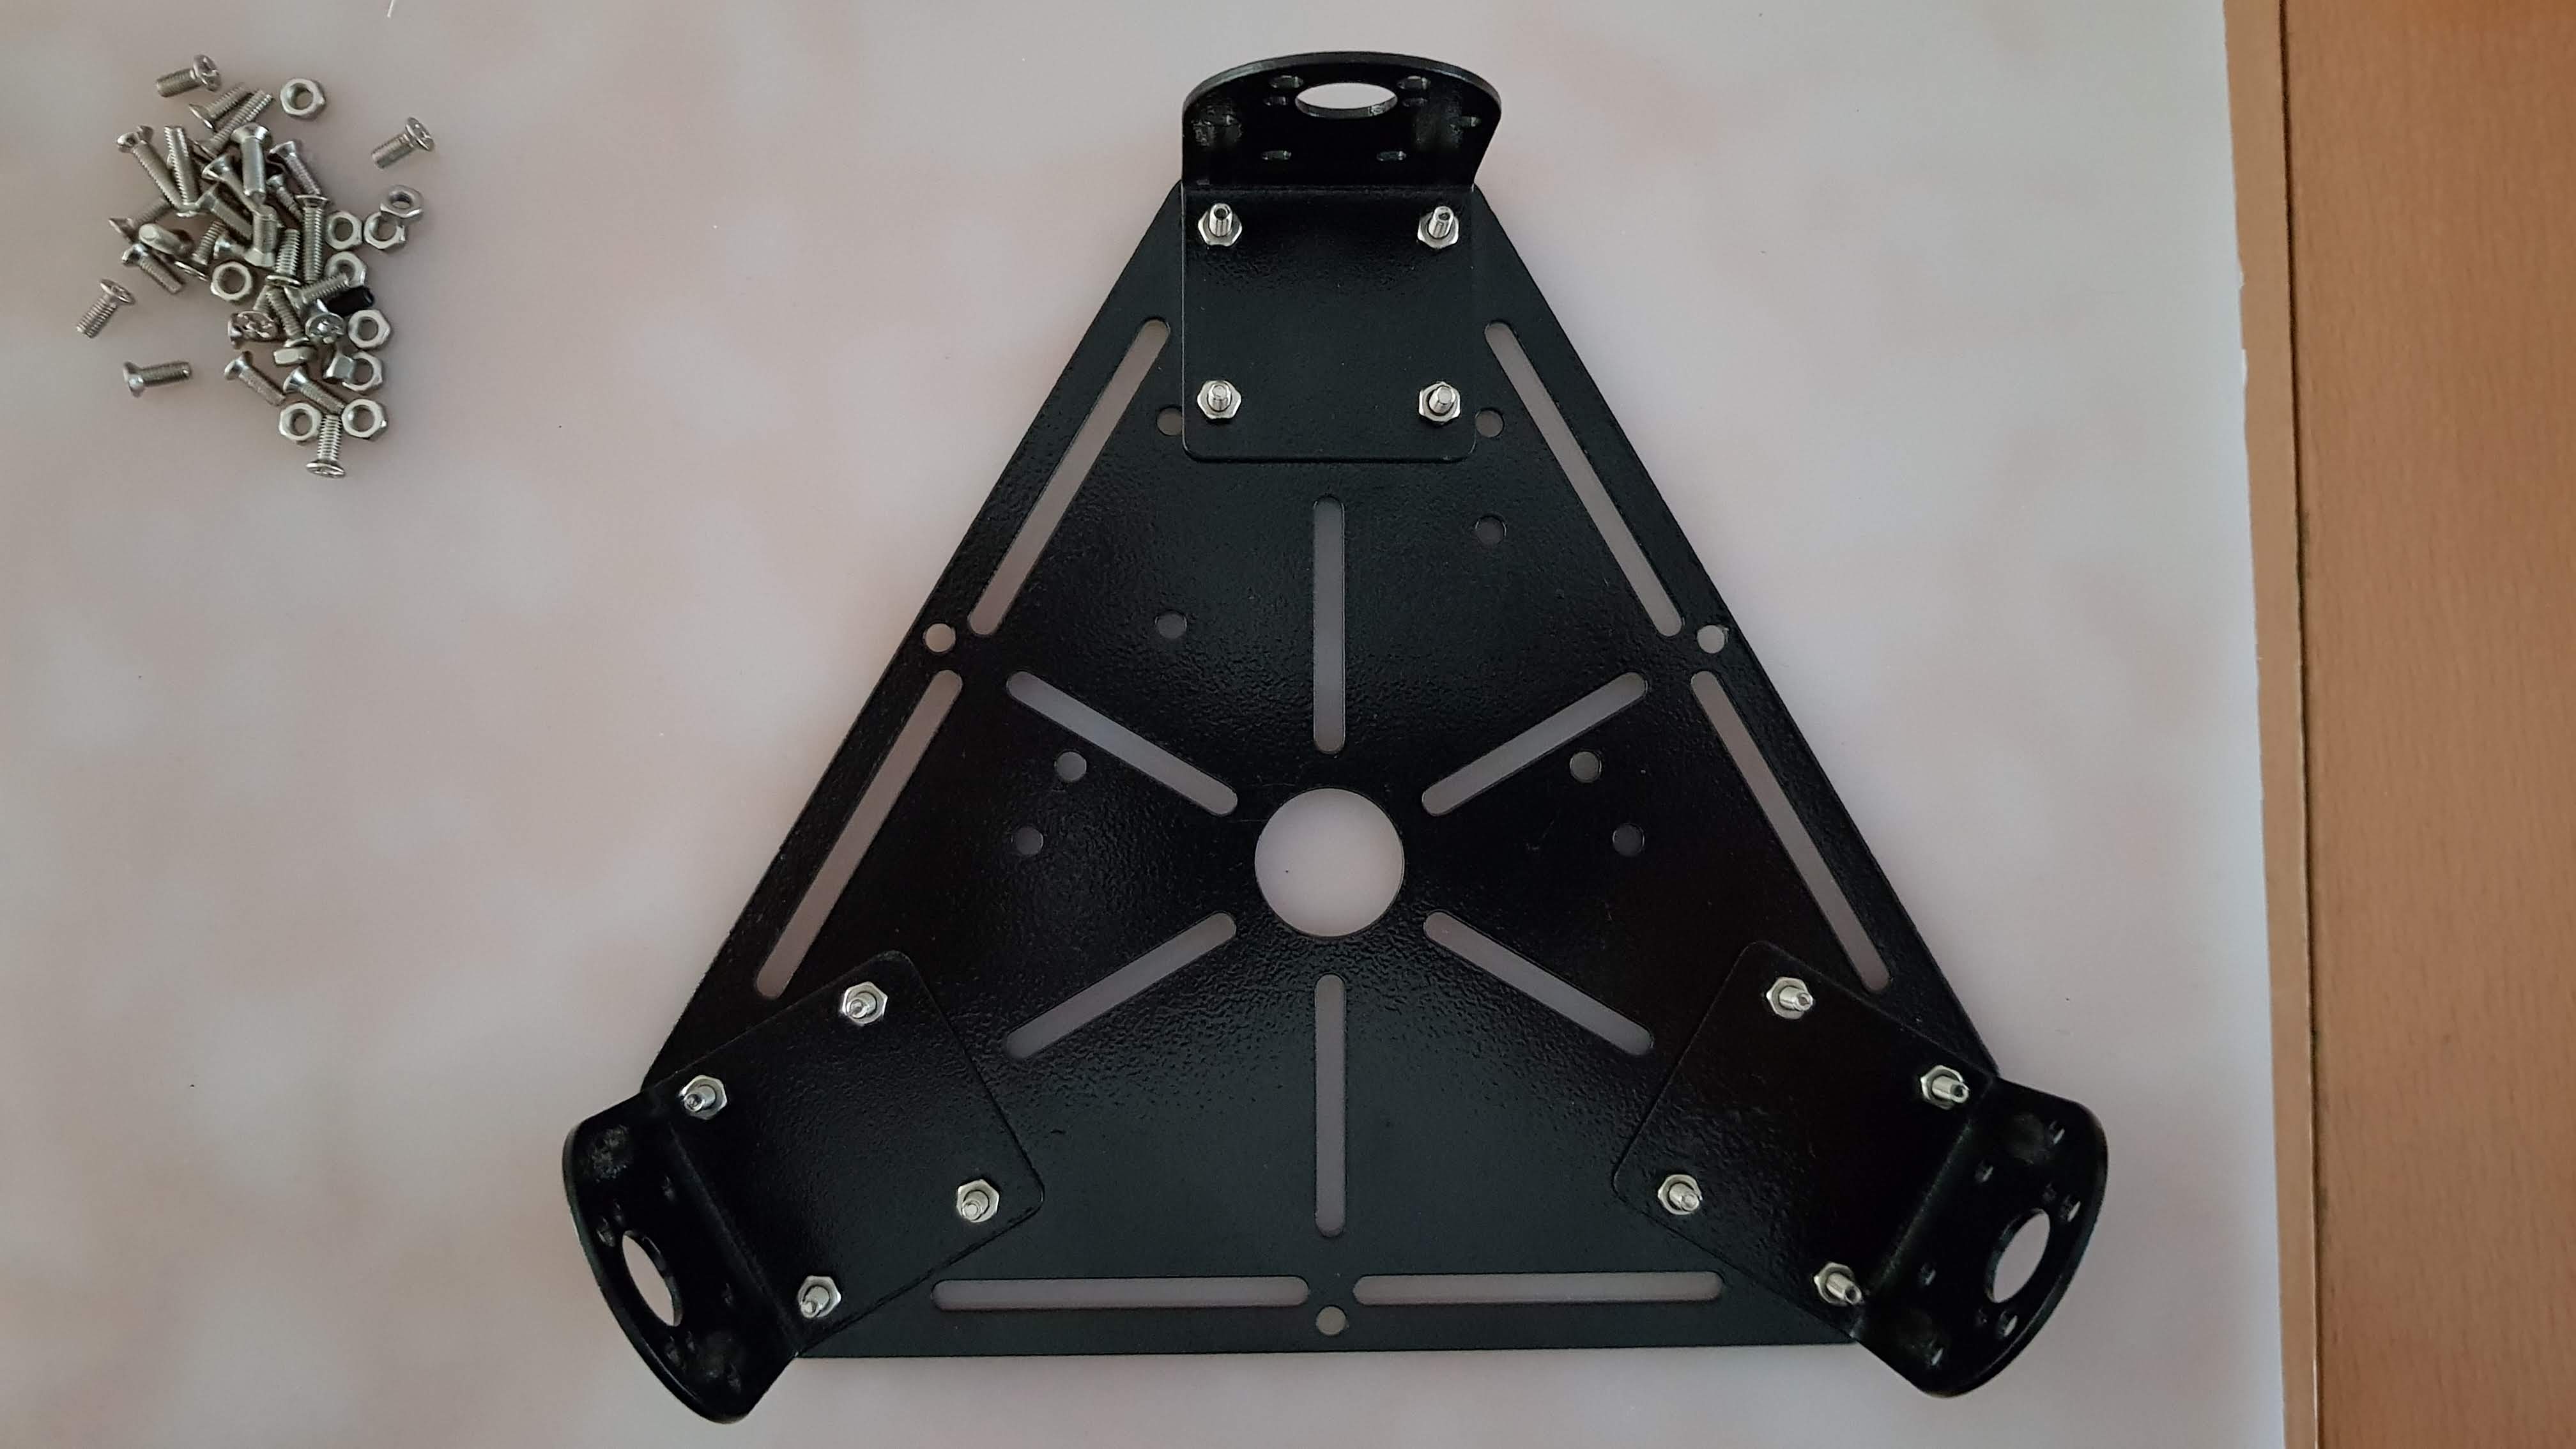
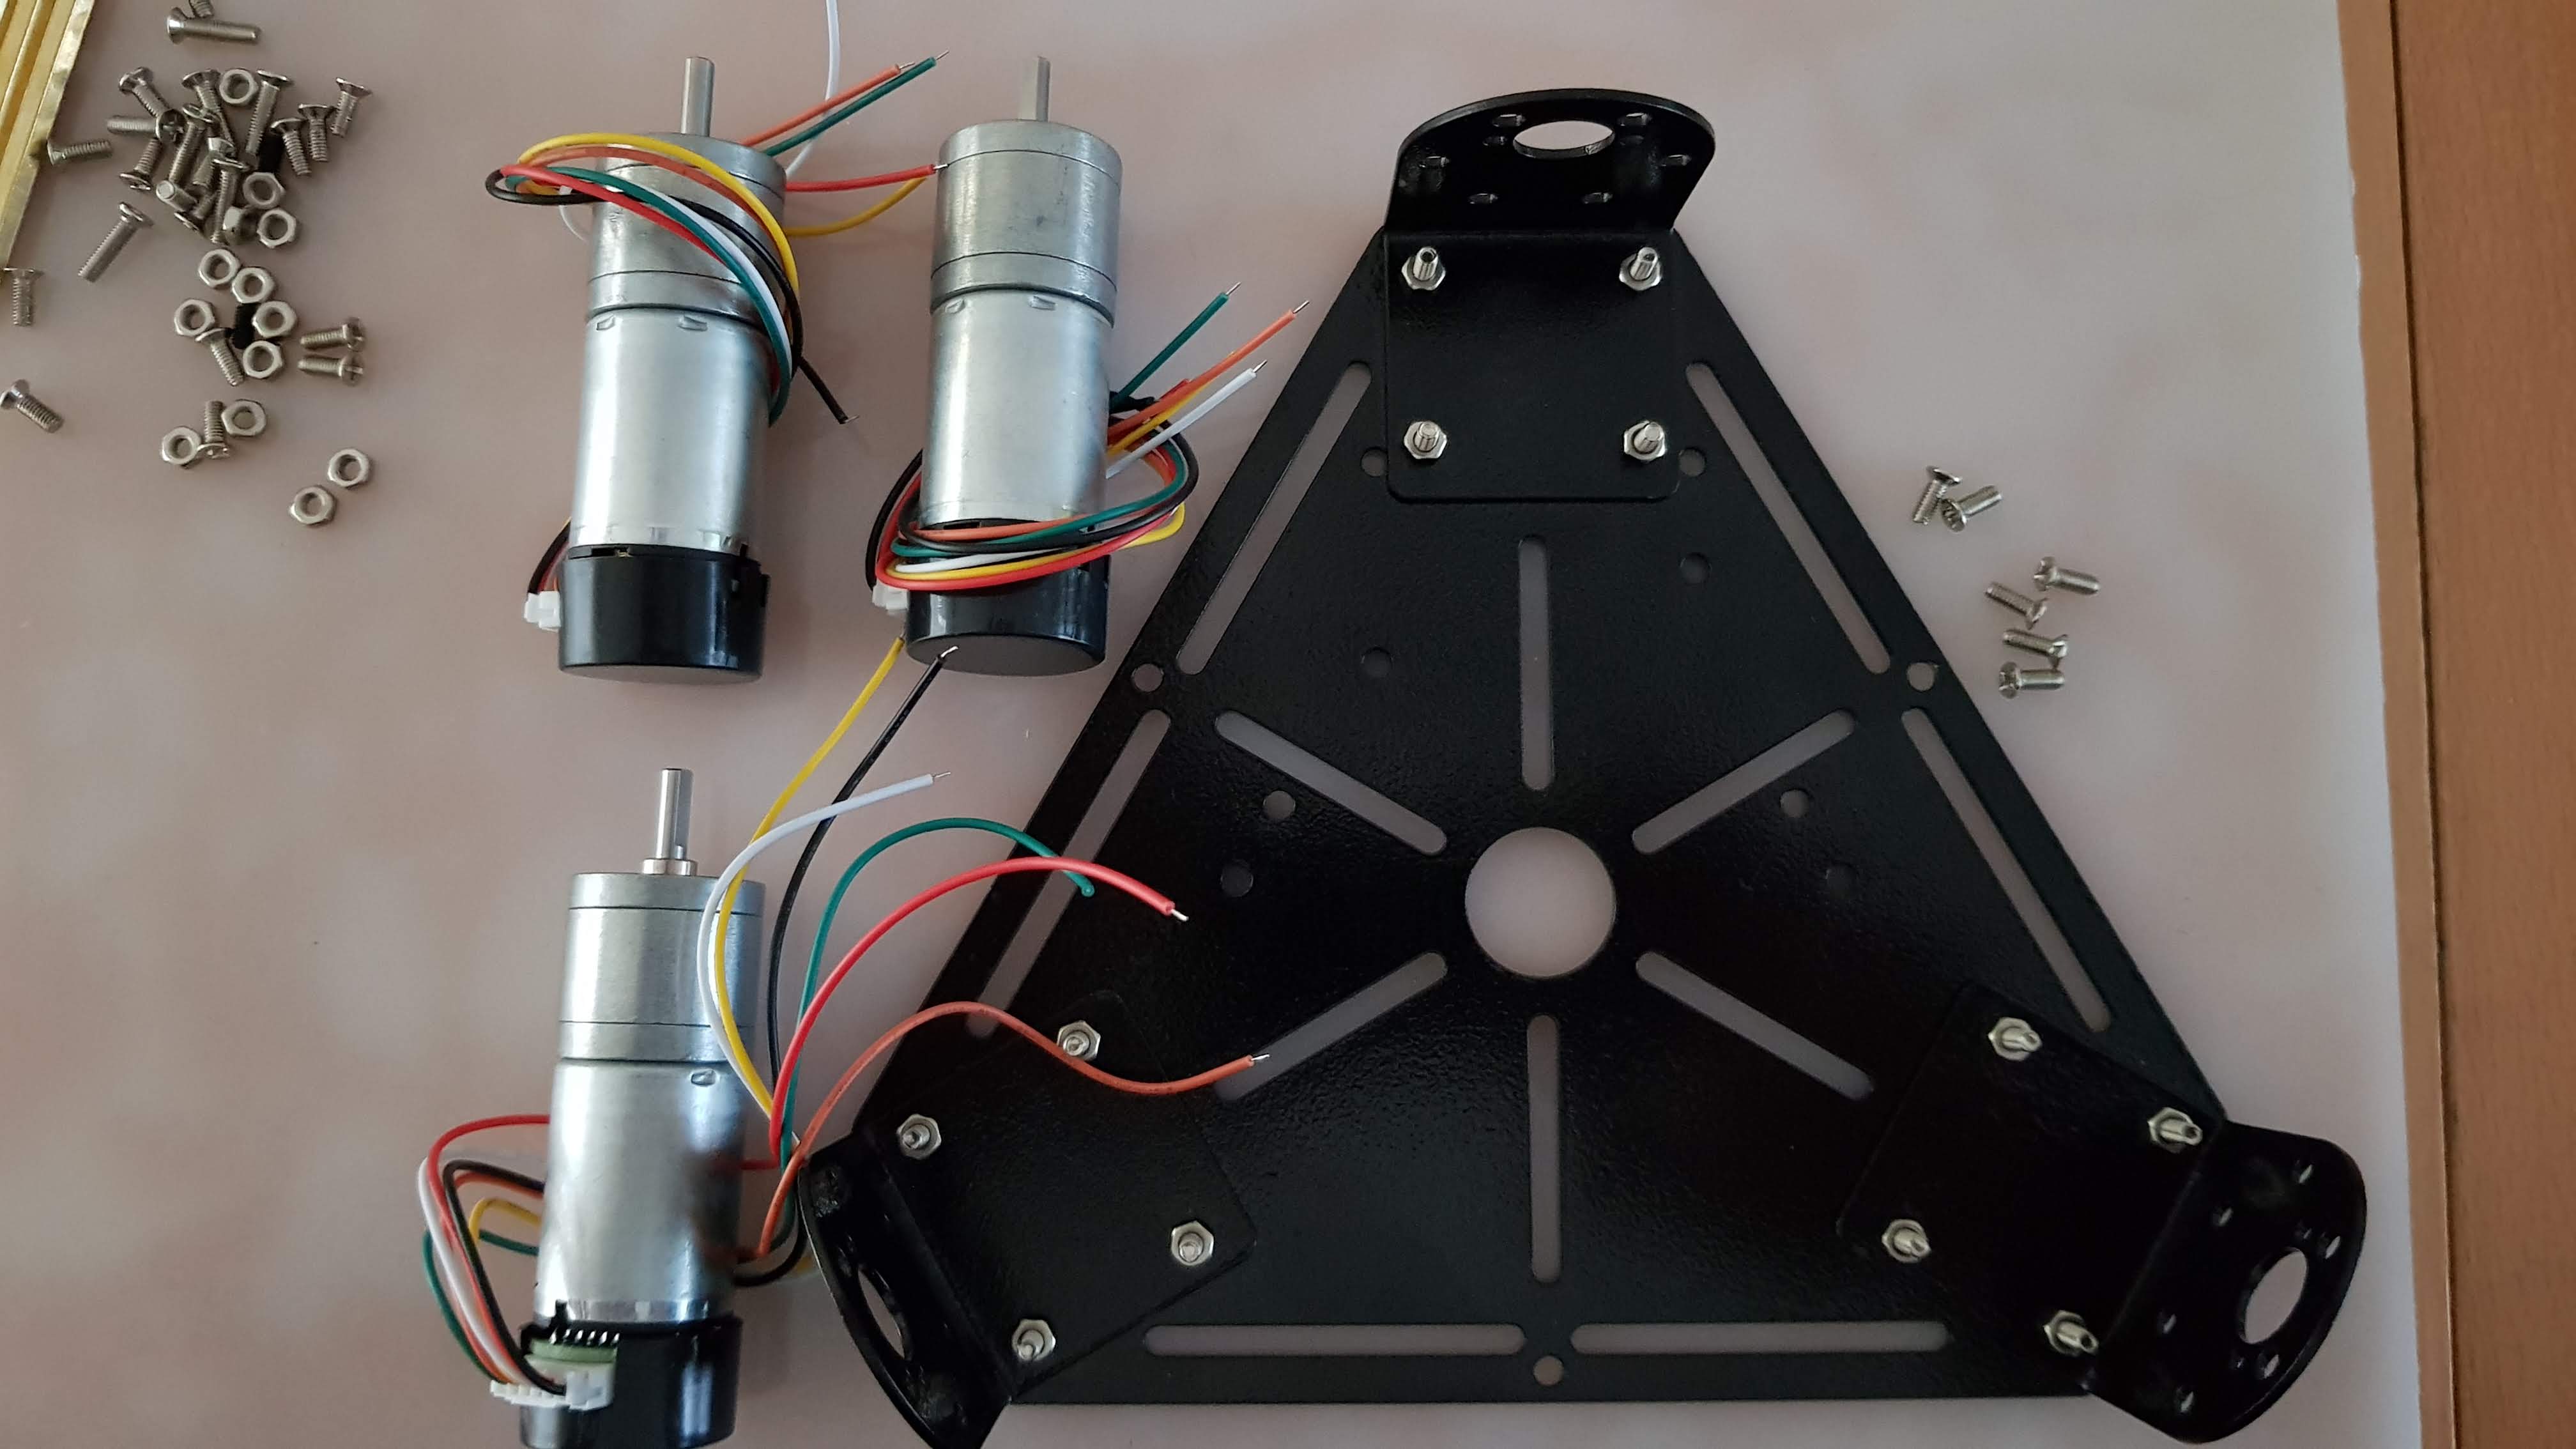
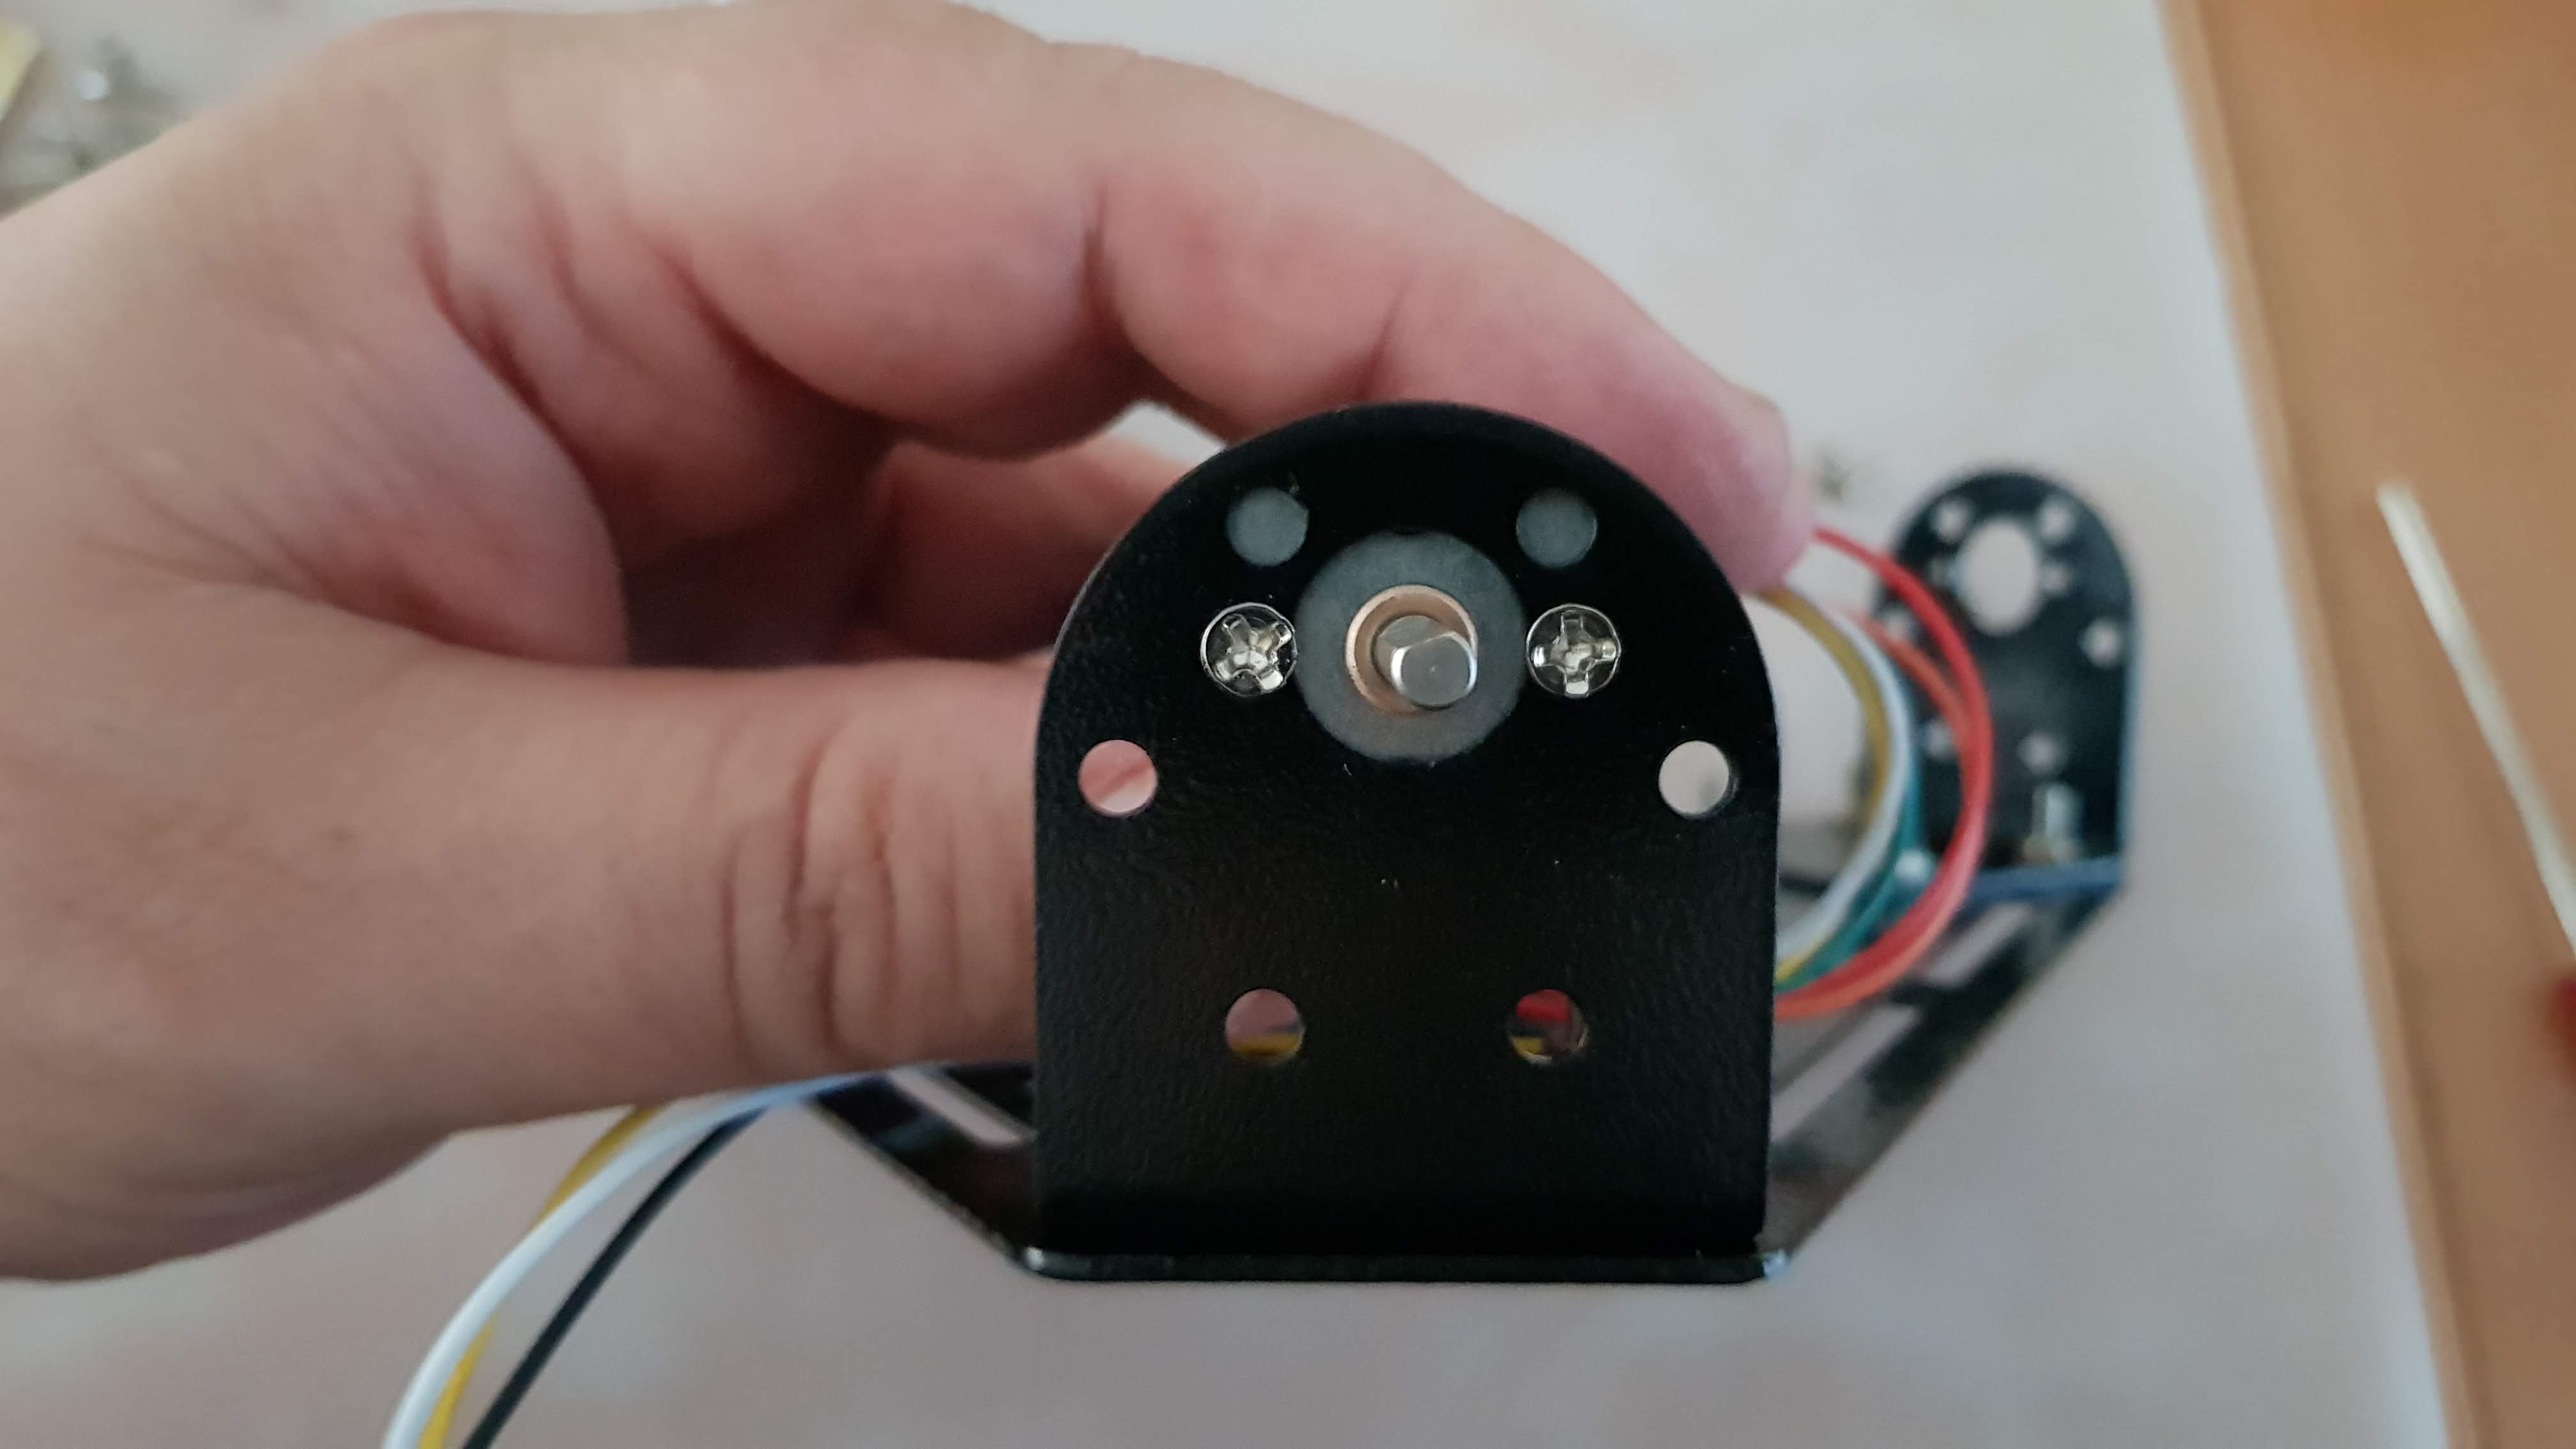
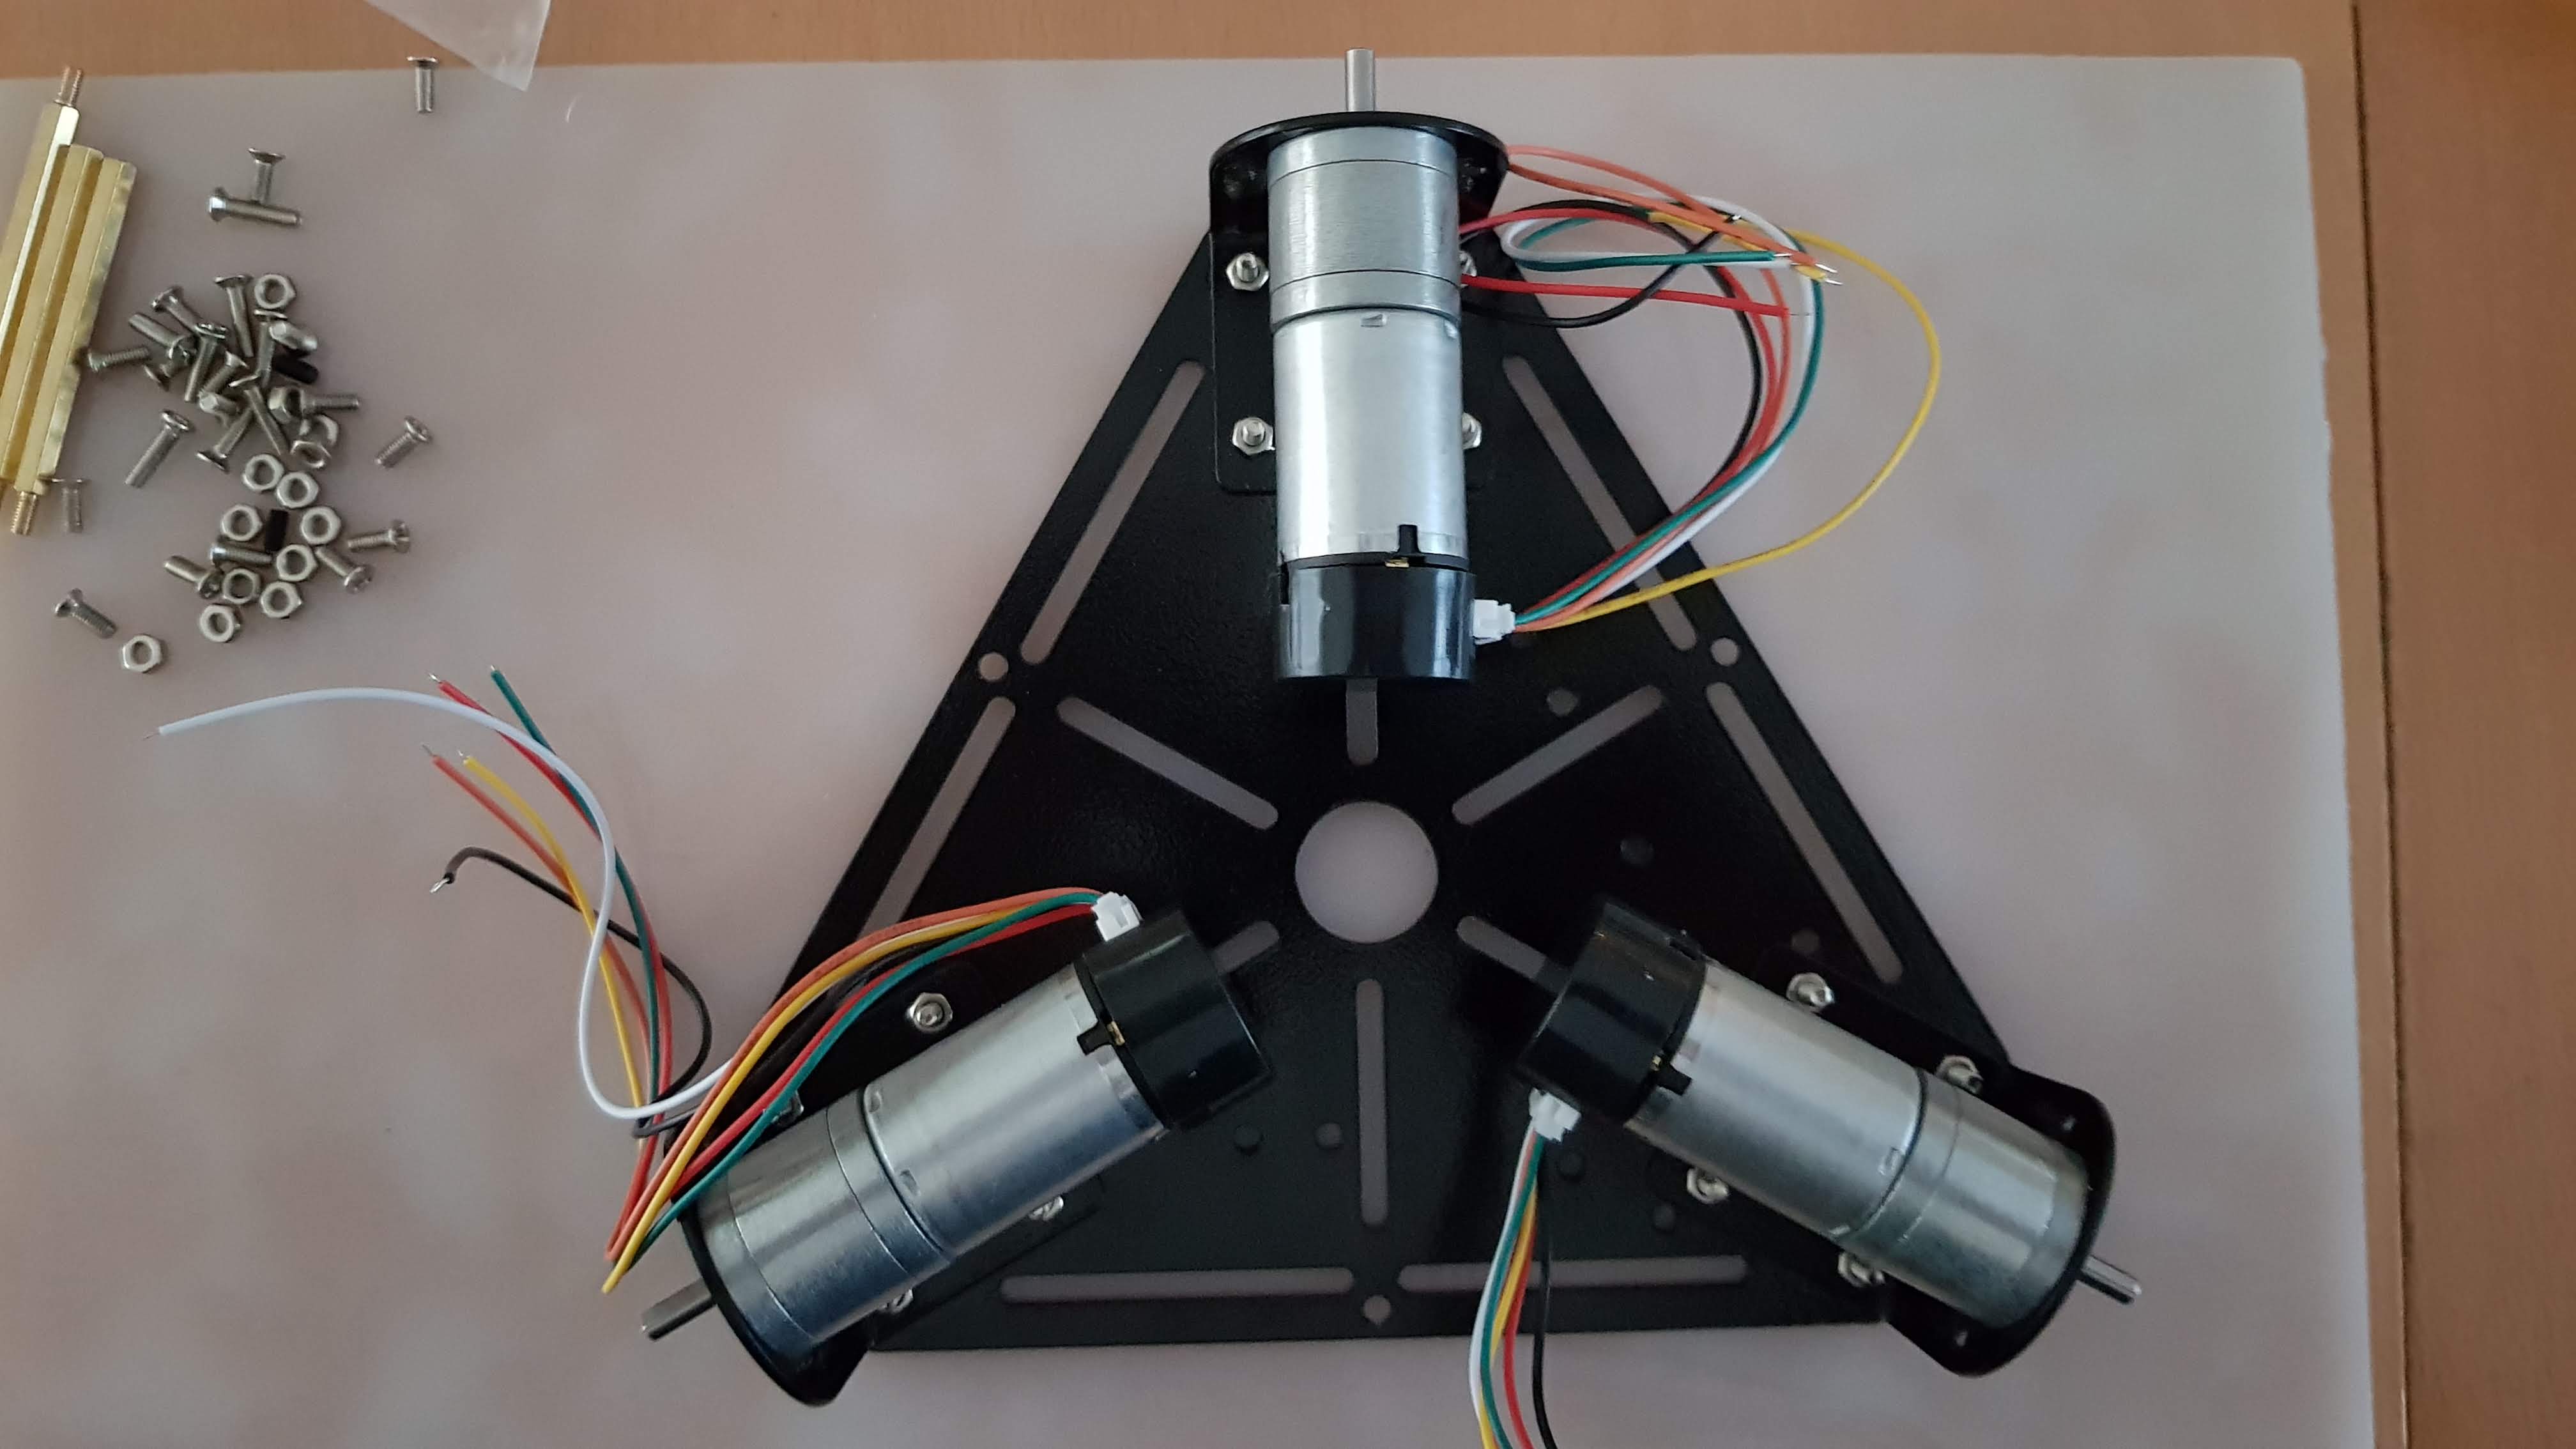
Gehäuse zusammenbauen
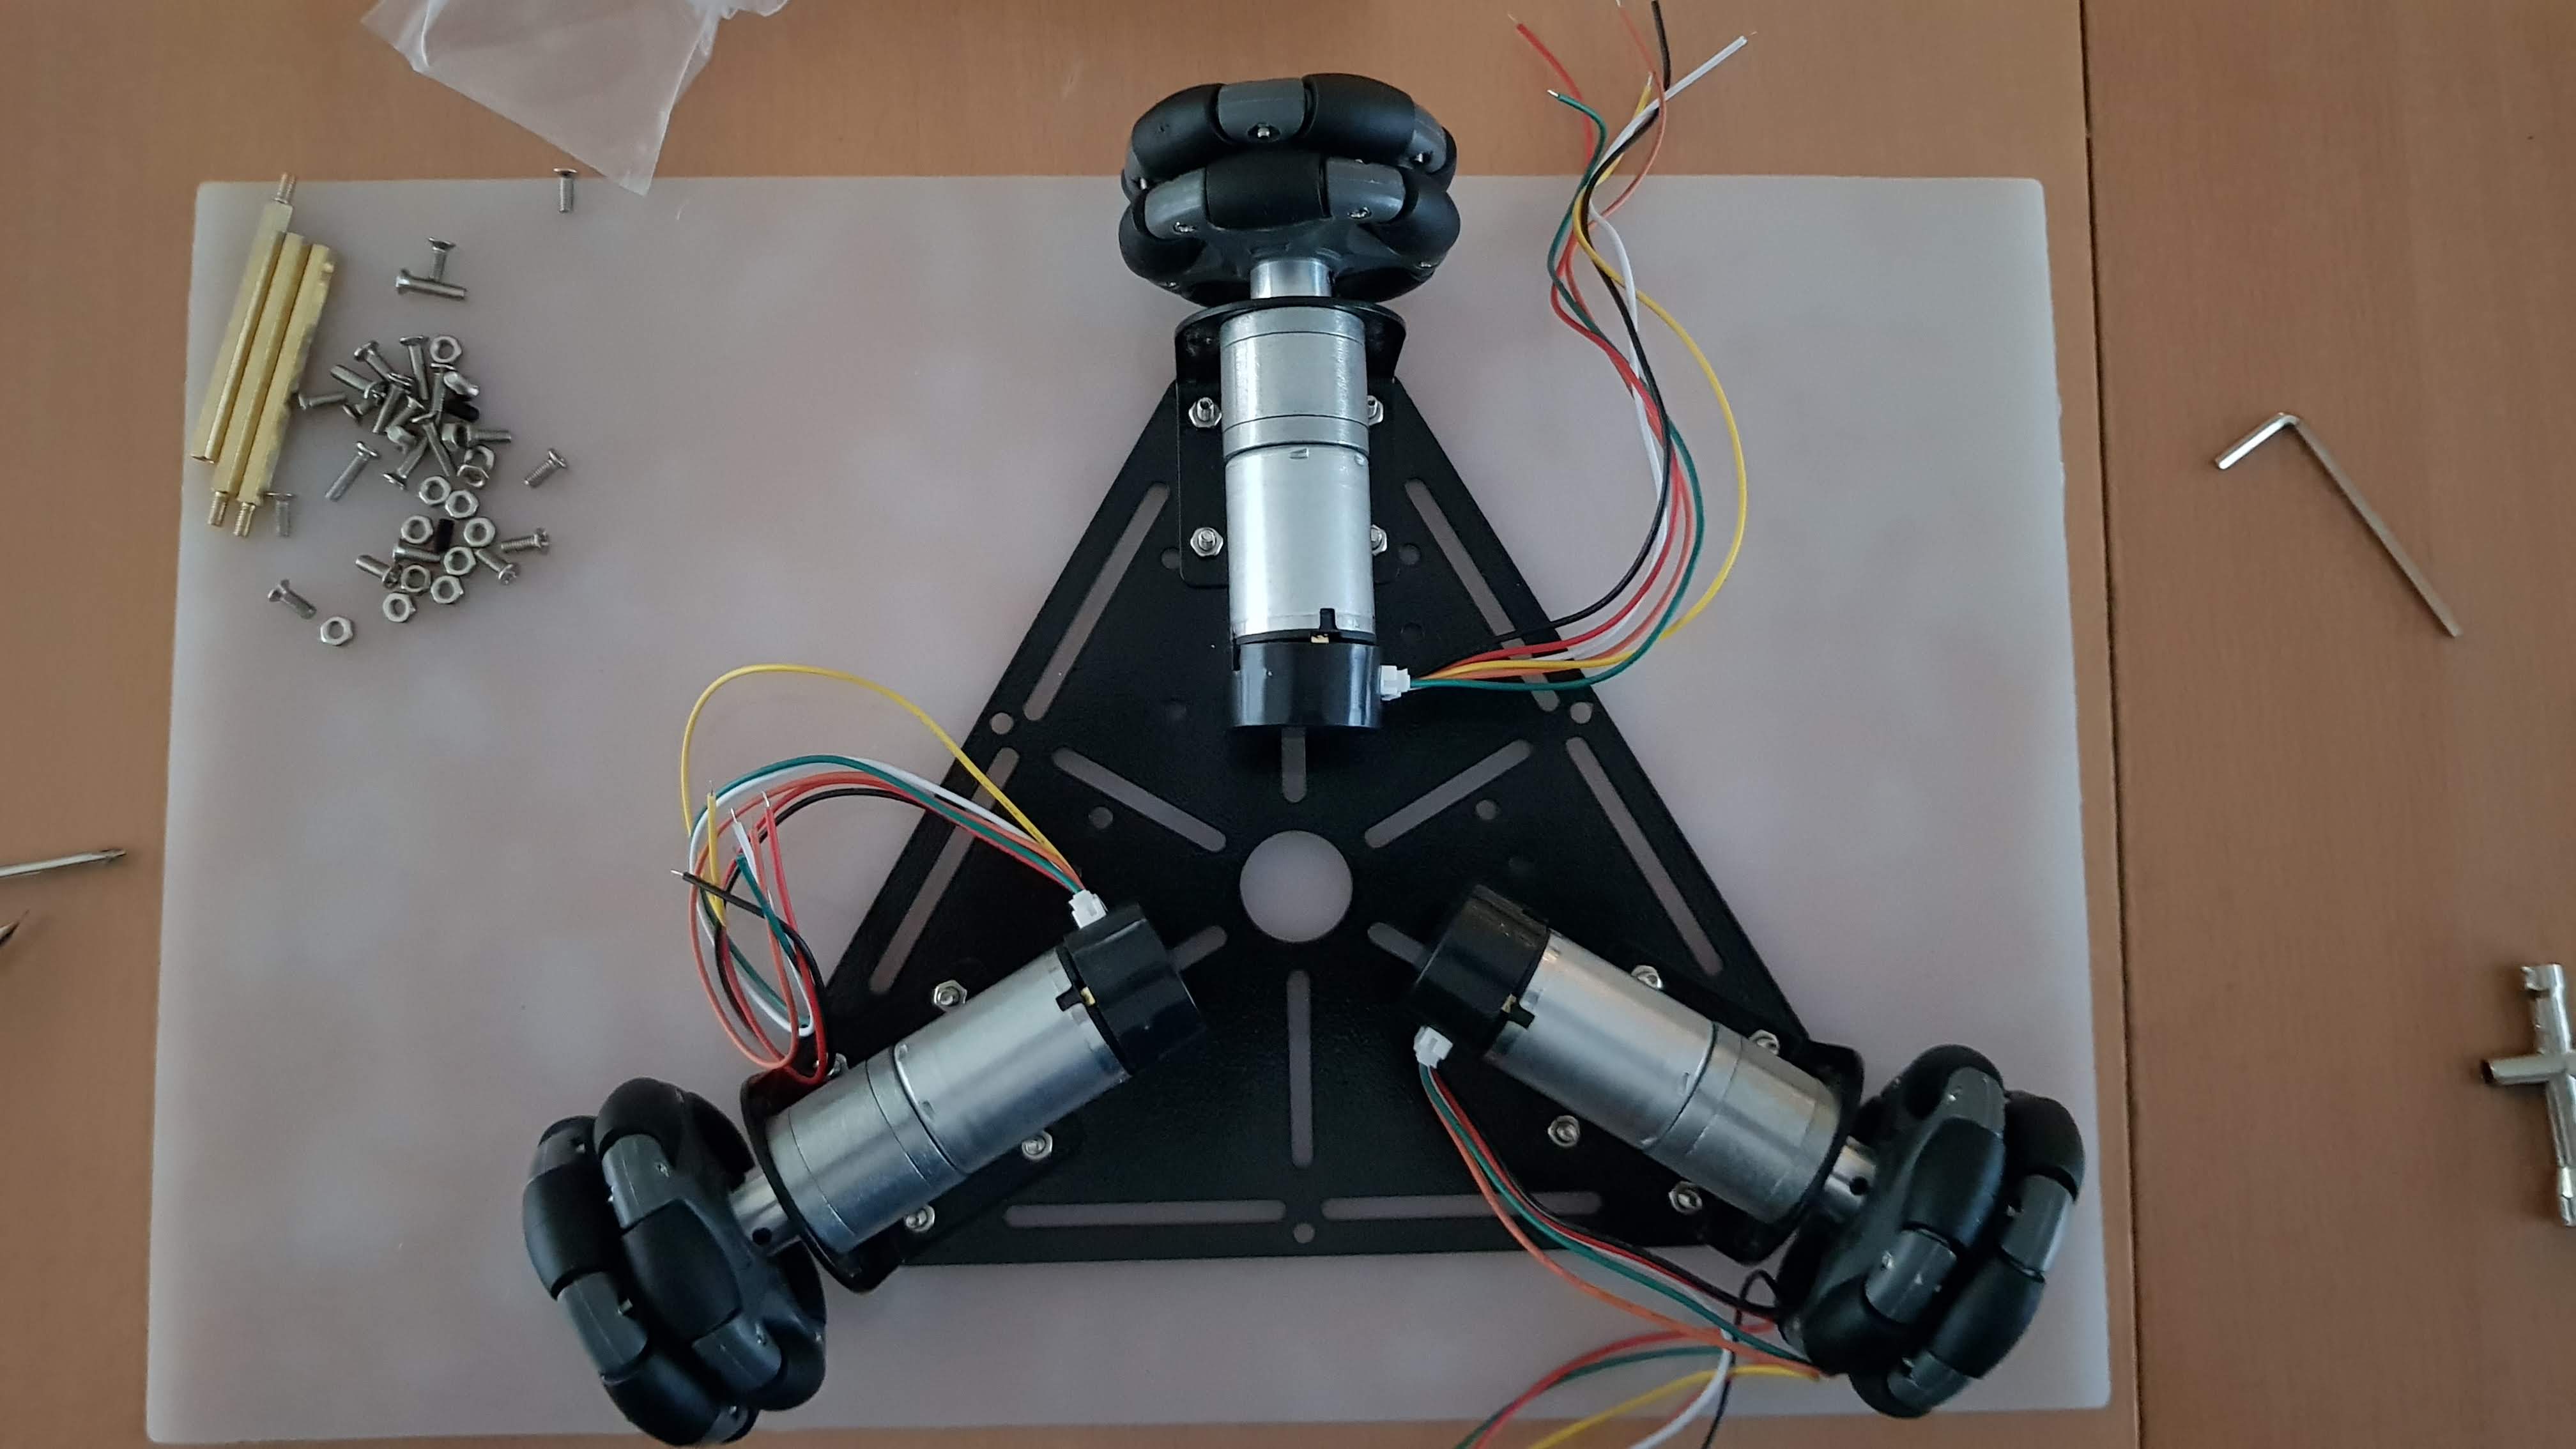
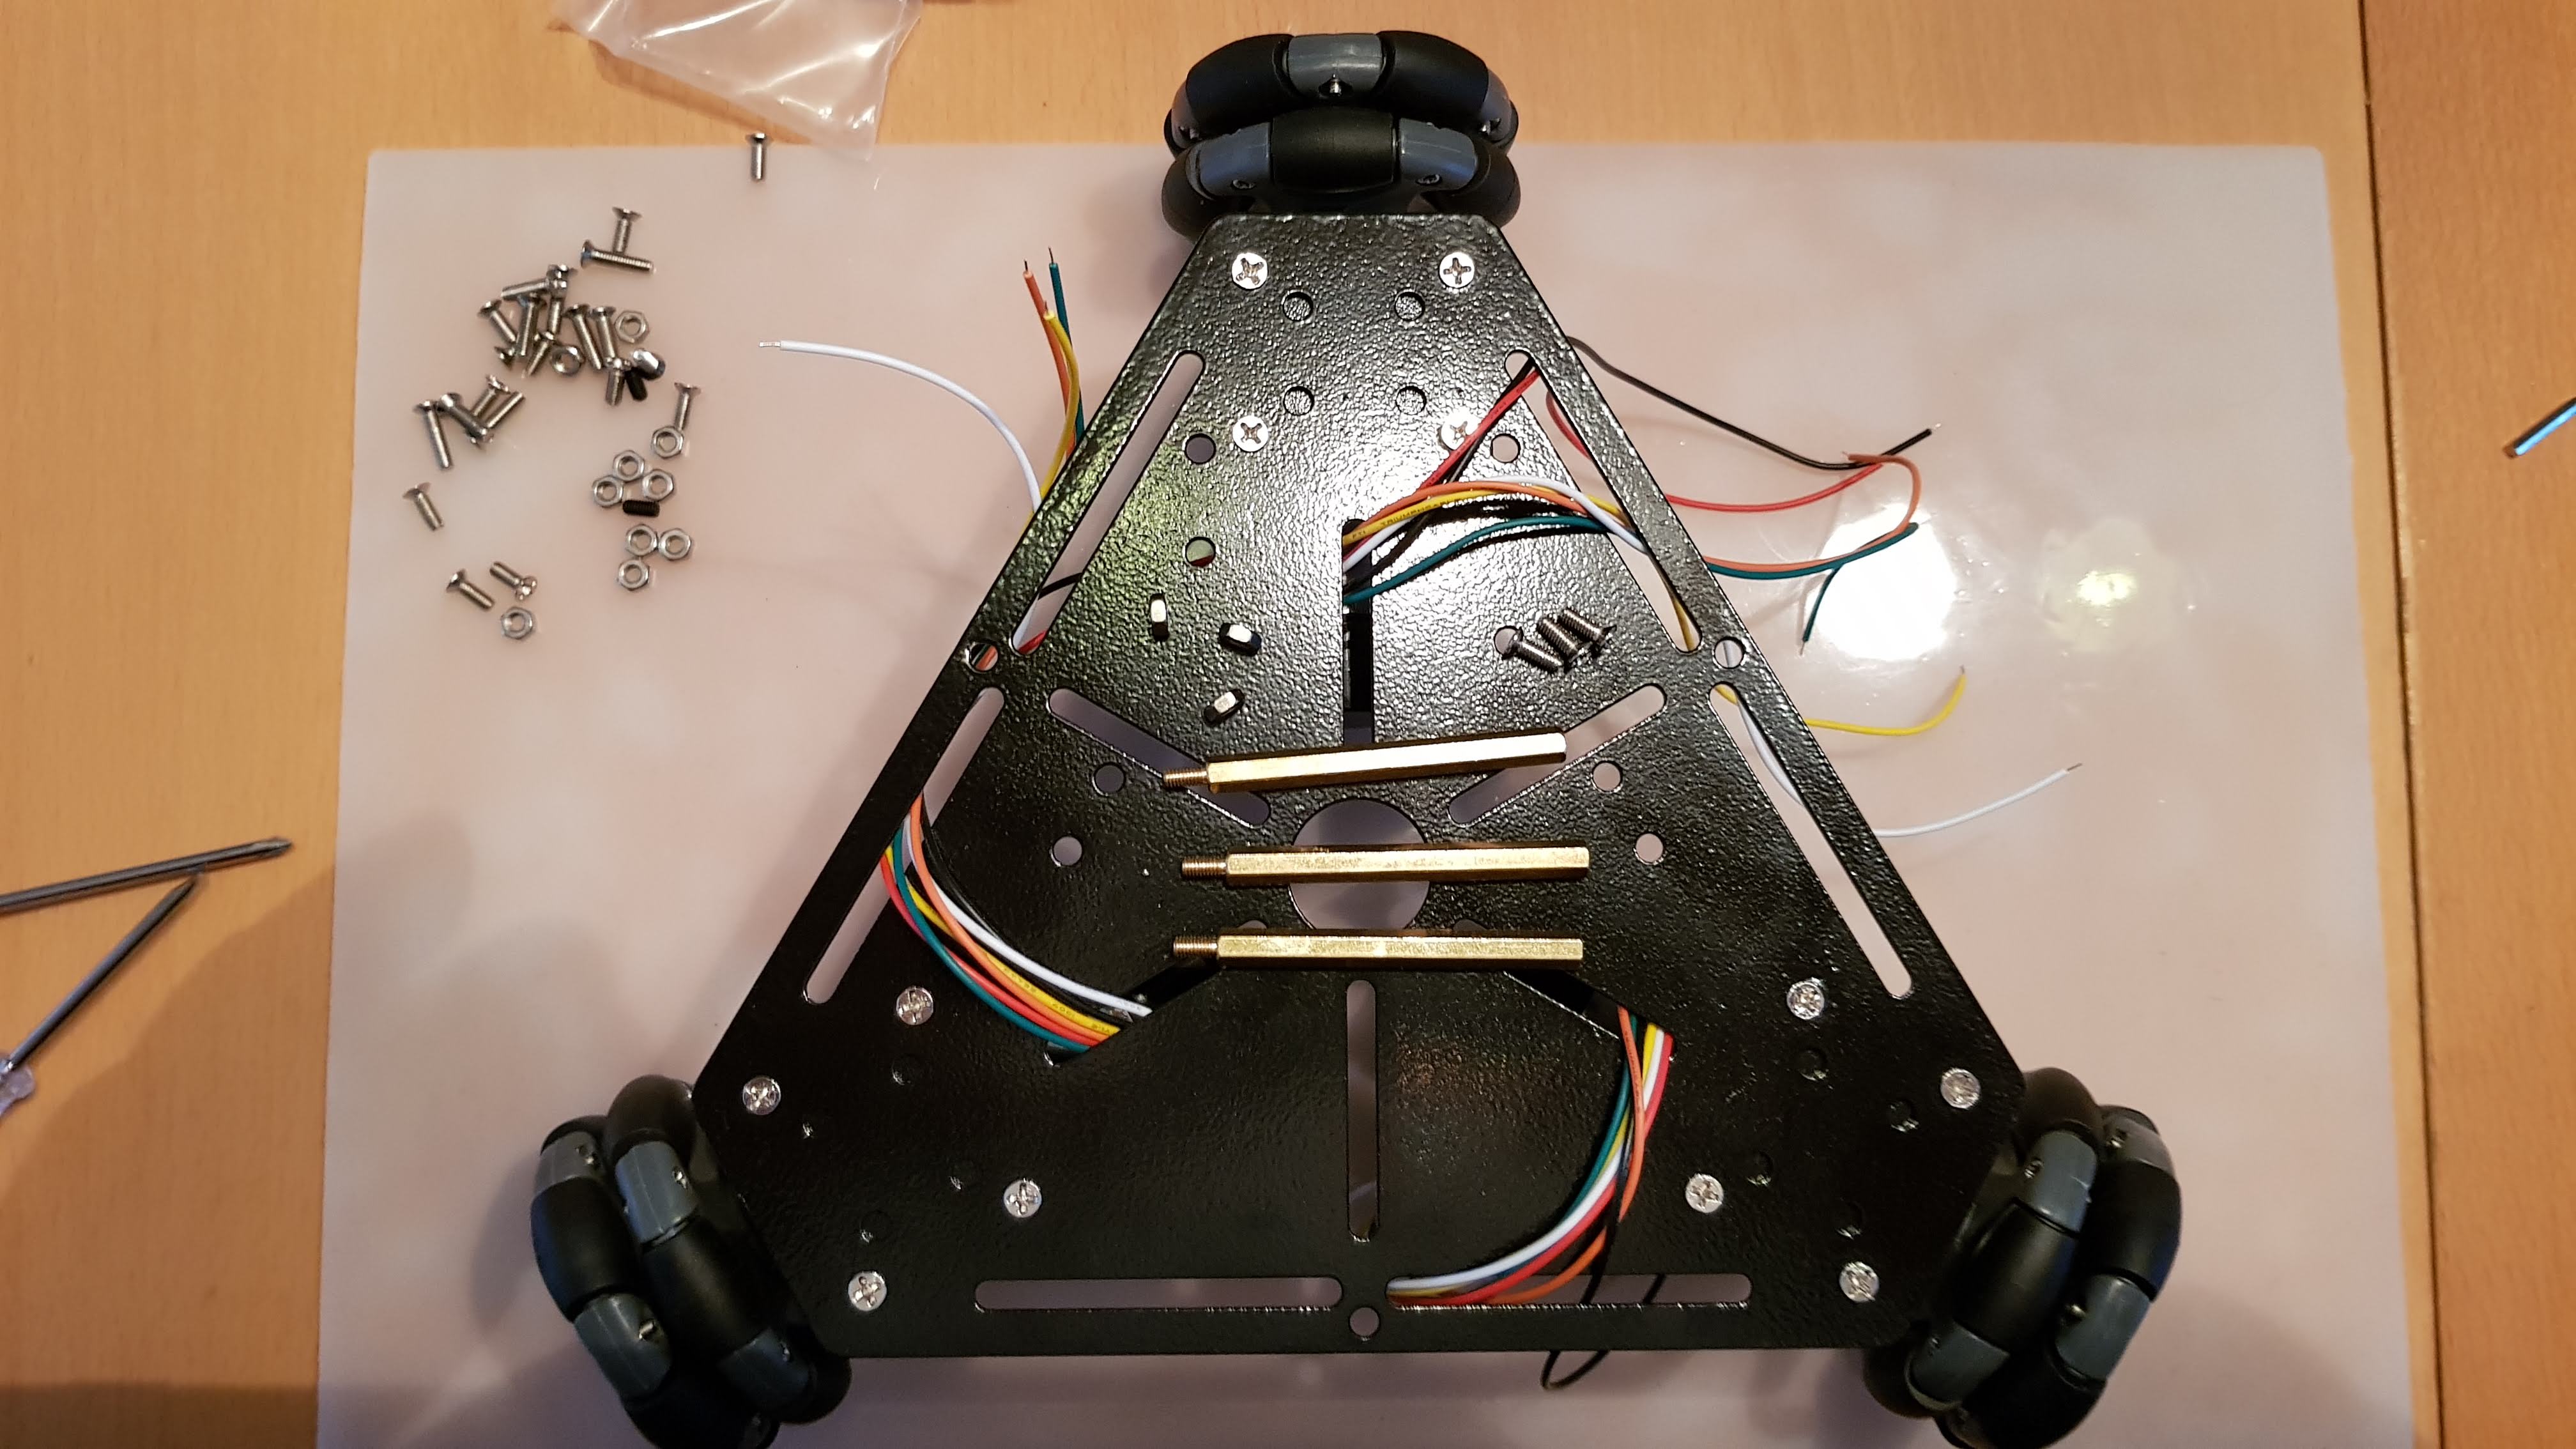
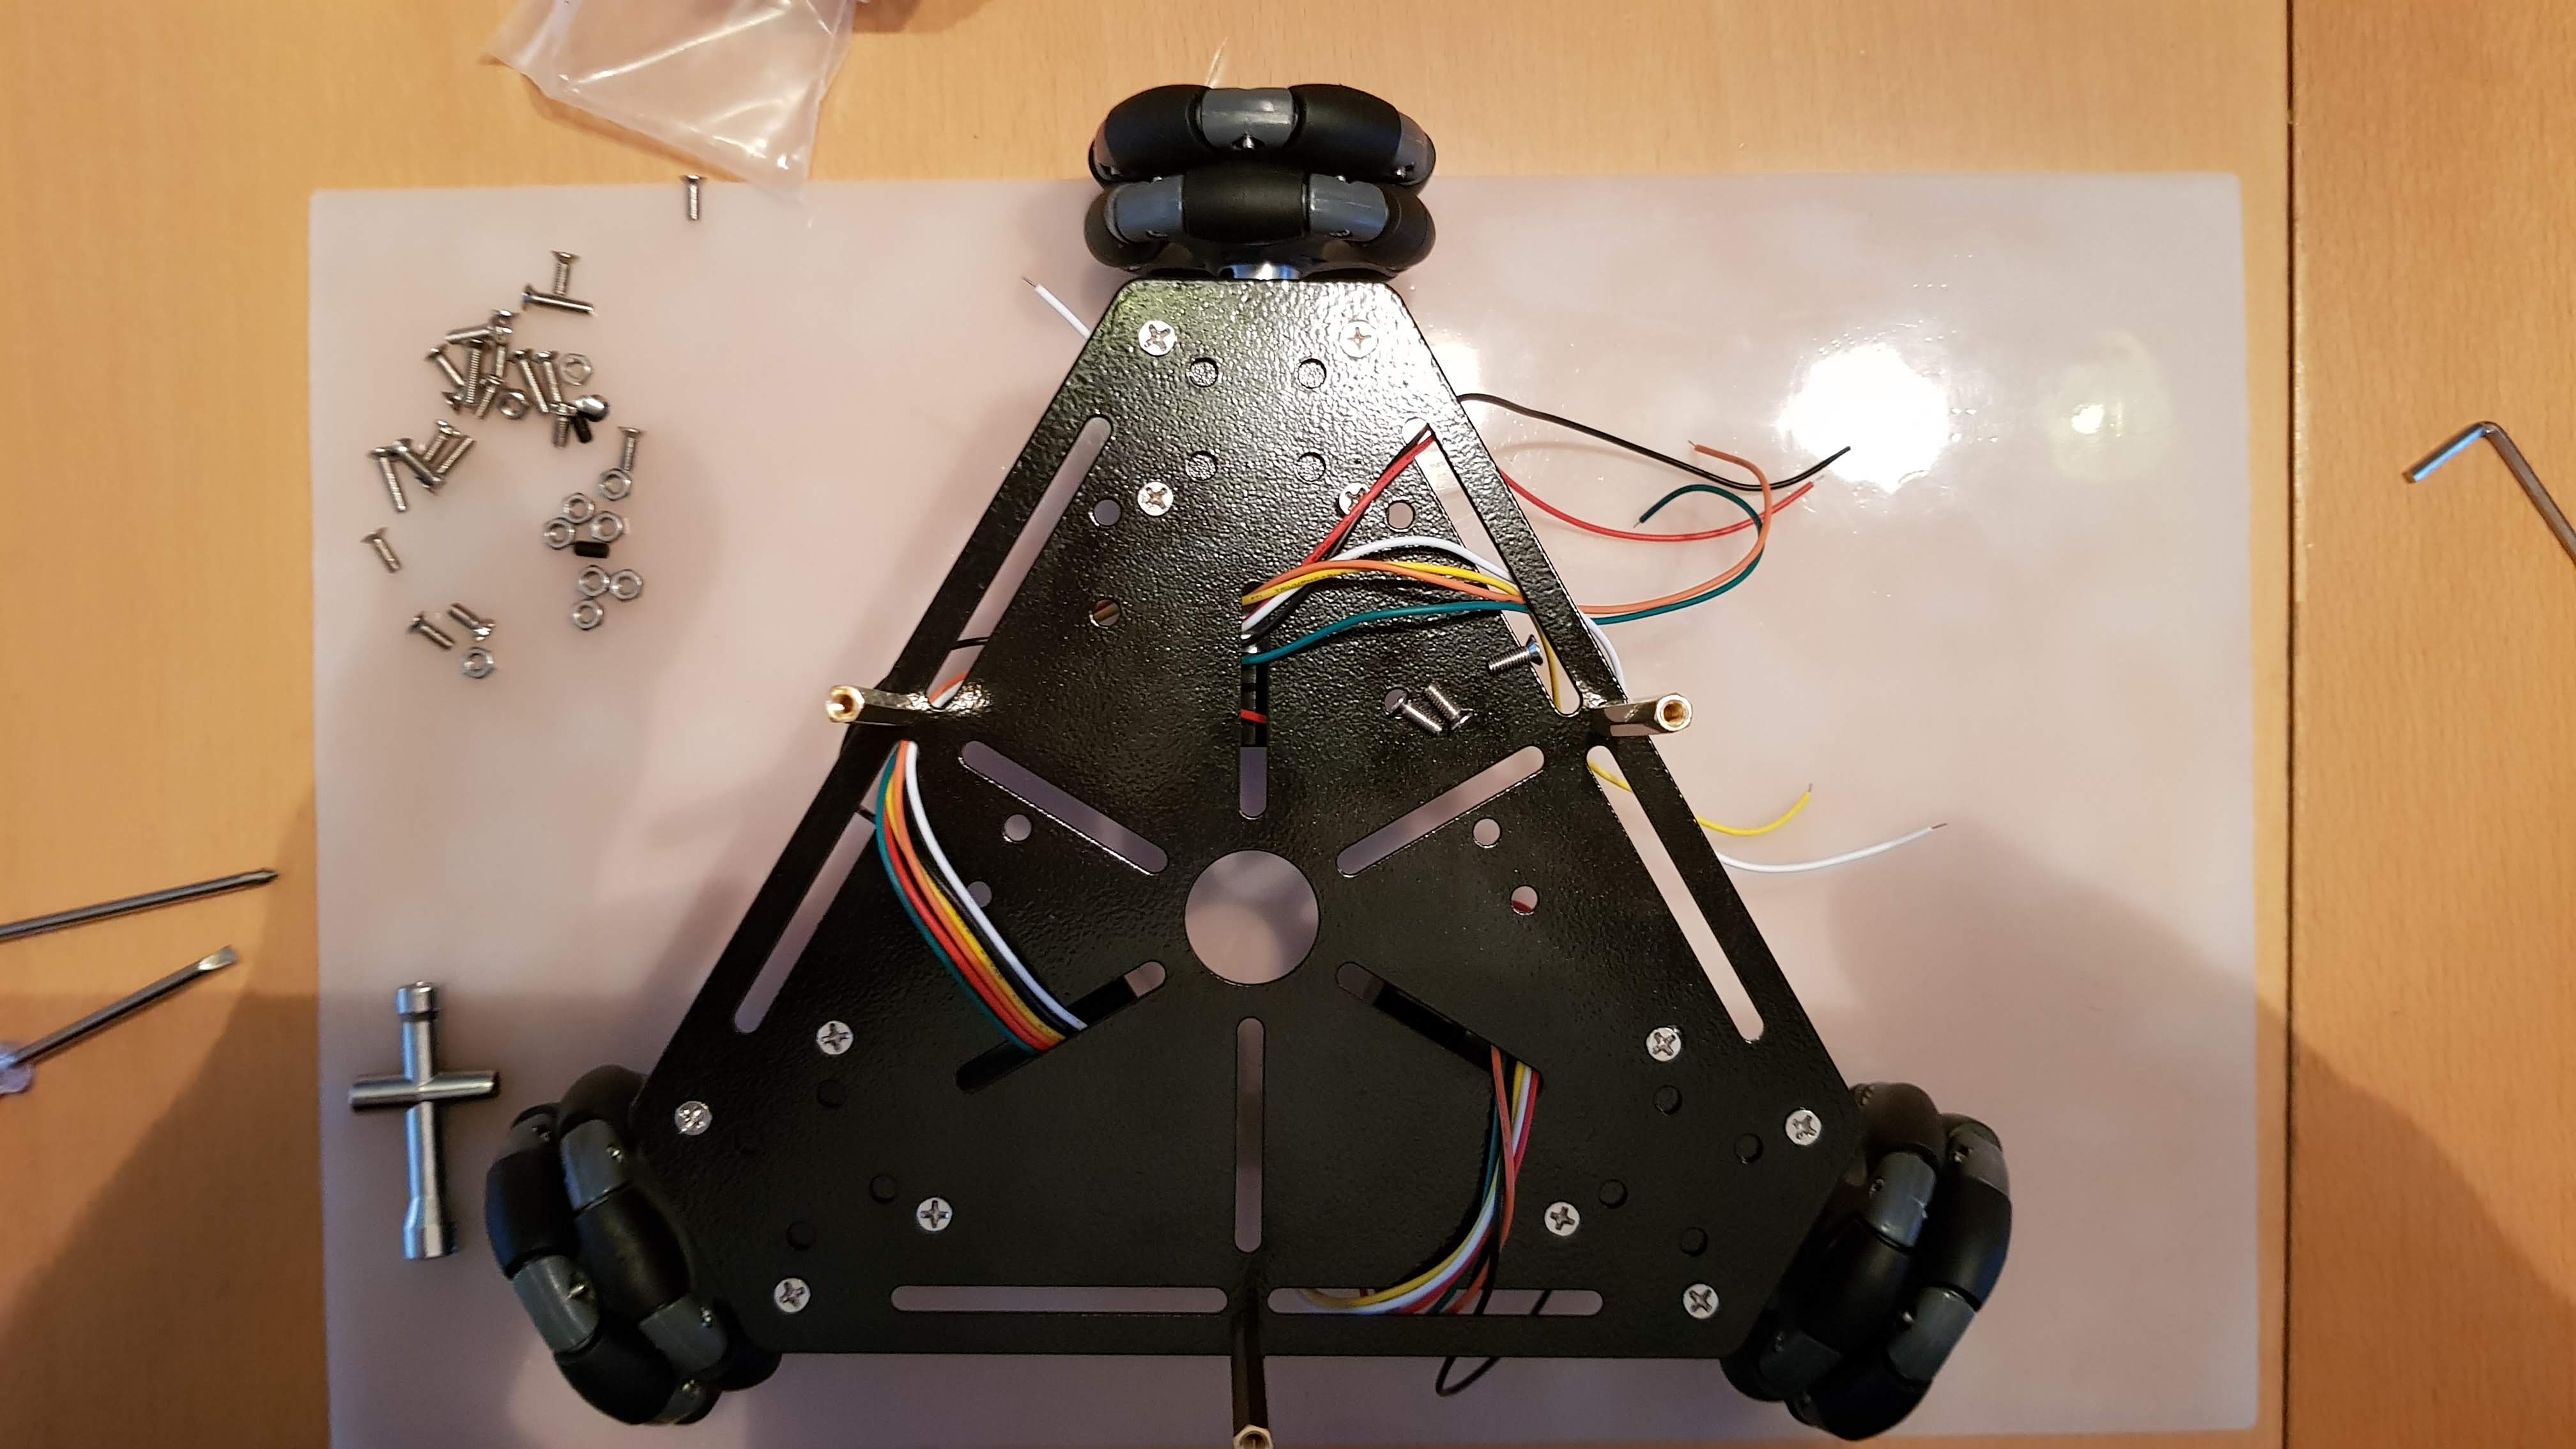
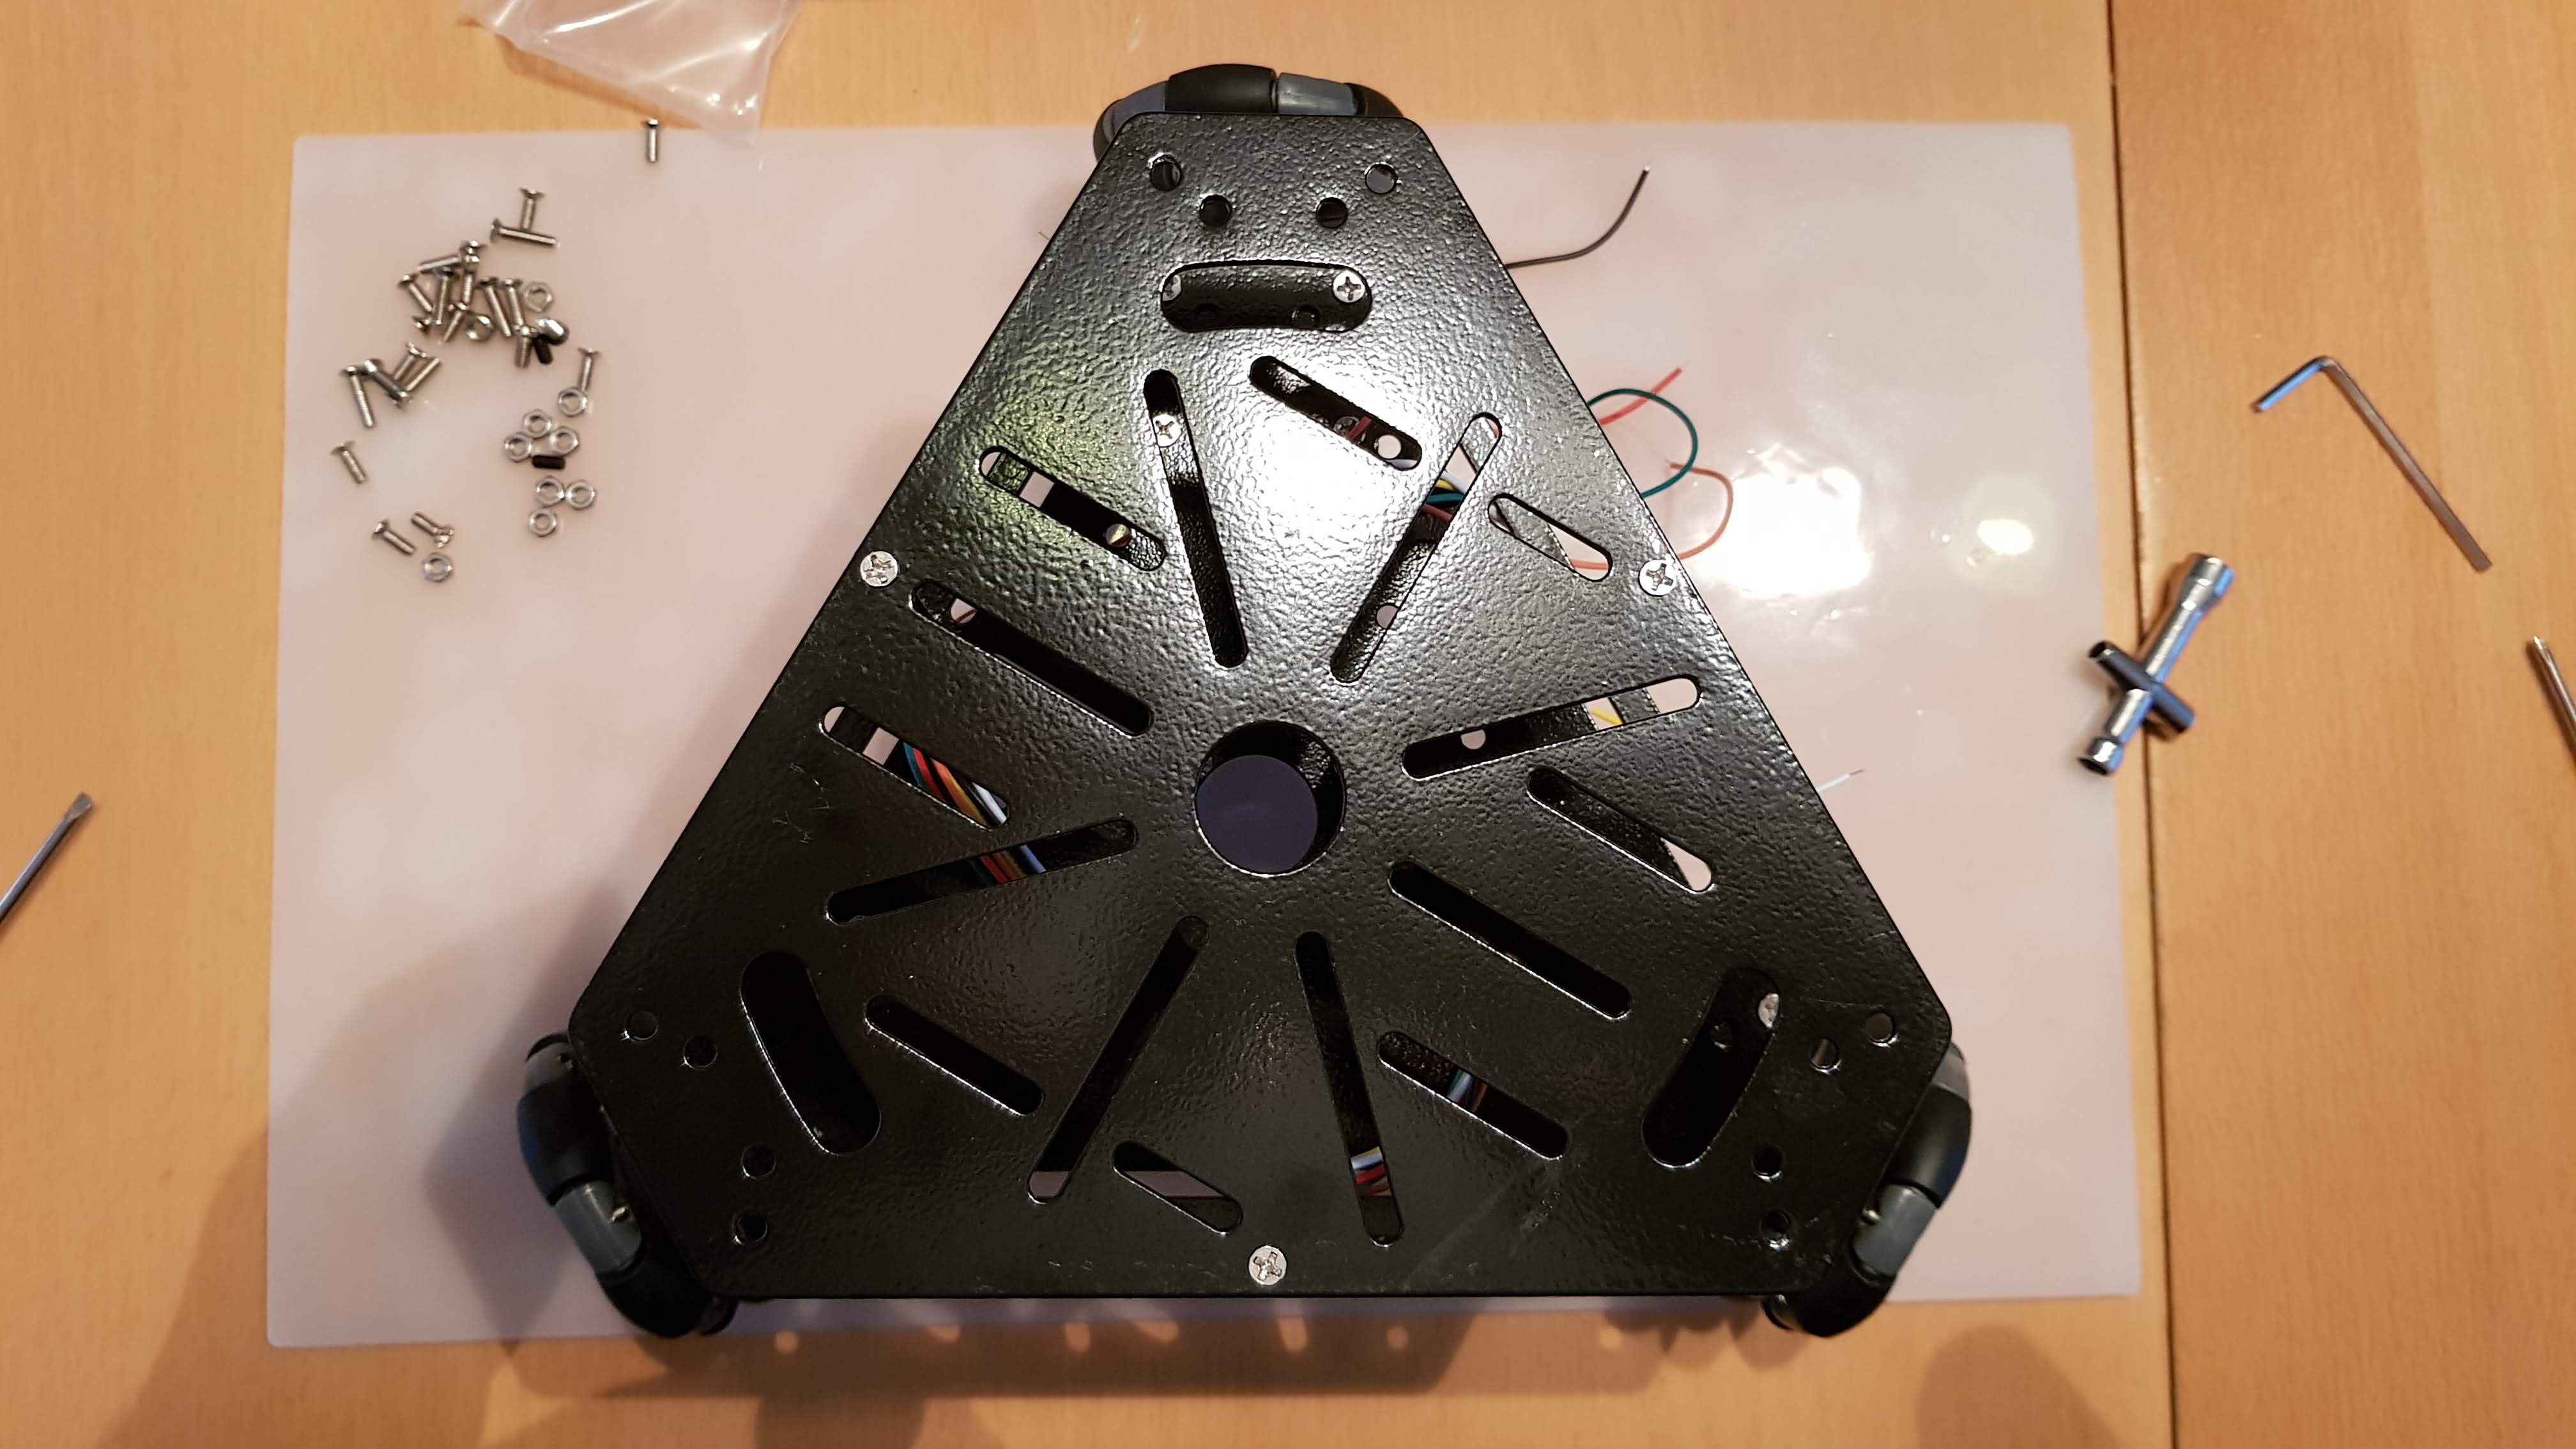
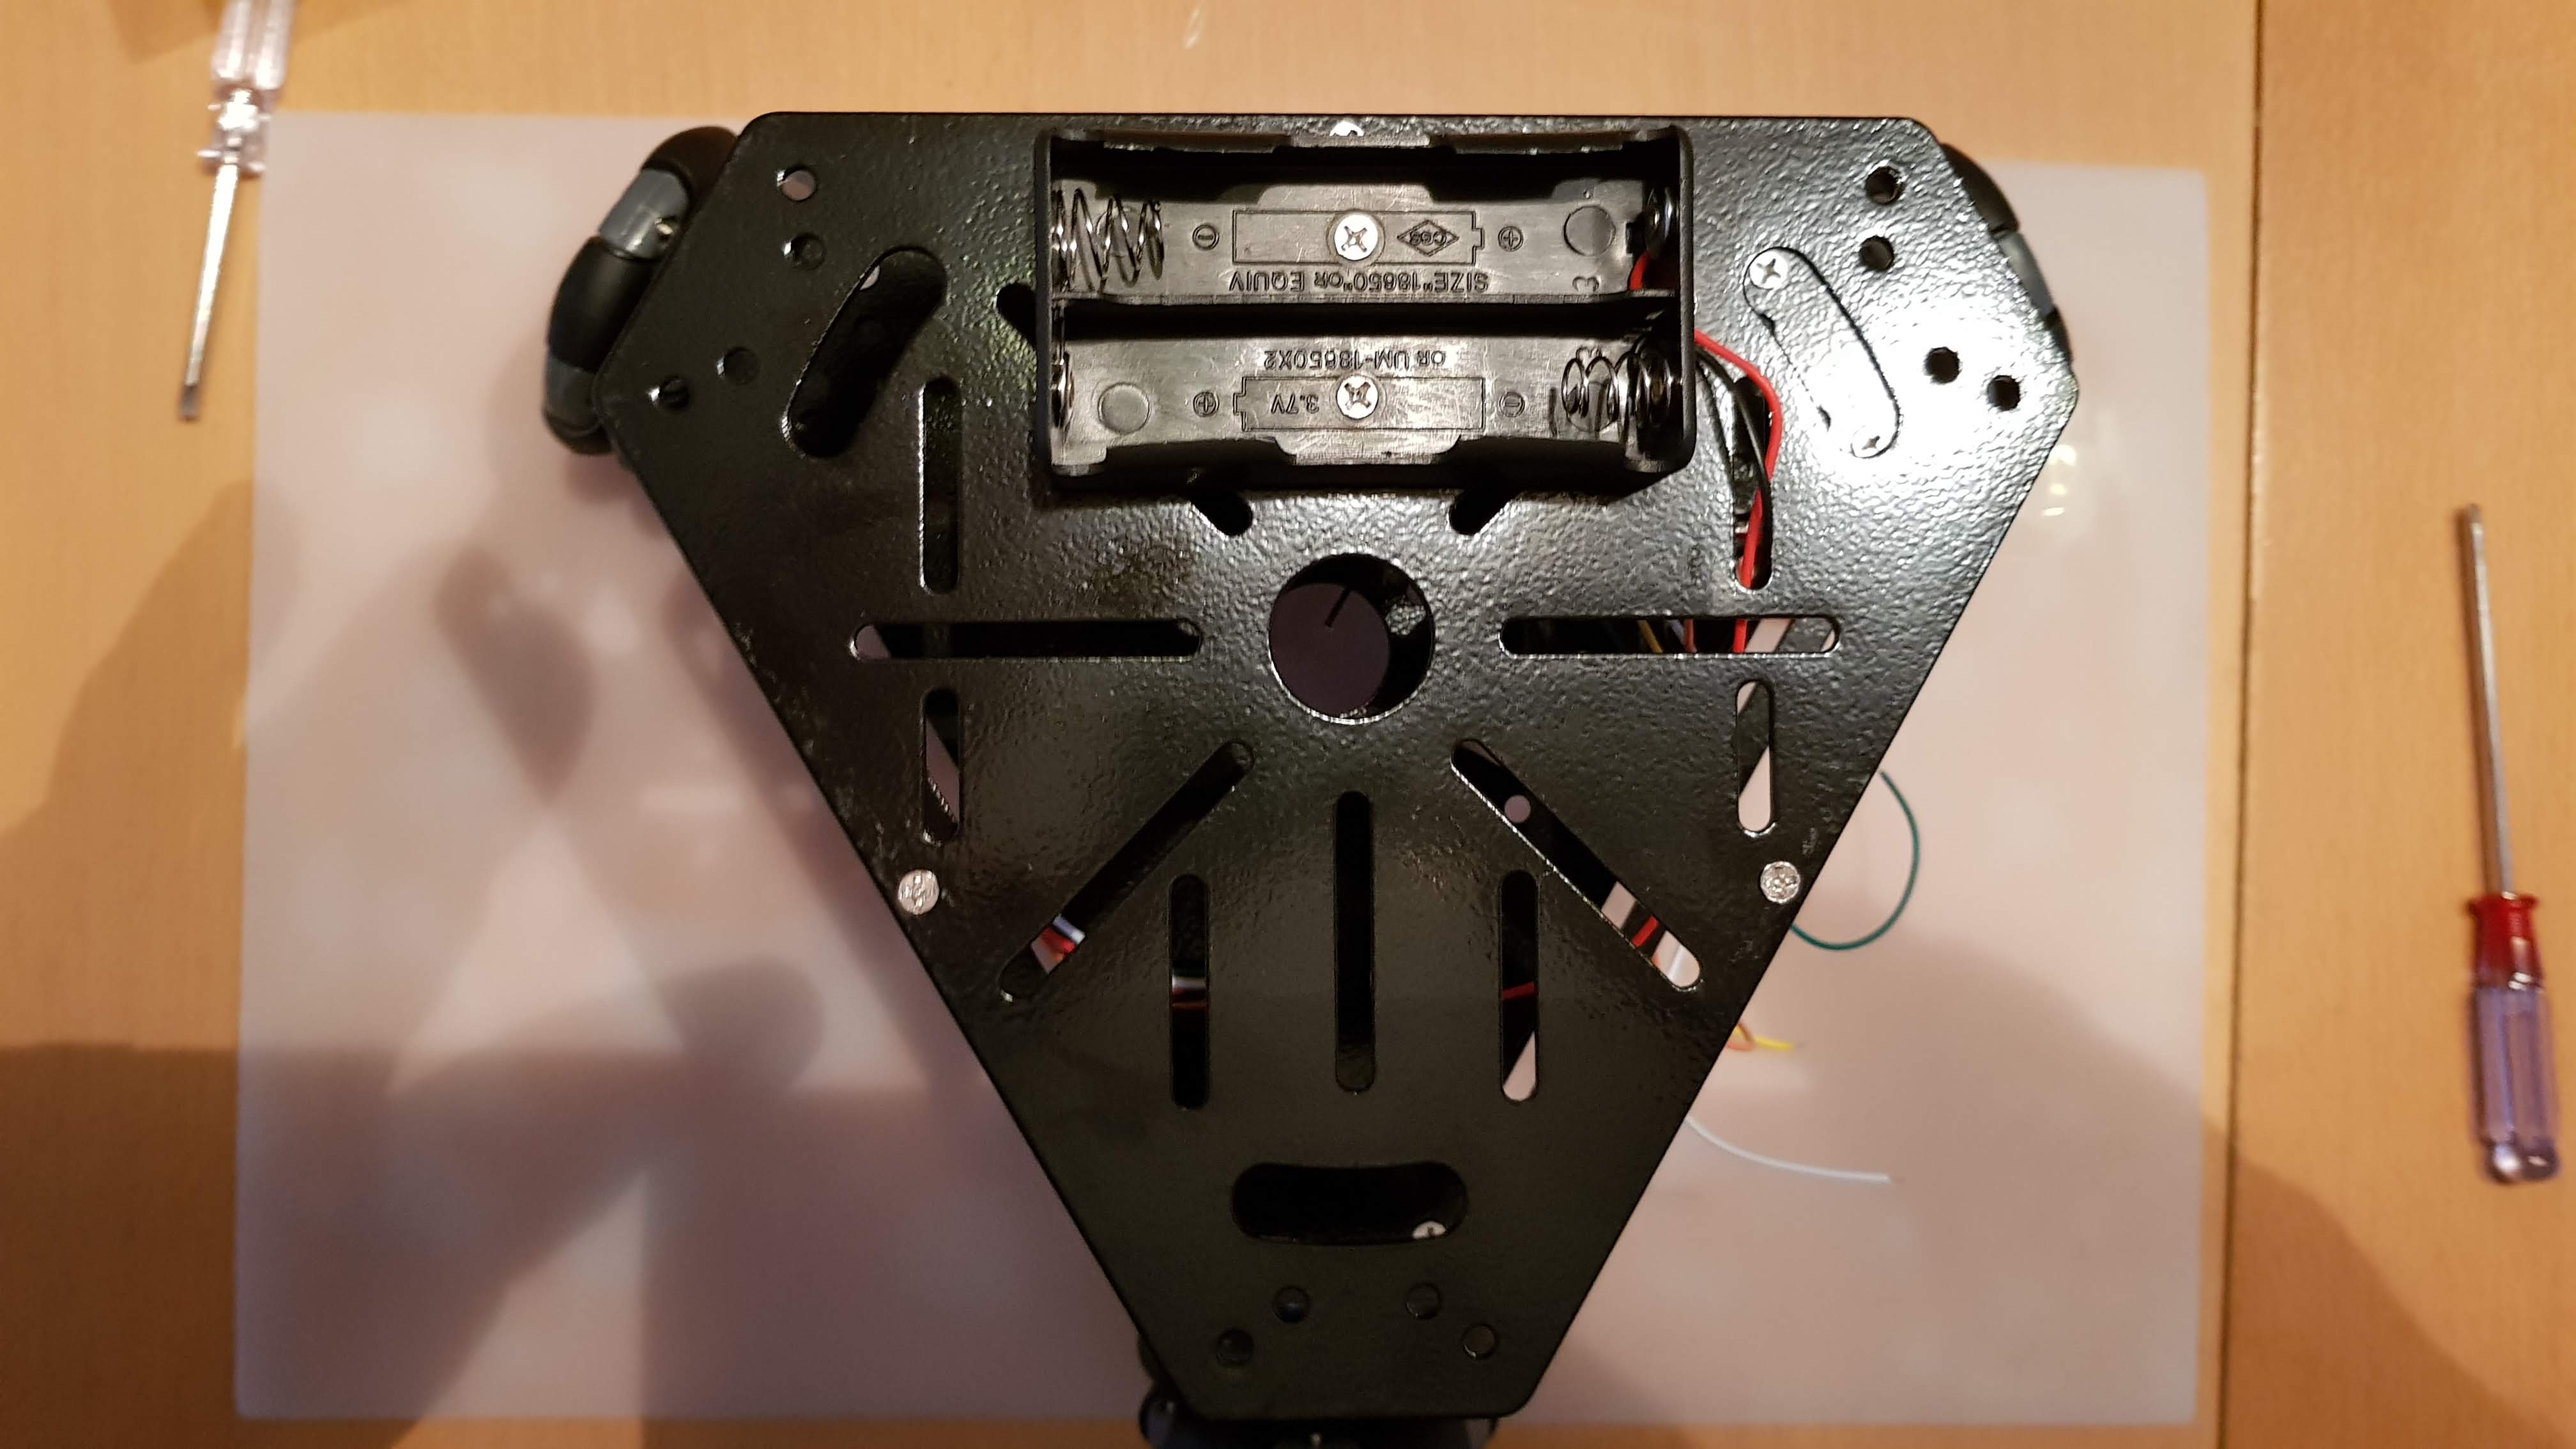
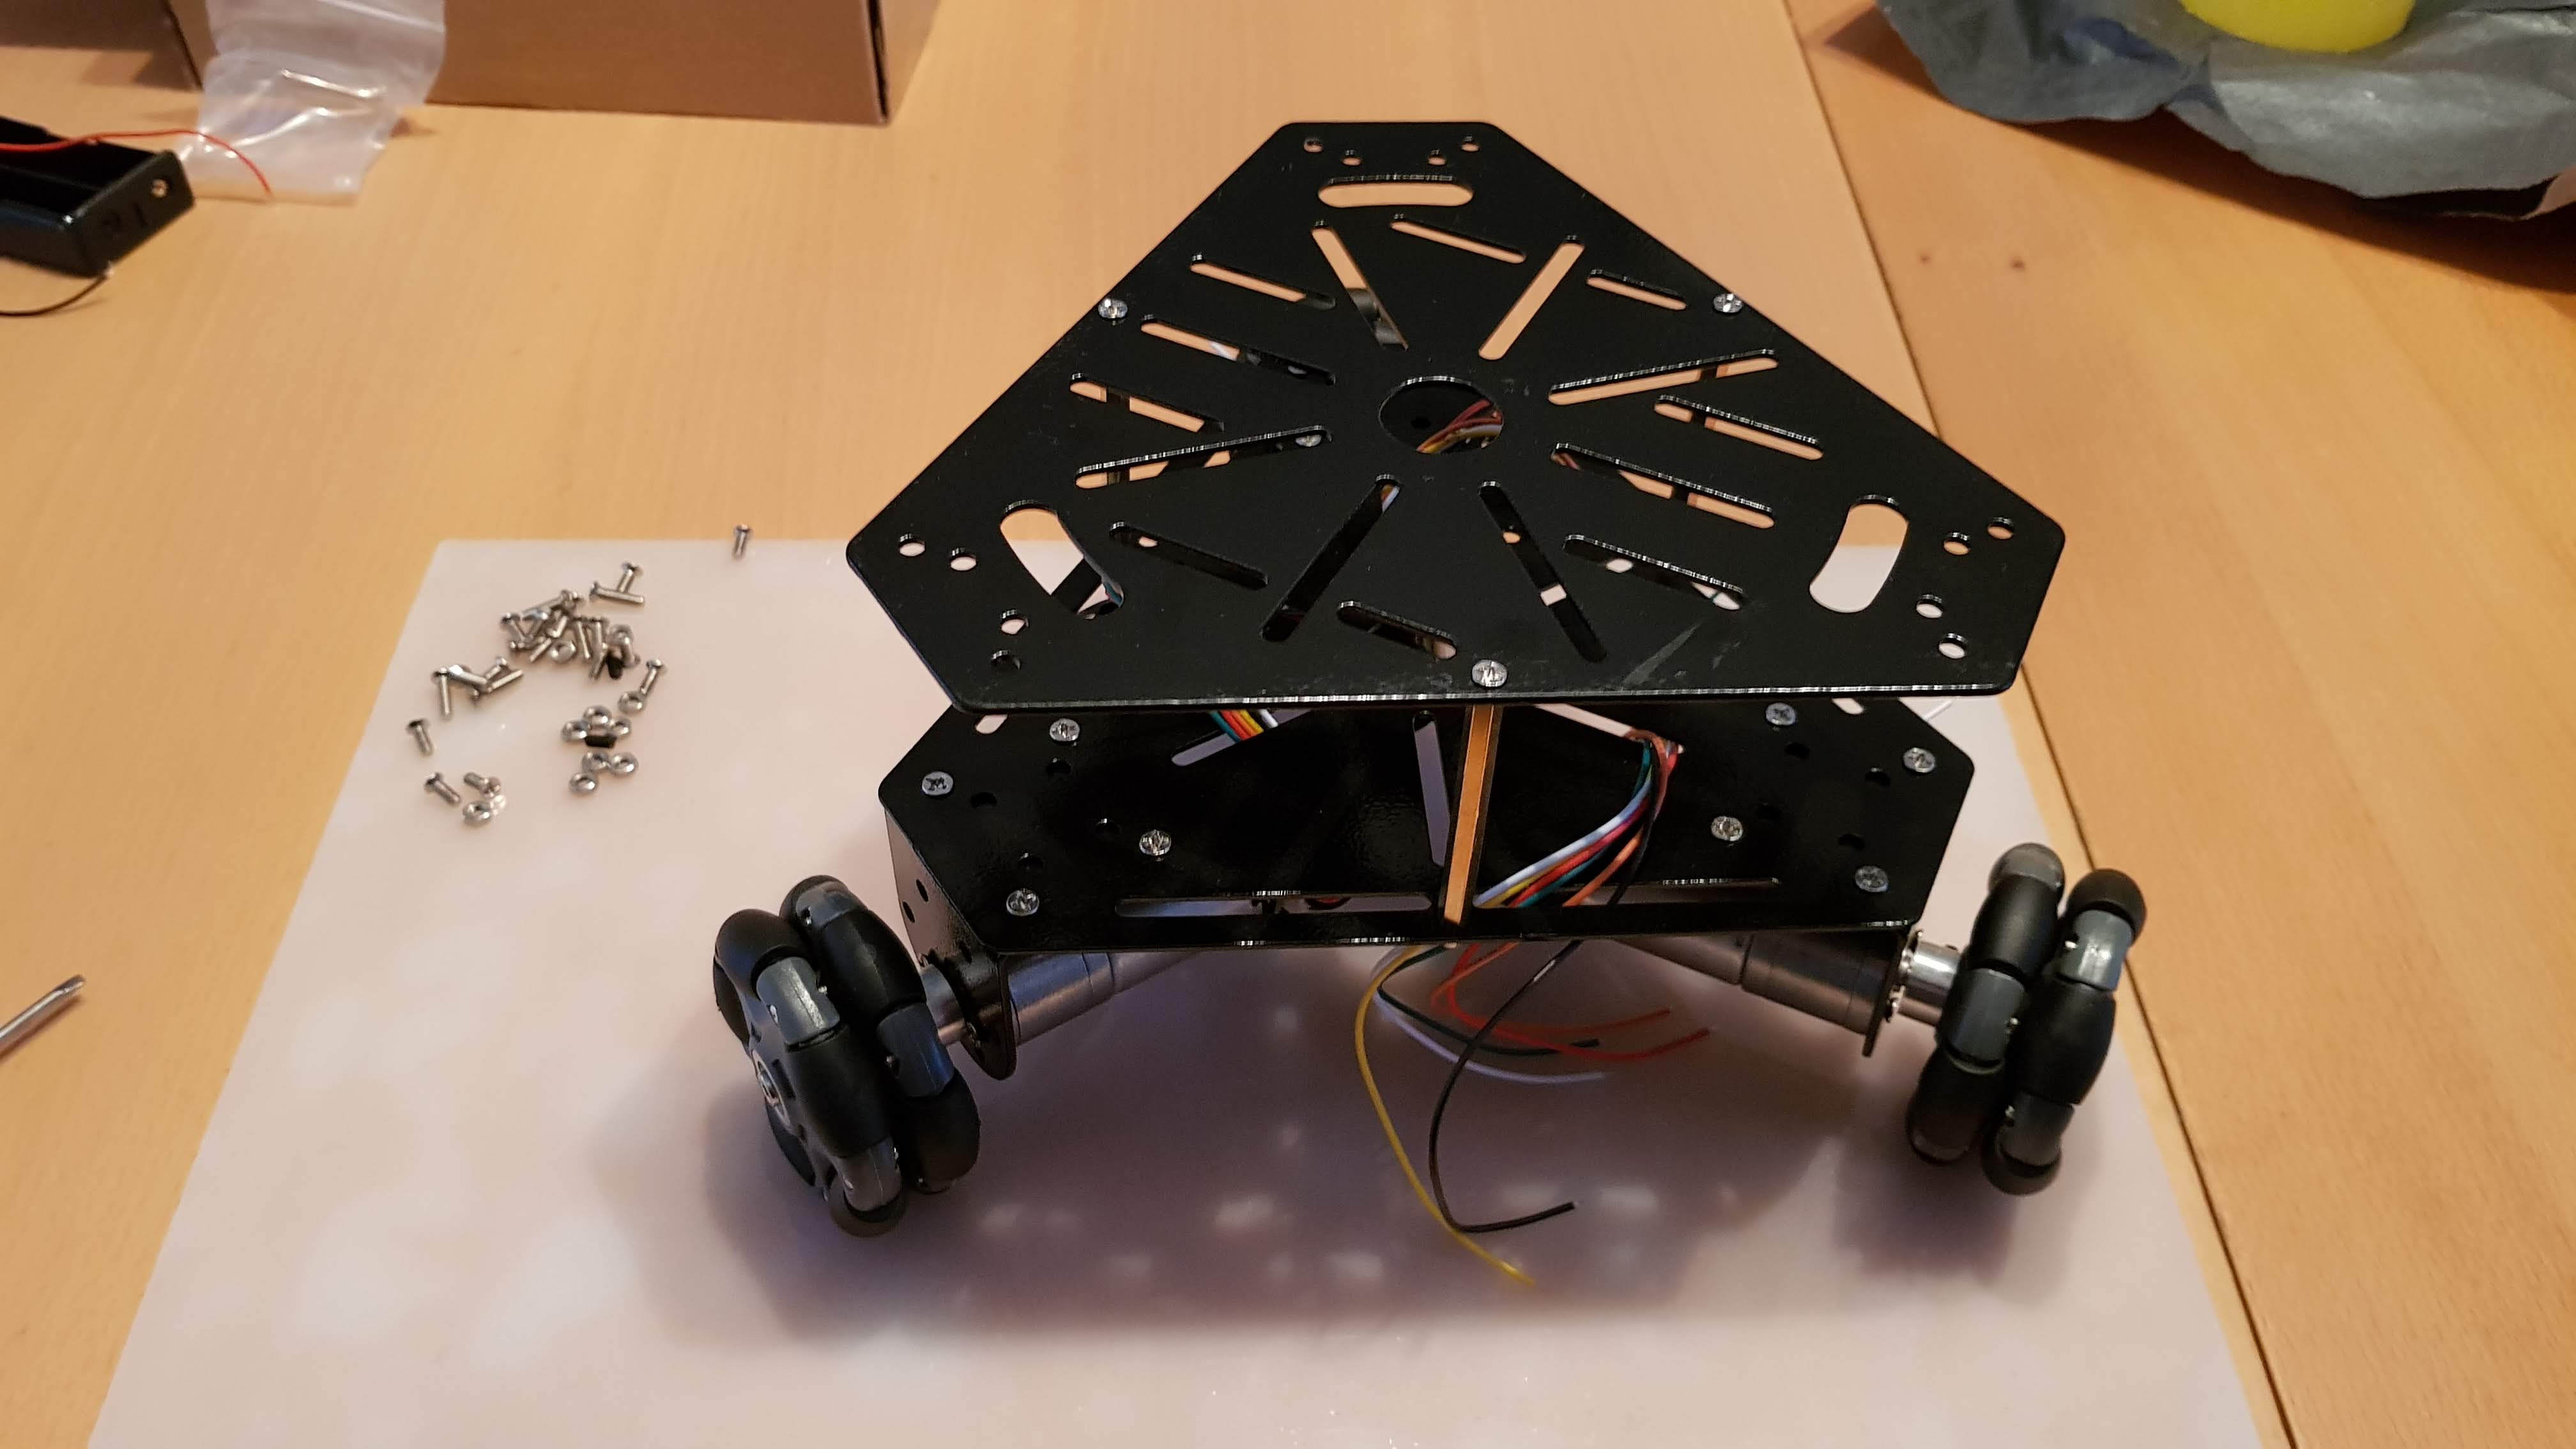
Conclusion
The kit is quick to assemble. All the shapes and holes fit perfectly. The speedy assembly is further accelerated by the included instructions and the available video on YouTube.
Was fehlt, ist eine Beschreibung und ein Belegungsplan für die Motoren. Es hat etwas Zeit gedauert, die richtige Belegung zu finden, da hier anscheinend kein Standard existiert.
The chassis and engines appear very stable, I'm already looking forward to putting it into operation.
Related Posts
- Zumo V1.2Link status: OK
Sources
https://en.wikipedia.org/wiki/Killough_platformLink status: OK
https://makezine.com/projects/make-40/kiwi/Link status: OK
https://github.com/WickedDevice/OmniWheelControl/Link status: OK
| Date | Change | Author |
|---|---|---|
| 03.10.2026 | Rechtschreibung korrigiert: Tippfehler, Kommas, Groß-/Kleinschreibung Log-Liste eingefügt | Suffocation |
| 18.06.2019 | Post created | Suffocation |