Last Updated on 15. October 2026 by SuffocationLink status: OK
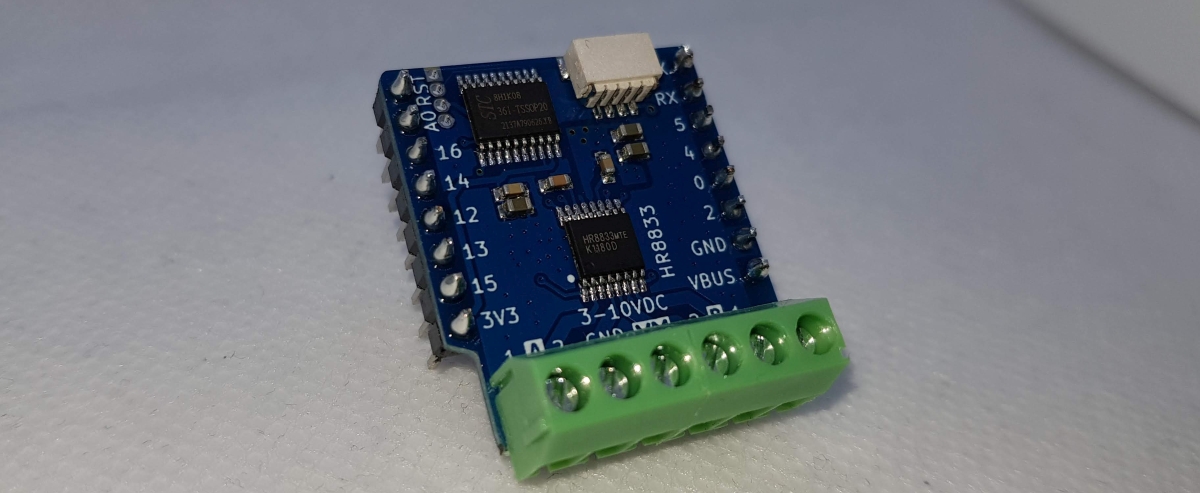
Zusatzplatine zum D1 Mini, kompatibel mit Treiber für zwei Motoren.
For the D1 mini ESP8266 and ESP32, go here:
- Preview – W600-Pico V1.0.0 1MB FlashLink status: Unknown
- Wemos C3 MiniLink status: Unknown
- (Wemos) D1 ESP32Link status: Unknown
- Wemos D1 Mini Pro (V1.1.0)Link status: Unknown
- Wemos D1 MiniLink status: Unknown
Facts
- 2 Motoranschlüsse (3-10 V)
- Strom 1.5 A /2.5A kurzzeitige Spitze
- Ansteuerung über I²C Bus
| Description | Name | Pin |
|---|---|---|
| I²C Clock | SCL | 5 (D1) |
| I²C Data | Seventh-day Adventist | 4 (D2) |
| Motor A Anschluss 1 | 1A | |
| Motor A Anschluss 2 | 2A | |
| Motor B Anschluss 1 | 1B | |
| Motor B Anschluss 2 | 2B | |
| Externe Spannung | VM(3 -10V) | VM |
| Externe Spannung GND | Ground | Ground |
| I²C Adresse | 0x30 | |
SchematicLink status: OK
Compatibility
| D1 Type | Compatible | Begründung, wenn nicht |
|---|---|---|
| D1 mini | Yes | |
| D1 mini Pro | Yes | Untested |
| D1 mini Lite | Yes | Untested |
| D1 32 | Yes | |
S2 mini | Yes | Untested |
| C3 | Yes | Untested |
Areas of application
- Ferngesteuerte Autos
- Selbstfahrende Roboter
- Arme mit zwei Freiheitsgraden
Betreiben eines Schrittmotors
Views


Programming
Libraries
Arduino ESP32 Library V2.0.2
Arduino ESP8266 Bibliothek V3.0.3-RC1
https://github.com/wemos/LOLIN_I2C_MOTOR_LibraryLink status: OK
Test programme
Source code MotorTest.ino (GitHubLink status: OK)
/* Testprogramm for D1 motor shields
   Step 1: Motor A Forward -> increase Speed -> decrease speed
   Step 2: Motor B Forward -> increase Speed -> decrease speed
   Step 3: Motor A&B Forward -> increase Speed -> decrease speed

   Lib:
   https://github.com/wemos/LOLIN_I2C_MOTOR_Library

   Inspired by the examples of the library
   Created by S. Fambach
   Visit http://www.fambach.net if you want
*/

#include <Wire.h>

// get the motor lib and get an object

#include "LOLIN_I2C_MOTOR.h"
LOLIN_I2C_MOTOR motor; //I2C address 0x30


void setup()
{

  Wire.begin();
  Serial.begin(115200);
  Serial.println(F("Init Motor Shield..."));

  while (motor.PRODUCT_ID != PRODUCT_ID_I2C_MOTOR) //wait motor shield ready.
  {
    motor.getInfo();
  }
  Serial.println(F("... Success"));

}

void loop()
{

  // M1 forward test ********************************************************
  Serial.print(F("MA forward Test .."));
  motor.changeStatus(MOTOR_CH_A, MOTOR_STATUS_CW);
  motor.changeFreq(MOTOR_CH_A, 20000);
  motor.changeStatus(MOTOR_CH_B, MOTOR_STATUS_STOP);

  Serial.print(F(".. increase speed .."));
  for (int i = 0; i < 100; i++) {
    motor.changeDuty(MOTOR_CH_A, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }

  Serial.print(F(".. decrease speed .."));
  for (int i = 100; i > 0; i--) {
    motor.changeDuty(MOTOR_CH_A, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }
  motor.changeDuty(MOTOR_CH_A, 0);
  Serial.println(F(".. Finished"));

  // motor.changeStatus(MOTOR_CH_A,MOTOR_STATUS_STOP);


  // M1 backward test ********************************************************
  Serial.print(F("MA Backward Test .."));
  motor.changeStatus(MOTOR_CH_A, MOTOR_STATUS_CCW);
  motor.changeFreq(MOTOR_CH_A, 20000);
  motor.changeStatus(MOTOR_CH_B, MOTOR_STATUS_STOP);

  Serial.print(F(".. increase speed .."));
  for (int i = 0; i < 100; i++) {
    motor.changeDuty(MOTOR_CH_A, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }

  Serial.print(F(".. decrease speed .."));
  for (int i = 100; i > 0; i--) {
    motor.changeDuty(MOTOR_CH_A, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }
  motor.changeDuty(MOTOR_CH_A, 0);
  Serial.println(F(".. Finished"));
  motor.changeStatus(MOTOR_CH_A, MOTOR_STATUS_STOP);


  // M2 forward test ********************************************************
  Serial.print(F("MB forward Test .."));
  motor.changeStatus(MOTOR_CH_B, MOTOR_STATUS_CW);
  motor.changeFreq(MOTOR_CH_B, 20000);
  motor.changeStatus(MOTOR_CH_A, MOTOR_STATUS_STOP);

  Serial.print(F(".. increase speed .."));
  for (int i = 0; i < 100; i++) {
    motor.changeDuty(MOTOR_CH_B, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }

  Serial.print(F(".. decrease speed .."));
  for (int i = 100; i > 0; i--) {
    motor.changeDuty(MOTOR_CH_B, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }
  motor.changeDuty(MOTOR_CH_B, 0);
  Serial.println(F(".. Finished"));

  // M2 Backward test ********************************************************
  Serial.print(F("MB backward Test .."));
  motor.changeStatus(MOTOR_CH_B, MOTOR_STATUS_CCW);
  motor.changeFreq(MOTOR_CH_B, 20000);
  motor.changeStatus(MOTOR_CH_A, MOTOR_STATUS_STOP);

  Serial.print(F(".. increase speed .."));
  for (int i = 0; i < 100; i++) {
    motor.changeDuty(MOTOR_CH_B, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }

  Serial.print(F(".. decrease speed .."));
  for (int i = 100; i > 0; i--) {
    motor.changeDuty(MOTOR_CH_B, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }
  motor.changeDuty(MOTOR_CH_B, 0);
  Serial.println(F(".. Finished"));

  // test both motors ********************************************************
  // forward test
  Serial.print(F("Both forward Test .."));
  motor.changeStatus(MOTOR_CH_BOTH, MOTOR_STATUS_CW);
  motor.changeFreq(MOTOR_CH_BOTH, 20000);
  //

  Serial.print(F(".. increase speed .."));
  for (int i = 0; i < 100; i++) {
    motor.changeDuty(MOTOR_CH_BOTH, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }

  Serial.print(F(".. decrease speed .."));
  for (int i = 100; i > 0; i--) {
    motor.changeDuty(MOTOR_CH_BOTH, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }
  motor.changeDuty(MOTOR_CH_BOTH, 0);
  Serial.println(F(".. Finished"));

  // Backward test ********************************************************
  Serial.print(F("Both backward Test .."));
  motor.changeStatus(MOTOR_CH_BOTH, MOTOR_STATUS_CCW);
  motor.changeFreq(MOTOR_CH_BOTH, 20000);


  Serial.print(F(".. increase speed .."));
  for (int i = 0; i < 100; i++) {
    motor.changeDuty(MOTOR_CH_BOTH, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }

  Serial.print(F(".. decrease speed .."));
  for (int i = 100; i > 0; i--) {
    motor.changeDuty(MOTOR_CH_BOTH, i);
    if ( (i % 10) == 0 ) {
      Serial.print(".");
    }
    delay(200);
  }
  motor.changeDuty(MOTOR_CH_BOTH, 0);
  Serial.println(F(".. Finished"));

  /********************************************************/

  motor.changeStatus(MOTOR_CH_BOTH, MOTOR_STATUS_STOP);
  delay(2000);
  // stop

}
So siehts auf der Konsole aus:

Problems
—
Conclusion
Kann zwei Motoren über den I²C-Bus bedienen, was will man mehr?
More posts
Other Shields
- D1 Mini Shield – Prototyp-PlatineLink status: OK
- D1 Mini Shield – RGB LED (Einzeln)Link status: OK
- D1 Mini Shield – RGB LEDLink status: OK
- D1 Mini Shield – PIR (Bewegungssensor)Link status: OK
- D1 Mini Shield – AT8870 MotorLink status: OK
- D1 Mini Shield – SG30 LuftqualitätsmessungLink status: OK
- D1 Mini Shield – I2C ConnectorLink status: OK
- D1 Mini Shield – Matrix LED ShieldLink status: OK
- D1 Mini Shield – Oled 64×48Link status: OK
- D1 Mini Shield – Buzzer (Pipser)Link status: OK
More ESPs
- October Check 2026 – Neue Mikrocontroller und BoardsLink status: OK
- Ulanzi TC001 Smart Pixel ClockLink status: OK
- ESP WEB Serial LibraryLink status: OK
- ESP32-C3 Seeed Studio XIAOLink status: OK
- ESP32-C3 Super Mini BoardLink status: OK
- Preview – LuatOs ESP32-C3 BoardLink status: OK
- ESP32 Bluetooth GamepadLink status: OK
- ESP01 – DHT11 Temperatur und Feuchte Sensor PlatinenLink status: OK
- ESP01 Relay BoardsLink status: OK
- ESP8266/32 WiFi Manager.Link status: OK
Sources
Sources for the Shield
Manufacturer's websiteLink status: OK
Sources for the boards
Manufacturer's websiteLink status: OK
SchematicLink status: OK
CH340 USB DriverLink status: OK
https://arduino-projekte.info/wemos-d1-mini/Link status: OK
https://www.exp-tech.de/plattformen/esp8266/entwicklungsboards/8898/wemos-d1-miniLink status: Broken
https://www.wemos.cc/en/latest/d1_mini_shield/hr8833_motor.htmlLink status: OK
| Date | Change | Author |
|---|---|---|
| 15.10.2026 | Beispielcode als Code-Block eingefügt (Einbettung über gist-it.appspot.com funktionierte nicht mehr) | Suffocation |
| 08.10.2026 | Überschriften-Hierarchie korrigiert (H1→H2, Unterebenen eine Stufe tiefer) | Suffocation |
| 04.10.2026 | Rechtschreibung korrigiert: Tippfehler, Groß-/Kleinschreibung, Kommas | Suffocation |
| 03.10.2026 | Log-Liste eingefügt | Suffocation |
| 16.04.2022 | Post created | Suffocation |
Hello Stefan,
tolle Beschreibung. Du sagst, dass am HR8833 ein stepper betrieben werden kann. Das bekomme ich nicht hin. Ich habe einen 2 Phasen, 4 Draht Stepper an A 1/2 und B 1/2 angeschlossen und bekomme den nicht ans laufen. D1 mini, D1 mini Shield HR8833, geht das mit der LOLIN_I2C_MOTOR_Library?
Hallo Tommes, die Antwort wird dir nicht gefallen, entweder du bekommst es mit den Befehlen in der LIB hin den Stepper anzusprechen (sehr unwahrscheinlich) oder du schaust welche Firmware der STC8H1K08 hat. Entweder sie unterstützt den Schrittmotor oder du müsstest eine neue Firmware schreiben. Da mir dies alles doch sehr aufwändig erscheint habe ich den Schrittmotorbetrieb mal durchgestrichen. Ich bin ehrlich gesagt davon ausgegangen das hier ein Std. IC für die I2C Anbindung verbaut ist. Auch hier auf der Seite konnte ich keine weiteren Infos finden. https://www.wemos.cc/en/latest/d1_mini_shield/hr8833_motor.html. Sorry war offensichtlich wohl eine Fehlinformation. Gruß Stefan
Hallo, mal eine Frage. Ich verwende einen D1-Mini und hab das HR8833 Motorshield draufgesteckt. alles läuft gut. Statt des 2ten Motors möchte ich einen Servo am Pin2 oder einem anderen geeigneten Pin betreiben.
Ein guter link mit einem Beispielscript würde mir sehr weiterhelfen.
Hallo Lutz,
würde glaube ich ne Lib wie diese verwenden:
https://github.com/jkb-git/ESP32Servo
Da sagste am Anfang welchen pin du willst und dann auf welche Position der Servo soll. Beispiele sind dabei. Pin mit Datenleitung des Servos verbinden und Spannung +/- anlegen. Gruß Stefan